eval_openvla_cup_stacking_ood
收藏资源简介:
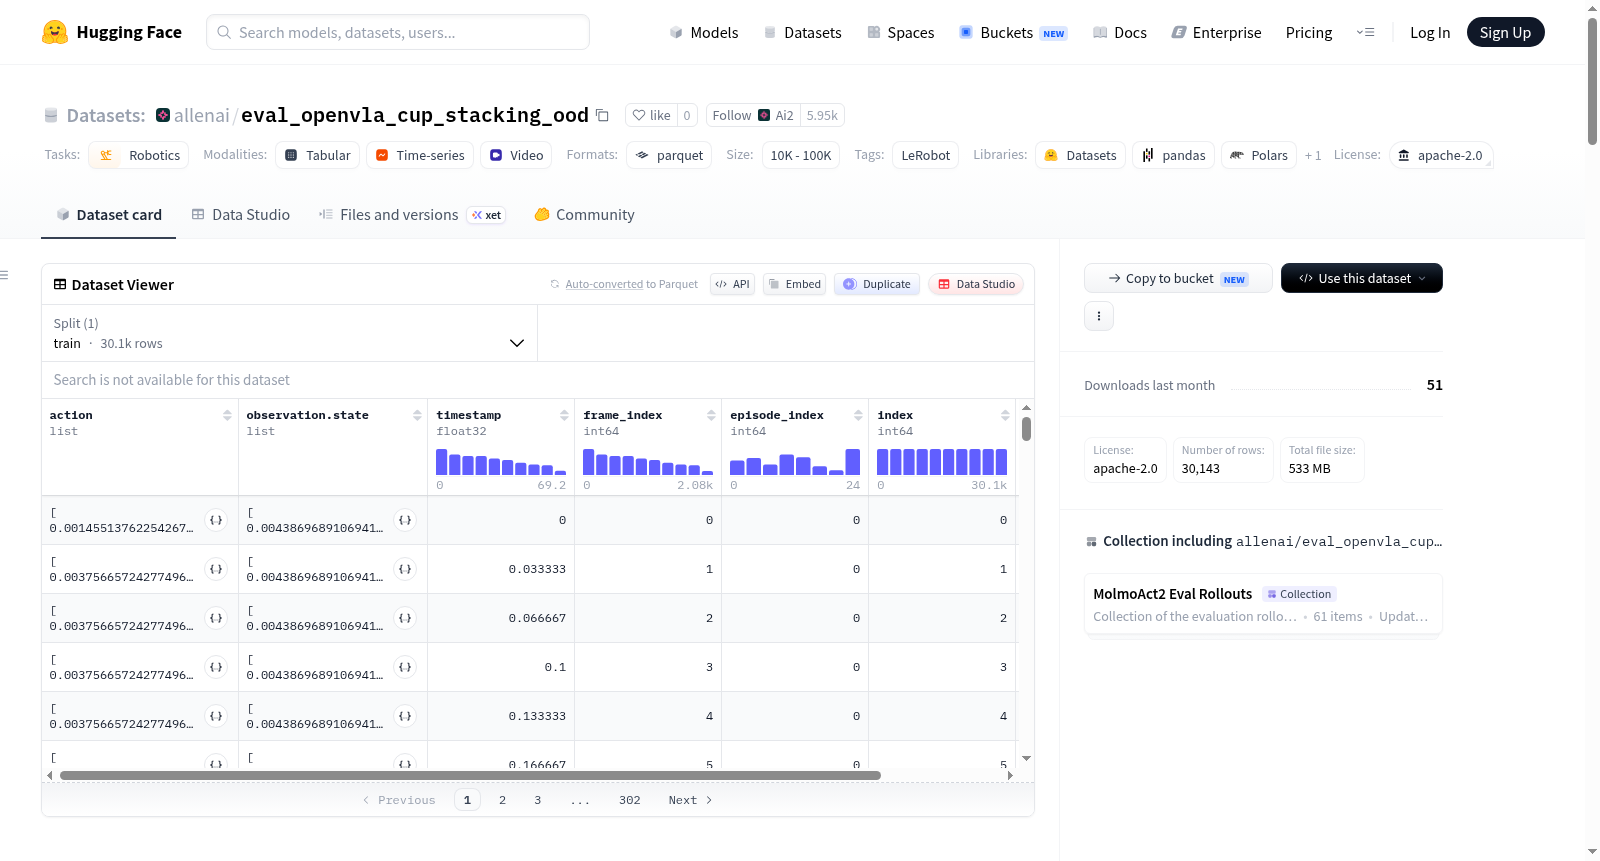
该数据集是一个机器人学数据集,使用LeRobot工具创建,包含双机械臂系统的演示数据,旨在支持机器人模仿学习、强化学习或视觉运动控制等任务的研究与开发。数据集由25个完整的任务执行片段(episodes)组成,总计30,143个数据帧,覆盖3种不同的任务。数据以块(chunk)的形式组织,每块包含1000帧。数据总大小约为100MB,关联的视频文件总大小约为200MB,视频帧率为30 FPS。数据仅包含训练集,涵盖了所有25个片段。核心特征包括:1. 动作(action):一个14维的浮点数向量,分别控制左机械臂的6个关节和1个夹爪的位置,以及右机械臂的6个关节和1个夹爪的位置。2. 观测(observation):包含状态和图像信息。状态观测是一个14维浮点数向量,记录了左右机械臂各关节和夹爪的实时位置。图像观测提供了三个固定视角(右侧、左侧、顶部)的RGB视频流,每个视频流的分辨率为360x640像素,包含3个颜色通道,采用AV1编码,帧率为30 FPS。3. 元数据:包括时间戳、帧索引、片段索引、全局数据索引和任务索引,用于精确定位和序列重建。数据集采用Apache-2.0许可证。
This dataset is a robotics dataset created using the LeRobot tool, containing demonstration data for a dual-arm robotic system, designed to support research and development in tasks such as robot imitation learning, reinforcement learning, or visual-motor control. The dataset consists of 25 complete task execution episodes, totaling 30,143 data frames, covering 3 different tasks. Data is organized in chunks, with each chunk containing 1000 frames. The total data size is approximately 100 MB, and the associated video files total about 200 MB, with a frame rate of 30 FPS. The data includes only the training set, covering all 25 episodes. Key features include: 1. Action: a 14-dimensional floating-point vector controlling the positions of 6 joints and 1 gripper for the left arm, and 6 joints and 1 gripper for the right arm. 2. Observation: includes state and image information. The state observation is a 14-dimensional floating-point vector recording the real-time positions of the joints and grippers of both arms. The image observation provides RGB video streams from three fixed perspectives (right, left, top), each with a resolution of 360x640 pixels, 3 color channels, AV1 encoding, and a frame rate of 30 FPS. 3. Metadata: includes timestamps, frame indices, episode indices, global data indices, and task indices for precise localization and sequence reconstruction. The dataset is licensed under Apache-2.0.