Oxford Inertial Odometry Dataset (OxIOD)
收藏资源简介:
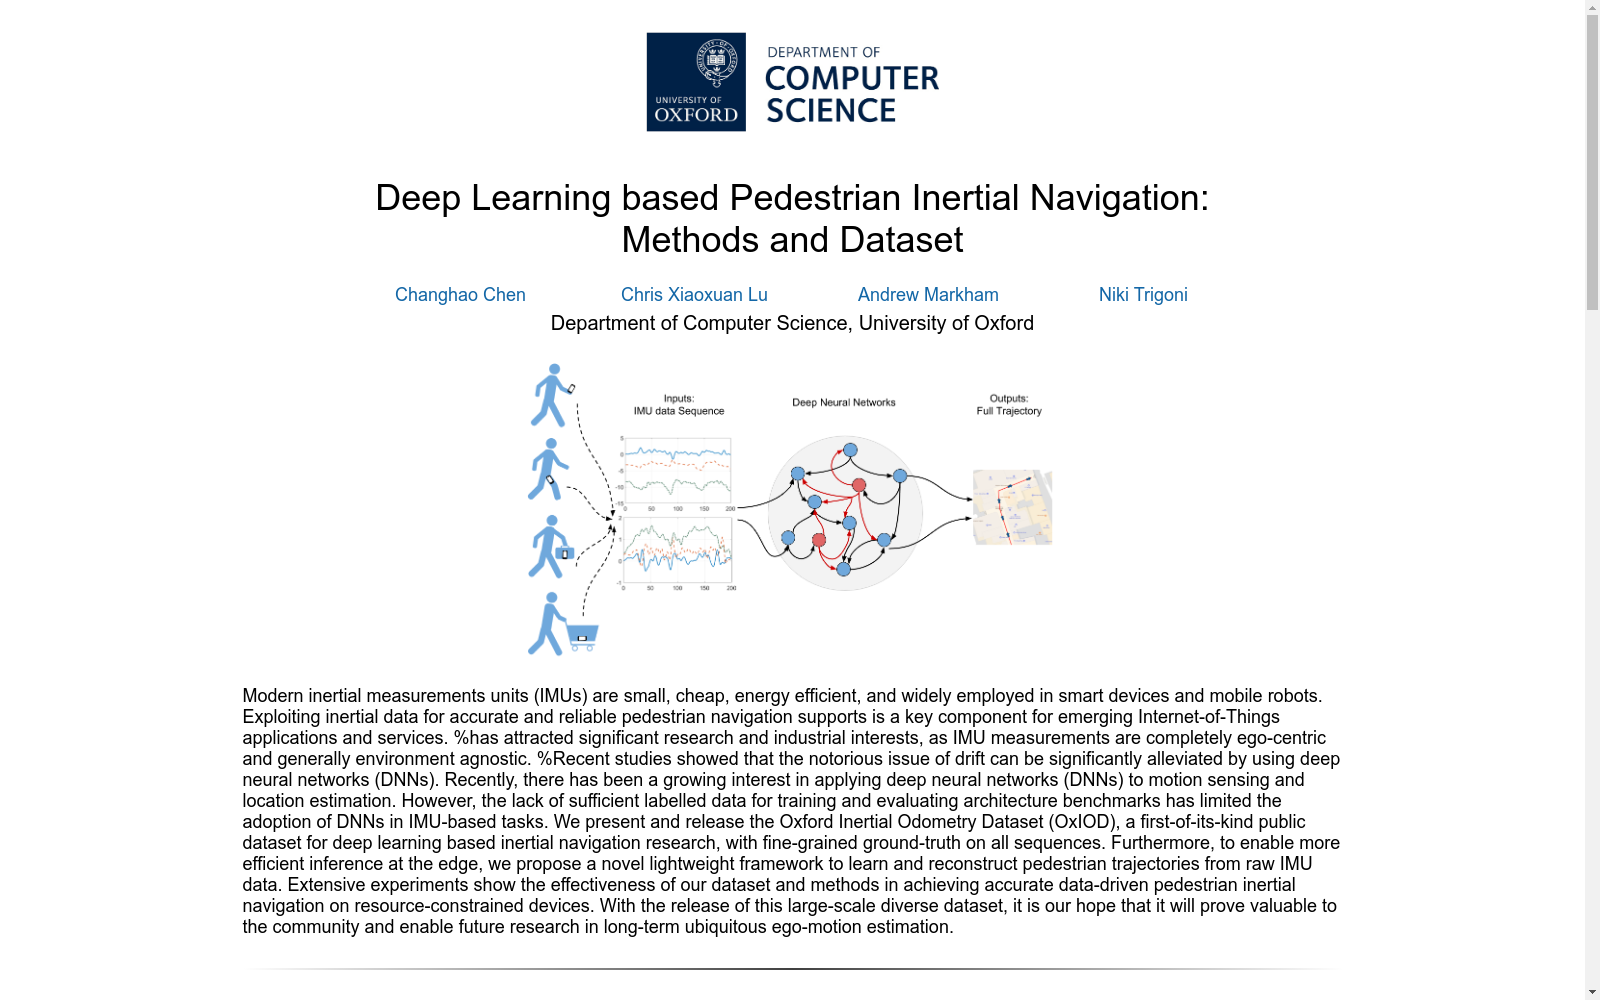
Oxford Inertial Odometry Dataset (OxIOD) 是由牛津大学计算机科学系创建的一个专门用于惯性测距研究的数据集。该数据集包含158个序列,总距离超过42公里,远大于之前的惯性数据集。OxIOD的特点在于其多样性,能够反映手机基IMU在日常使用中的复杂运动。数据收集涉及四种不同的附件(手持、口袋、手提包和手推车),四种运动模式(停止、慢走、正常行走和跑步),五种不同用户和四种消费级手机类型。数据集的创建过程中,使用了高精度的运动捕捉系统进行标记,旨在通过深度神经网络模型解决惯性导航中的漂移问题,适用于训练和评估基于学习的和基于模型的算法。
The Oxford Inertial Odometry Dataset (OxIOD) is a specialized dataset dedicated to inertial odometry research, created by the Department of Computer Science, University of Oxford. It includes 158 sequences with a total distance exceeding 42 kilometers, which is far larger than previous inertial datasets. The key feature of OxIOD is its diversity, which can reflect the complex motions of cell-phone-based IMUs during daily use. Data collection involves four different mounting scenarios: handheld, in a pocket, in a handbag, and on a trolley, four motion modes: stationary, slow walking, normal walking, and running, five distinct users, and four consumer-grade smartphone models. During the dataset creation process, a high-precision motion capture system was used for ground-truth labeling. It aims to solve the drift problem in inertial navigation via deep neural network models, and is applicable for training and evaluating both learning-based and model-based algorithms.