areumii_pickplace-v5
收藏资源简介:
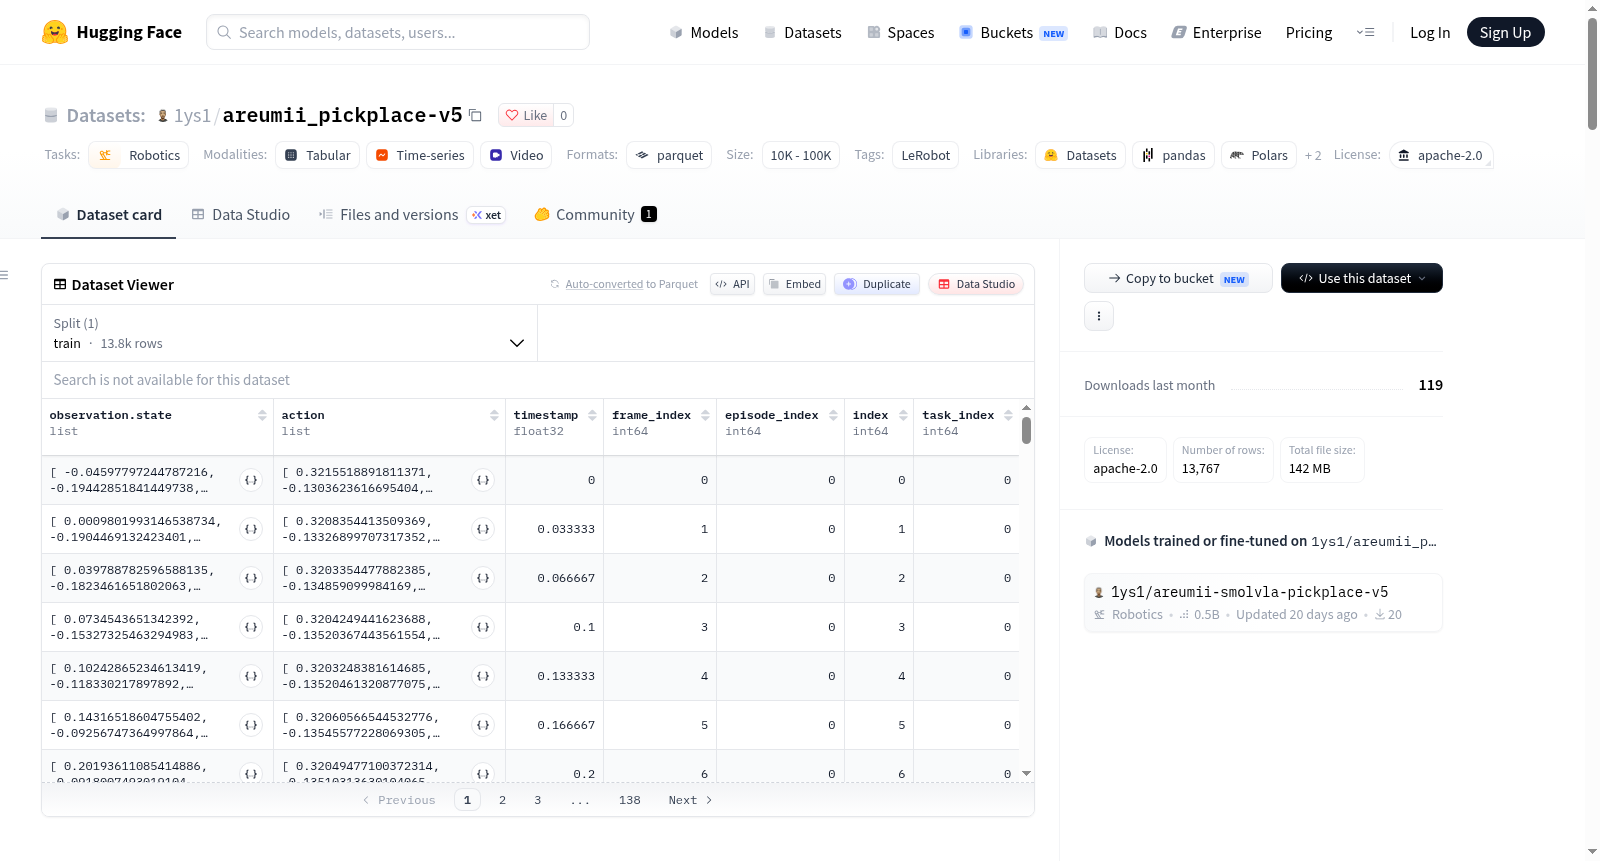
该数据集是基于LeRobot框架构建的机器人操作数据集,专注于双臂机器人(areumii_c1)的抓取放置任务(pick and place)。数据集包含160个演示片段(episode),共计13767帧,涵盖2个不同的任务。数据以30帧/秒的速率采集,包含来自三个摄像头的视频流:前视摄像头(480×640分辨率)以及左右腕部摄像头(各240×320分辨率),均采用AV1编码。此外,每个时间步还记录了机器人左右臂的18维关节状态(角度/位置)、16维动作(包括左右臂末端执行器的位置、四元数姿态和夹爪指令),以及时间戳、帧索引、episode索引和任务索引等元数据。该数据集适用于机器人模仿学习、行为克隆、强化学习等任务,特别适合研究双臂协调操作场景。
This dataset is a robot manipulation dataset built on the LeRobot framework, focusing on the pick and place task of a dual-arm robot (areumii_c1). The dataset contains 160 demonstration episodes totaling 13767 frames, covering 2 different tasks. Data is collected at 30 frames per second, including video streams from three cameras: a front-view camera (480×640 resolution) and left and right wrist cameras (240×320 resolution each), all encoded with AV1. Additionally, each timestep records the 18-dimensional joint states (angles/positions) of the robots left and right arms, 16-dimensional actions (including positions, quaternion poses, and gripper commands of the left and right arm end effectors), as well as metadata such as timestamps, frame indices, episode indices, and task indices. This dataset is suitable for tasks such as robot imitation learning, behavior cloning, and reinforcement learning, especially for studying dual-arm coordinated manipulation scenarios.
数据集概述:areumii_pickplace-v5
基本信息
- 数据集名称:areumii_pickplace-v5
- 许可证:Apache-2.0
- 任务类型:机器人(Robotics)
- 标签:LeRobot
- 创建工具:通过 LeRobot 创建
- 数据集地址:https://huggingface.co/datasets/1ys1/areumii_pickplace-v5
数据集结构
| 属性 | 值 |
|---|---|
| 总片段数 | 160 |
| 总帧数 | 13,767 |
| 总任务数 | 2 |
| 帧率 | 30 FPS |
| 数据文件大小 | 100 MB |
| 视频文件大小 | 200 MB |
| 机器人类型 | areumii_c1 |
| 训练/测试划分 | 训练集:0-160(全部) |
| 代码库版本 | v3.0 |
数据特征
观测状态(observation.state)
- 数据类型:float32
- 维度:18维
- 包含左右手臂各9个关节信息:
- 左臂:shoulder_pitch, shoulder_roll, shoulder_yaw, elbow, wrist_roll, wrist_yaw, wrist_pitch, gripper_left_finger, gripper_right_finger
- 右臂:与左臂相同结构
动作(action)
- 数据类型:float32
- 维度:16维
- 包含双臂末端执行器的位姿和夹爪控制:
- 右臂:ee_x, ee_y, ee_z, ee_qw, ee_qx, ee_qy, ee_qz, gripper
- 左臂:与右臂相同结构
图像观测(observation.images)
- 前置摄像头(front):480x640 分辨率,3通道
- 左腕摄像头(left_wrist):240x320 分辨率,3通道
- 右腕摄像头(right_wrist):240x320 分辨率,3通道
- 视频编码:AV1 编码,30 FPS,YUV420P 像素格式
其他特征
- timestamp:时间戳(float32)
- frame_index:帧索引(int64)
- episode_index:片段索引(int64)
- index:索引(int64)
- task_index:任务索引(int64)
数据格式
- 数据文件:Parquet 格式,存储在
data/目录下 - 视频文件:MP4 格式,存储在
videos/目录下 - 文件命名:chunk-{编号}/file-{编号}.parquet 和 .mp4 格式
总结
该数据集是一个面向双臂机器人拾取与放置(Pick and Place)任务的机器人操作数据集,包含160个演示片段,记录了双臂的关节状态、末端执行器动作以及多视角视觉信息(前置、左腕、右腕摄像头),适用于基于模仿学习的机器人操控任务训练。