
ROVER
收藏资源简介:
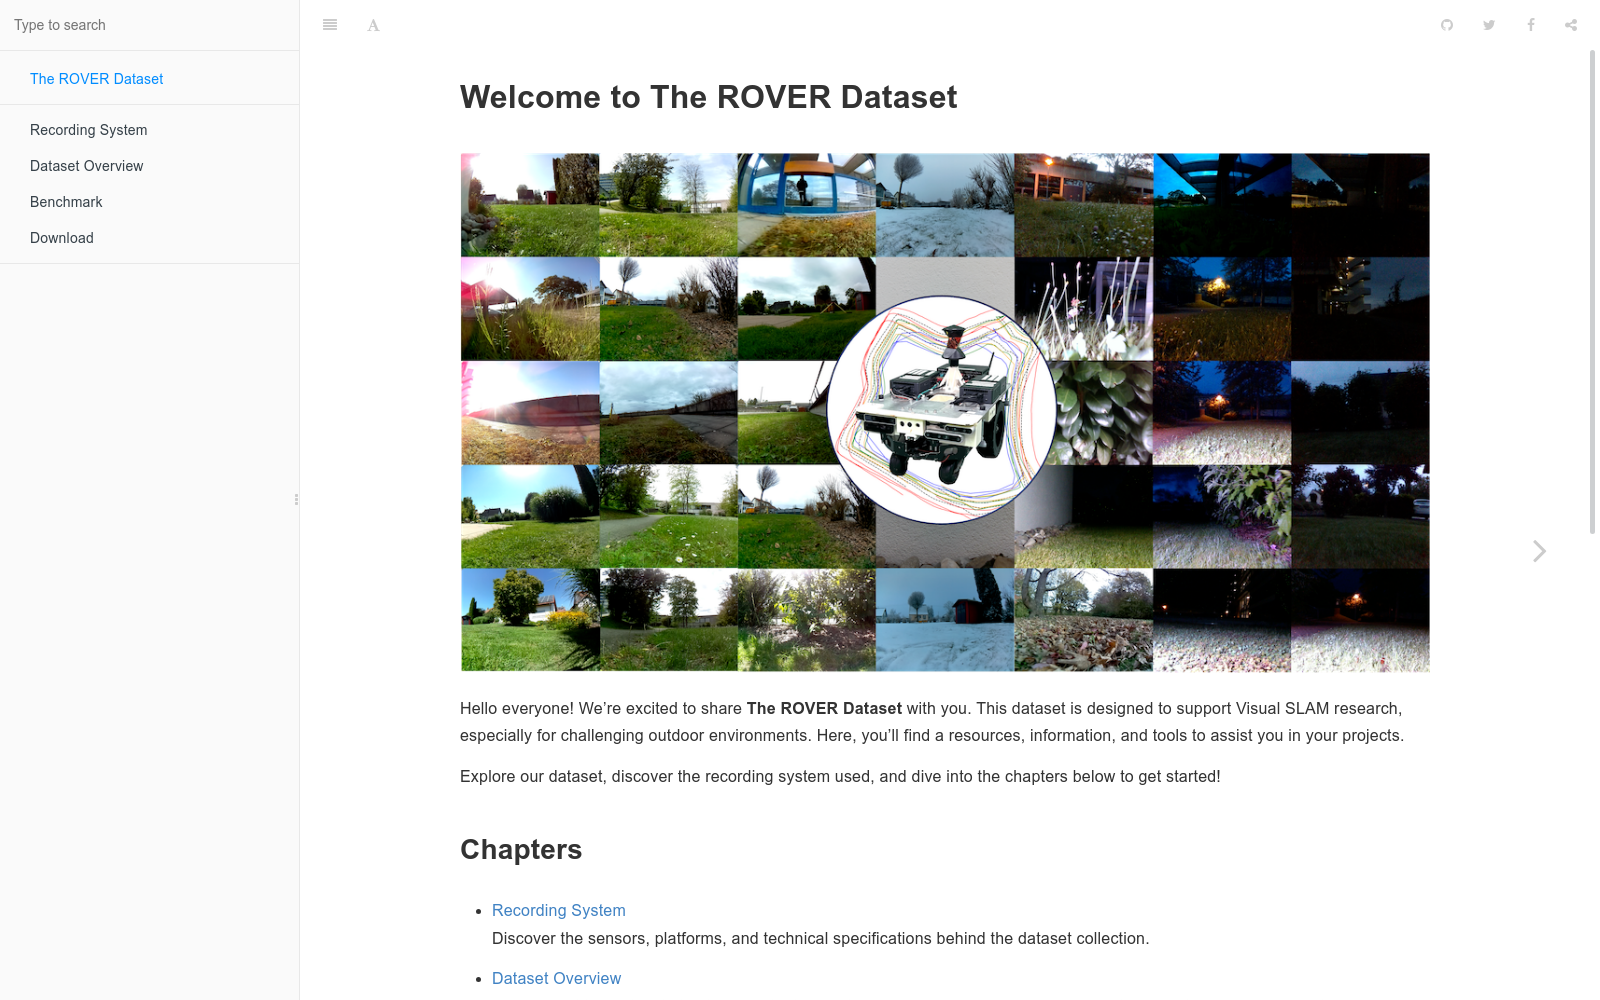
ROVER数据集是一个专为评估视觉SLAM算法在多样自然户外环境中的鲁棒性而设计的综合基准数据集。该数据集由智能系统研究所和弗莱堡大学计算机科学系合作创建,包含39个记录,覆盖了7.2公里的轨迹,数据量约1TB。数据集涵盖了五个户外地点,跨越四季和多种光照条件,包括白天、黄昏和夜晚,以及有无外部照明的情况。数据集通过配备单目、立体和RGB-D相机以及惯性传感器的机器人平台采集,旨在支持视觉和视觉-惯性SLAM算法的评估。ROVER数据集的应用领域包括精准农业、林业和崎岖户外环境中的自主导航,旨在解决在这些复杂环境中长期定位和建图的挑战。
The ROVER dataset is a comprehensive benchmark specifically designed to evaluate the robustness of visual SLAM algorithms across diverse natural outdoor environments. It was collaboratively created by the Institute of Intelligent Systems and the Department of Computer Science, University of Freiburg. The dataset comprises 39 recording sessions, covering a total trajectory of 7.2 kilometers with an overall data volume of approximately 1 TB. It spans five outdoor locations across four seasons and various lighting conditions, including daytime, dusk, night, as well as scenarios with and without external illumination. The data was collected using a robotic platform equipped with monocular, stereo, RGB-D cameras and inertial sensors, aiming to support the evaluation of visual and visual-inertial SLAM algorithms. The ROVER dataset has applications in precision agriculture, forestry and autonomous navigation in rugged outdoor environments, and is intended to address the challenges of long-term localization and mapping in these complex environments.
- 1ROVER: A Multi-Season Dataset for Visual SLAM智能系统研究所,埃斯林根应用科学大学,弗莱堡大学计算机科学系 · 2024年


