jellyho/aloha_handover_box_joint_pos_rl_mc
收藏资源简介:
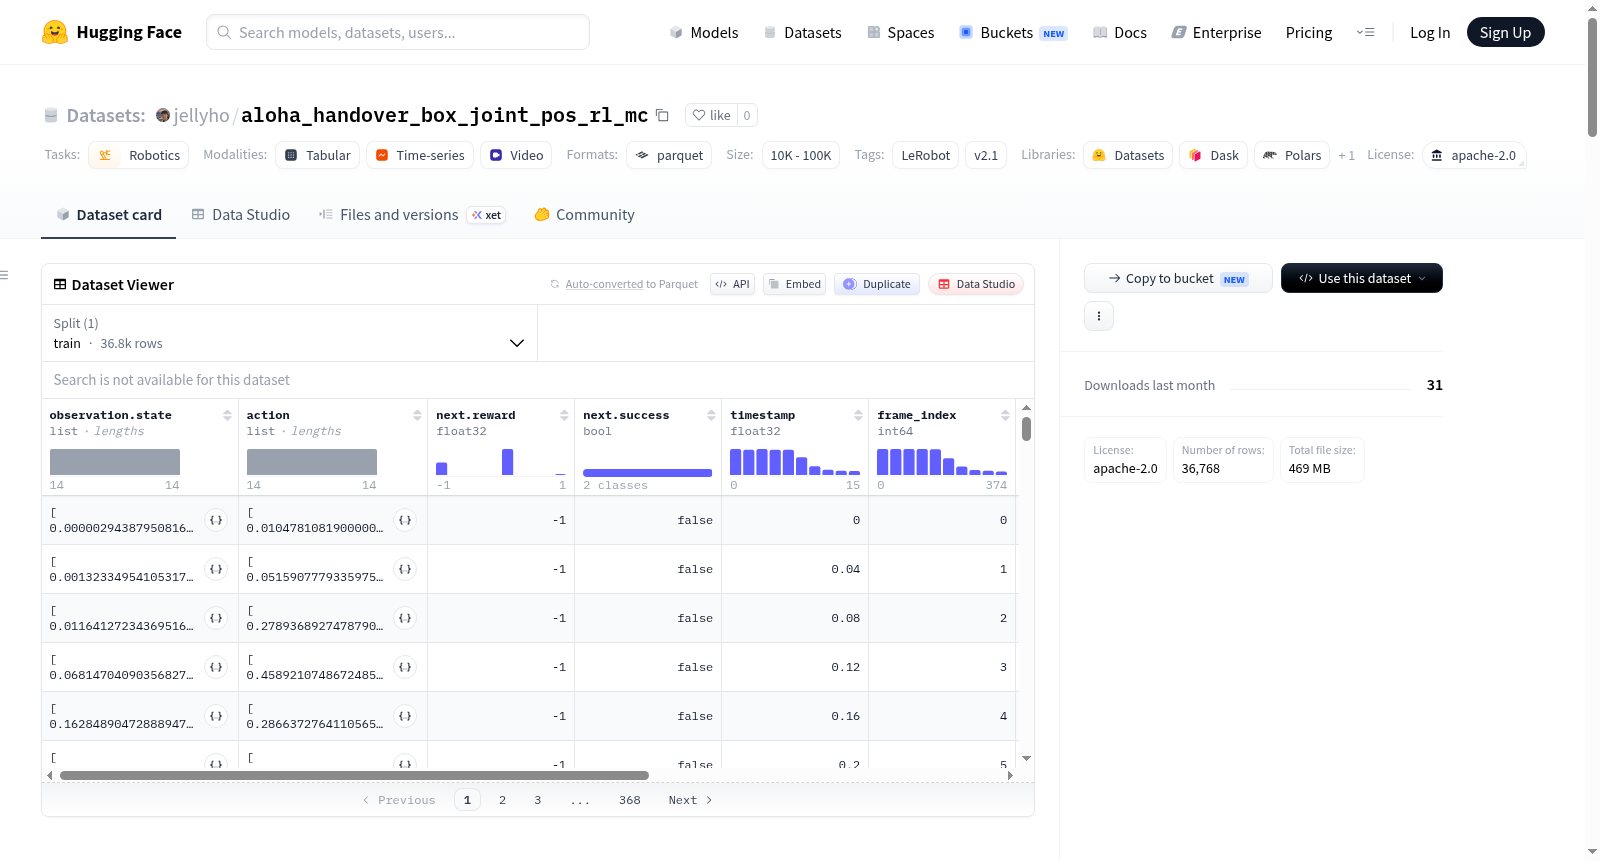
该数据集是一个机器人学数据集,由LeRobot工具创建,版本为v2.1。它包含50个episodes,总计11829帧和150个视频,帧率为25fps,全部数据用于训练集。数据集提供了多模态数据,包括观察状态(14个浮点值,代表左右机械臂的6个关节和夹持器位置)、动作(类似14维浮点向量)、来自三个摄像头的图像(背部摄像头分辨率480x640,左腕和右腕摄像头分辨率240x320,均为RGB视频),以及奖励值、成功标志、时间戳和索引信息。这些数据适用于机器人控制、强化学习或模仿学习任务,支持双机械臂系统的状态和视觉反馈分析。
This dataset is a robotics dataset created using the LeRobot tool, version v2.1. It contains 50 episodes, with a total of 11829 frames and 150 videos, at a frame rate of 25fps, all designated for training. The dataset provides multimodal data, including observation states (14 float values representing the positions of 6 joints and grippers for both left and right robotic arms), actions (a similar 14-dimensional float vector), images from three cameras (back camera at 480x640 resolution, left and right wrist cameras at 240x320 resolution, all RGB videos), as well as reward values, success flags, timestamps, and index information. This data is suitable for robotics control, reinforcement learning, or imitation learning tasks, supporting analysis of state and visual feedback for dual-arm robotic systems.