CID-SIMS Dataset
收藏资源简介:
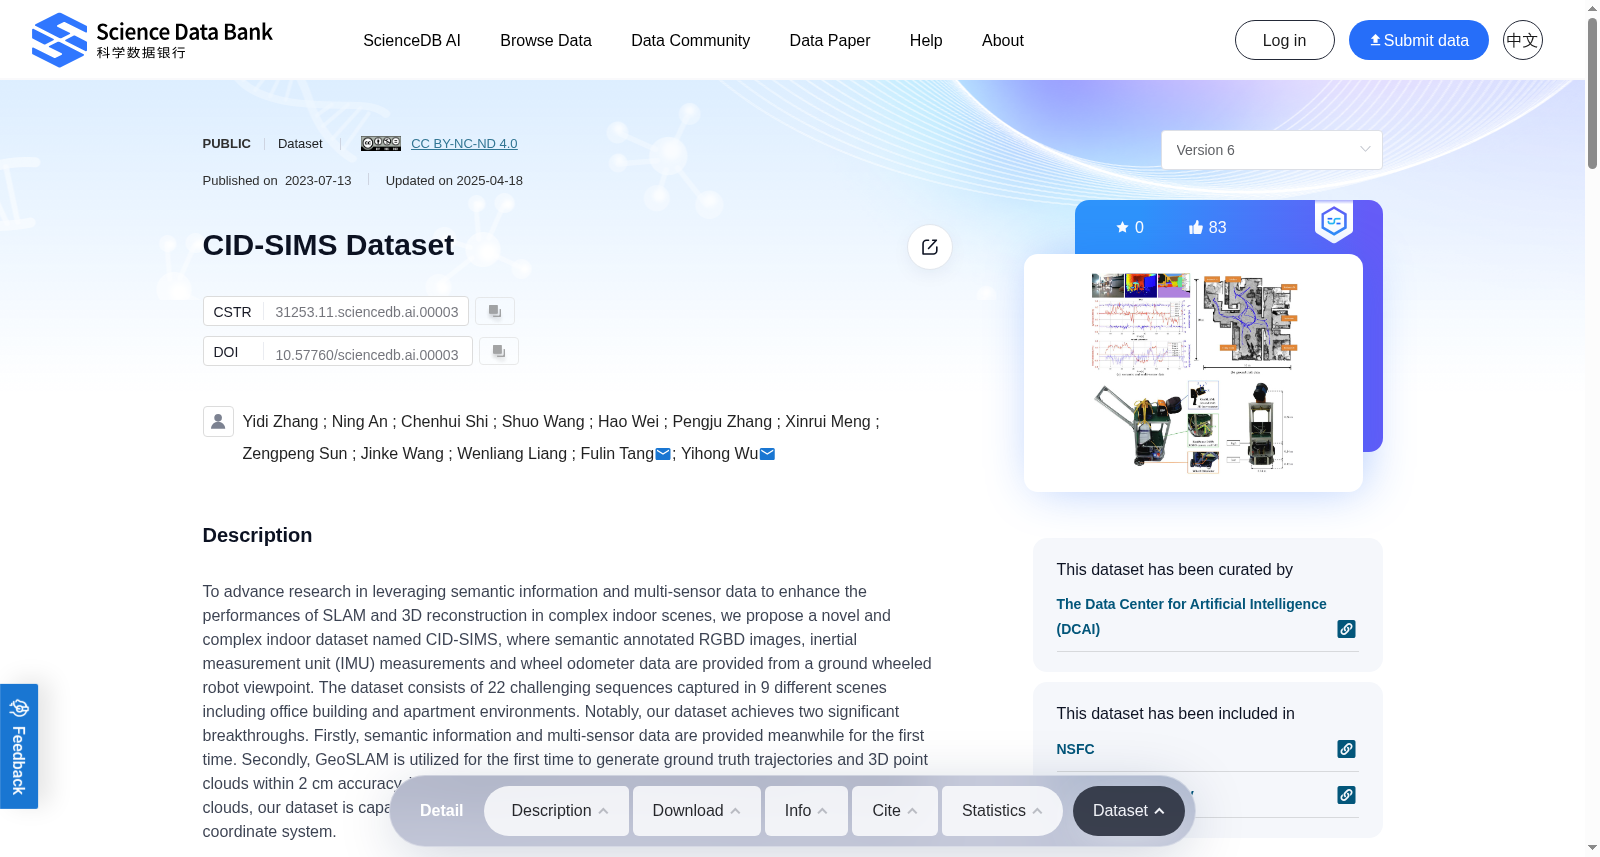
To advance research in leveraging semantic information and multi-sensor data to enhance the performances of SLAM and 3D reconstruction in complex indoor scenes, we propose a novel and complex indoor dataset named CID-SIMS, where semantic annotated RGBD images, inertial measurement unit (IMU) measurements and wheel odometer data are provided from a ground wheeled robot viewpoint. The dataset consists of 22 challenging sequences captured in 9 different scenes including office building and apartment environments. Notably, our dataset achieves two significant breakthroughs. Firstly, semantic information and multi-sensor data are provided meanwhile for the first time. Secondly, GeoSLAM is utilized for the first time to generate ground truth trajectories and 3D point clouds within 2 cm accuracy. With spatial-temporal synchronous ground truth trajectories and 3D point clouds, our dataset is capable of evaluating SLAM and 3D reconstruction algorithms in a unified global coordinate system.
为推动利用语义信息与多传感器数据优化复杂室内场景下同步定位与建图(Simultaneous Localization and Mapping,SLAM)及三维重建性能的研究工作,我们提出一款新型复杂室内数据集CID-SIMS。该数据集采用地面轮式机器人作为采集视角,提供带语义标注的RGBD图像、惯性测量单元(IMU)测量数据与轮式里程计数据。该数据集包含22组高挑战性采集序列,采集场景涵盖办公楼、公寓等共9类不同室内环境。值得关注的是,本数据集实现了两项重要突破:其一,首次同时提供语义信息与多传感器数据;其二,首次通过GeoSLAM生成精度达2厘米以内的真值轨迹与三维点云。依托时空同步的真值轨迹与三维点云,本数据集可在统一全局坐标系下对SLAM及三维重建算法开展性能评估。