ember-lab-berkeley/bridge_v2
收藏资源简介:
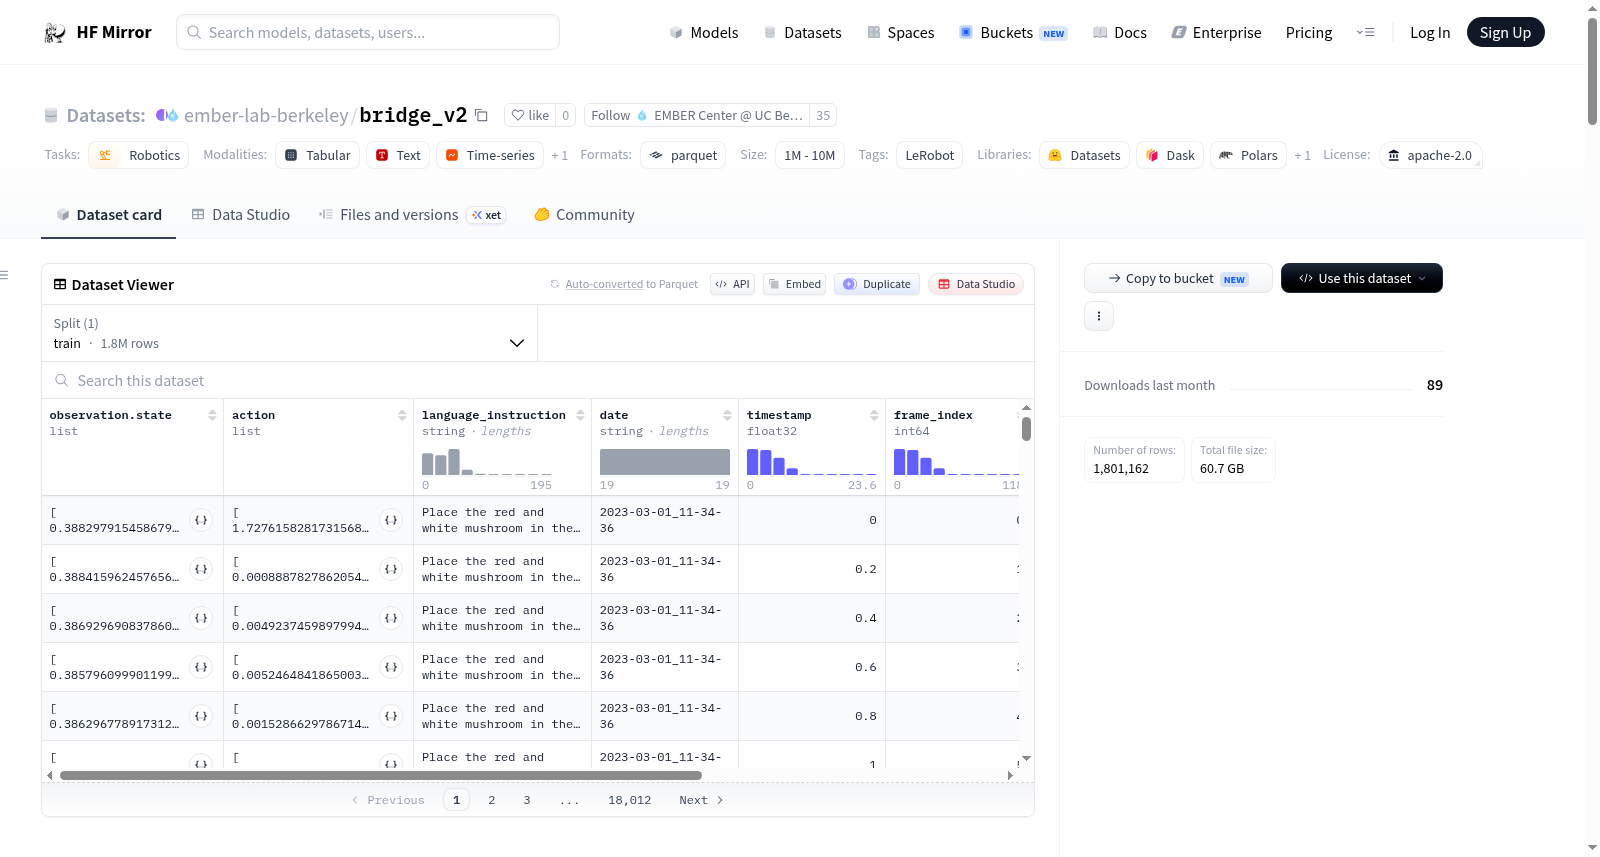
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). ## Dataset Description Converted BridgeV2 dataset to lerobot format. Downloaded from [https://rail.eecs.berkeley.edu/datasets/bridge_release/data/] (only demos_8_17.zip, not scripted_6_18.zip) ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "robot_type": "widowx", "total_episodes": 50418, "total_frames": 1801162, "total_tasks": 22199, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "fps": 5, "splits": { "train": "0:50418" }, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "features": { "observation.images.primary": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 5, "video.channels": 3, "has_audio": false } }, "observation.images.wrist": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 5, "video.channels": 3, "has_audio": false } }, "observation.images.side1": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 5, "video.channels": 3, "has_audio": false } }, "observation.images.side2": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 5, "video.channels": 3, "has_audio": false } }, "observation.state": { "dtype": "float32", "shape": [ 7 ], "names": { "axes": [ "joint_0", "joint_1", "joint_2", "joint_3", "joint_4", "joint_5", "gripper" ] } }, "action": { "dtype": "float32", "shape": [ 7 ], "names": { "axes": [ "action_0", "action_1", "action_2", "action_3", "action_4", "action_5", "gripper" ] } }, "language_instruction": { "dtype": "string", "shape": [ 1 ], "names": null }, "date": { "dtype": "string", "shape": [ 1 ], "names": null }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } } } ``` ## Citation **BibTeX:** ```bibtex @inproceedings{walke2023bridgedata, title={BridgeData V2: A Dataset for Robot Learning at Scale}, author={Walke, Homer and Black, Kevin and Lee, Abraham and Kim, Moo Jin and Du, Max and Zheng, Chongyi and Zhao, Tony and Hansen-Estruch, Philippe and Vuong, Quan and He, Andre and Myers, Vivek and Fang, Kuan and Finn, Chelsea and Levine, Sergey}, booktitle={Conference on Robot Learning (CoRL)}, year={2023} } ```