CARLA-GEAR
收藏资源简介:
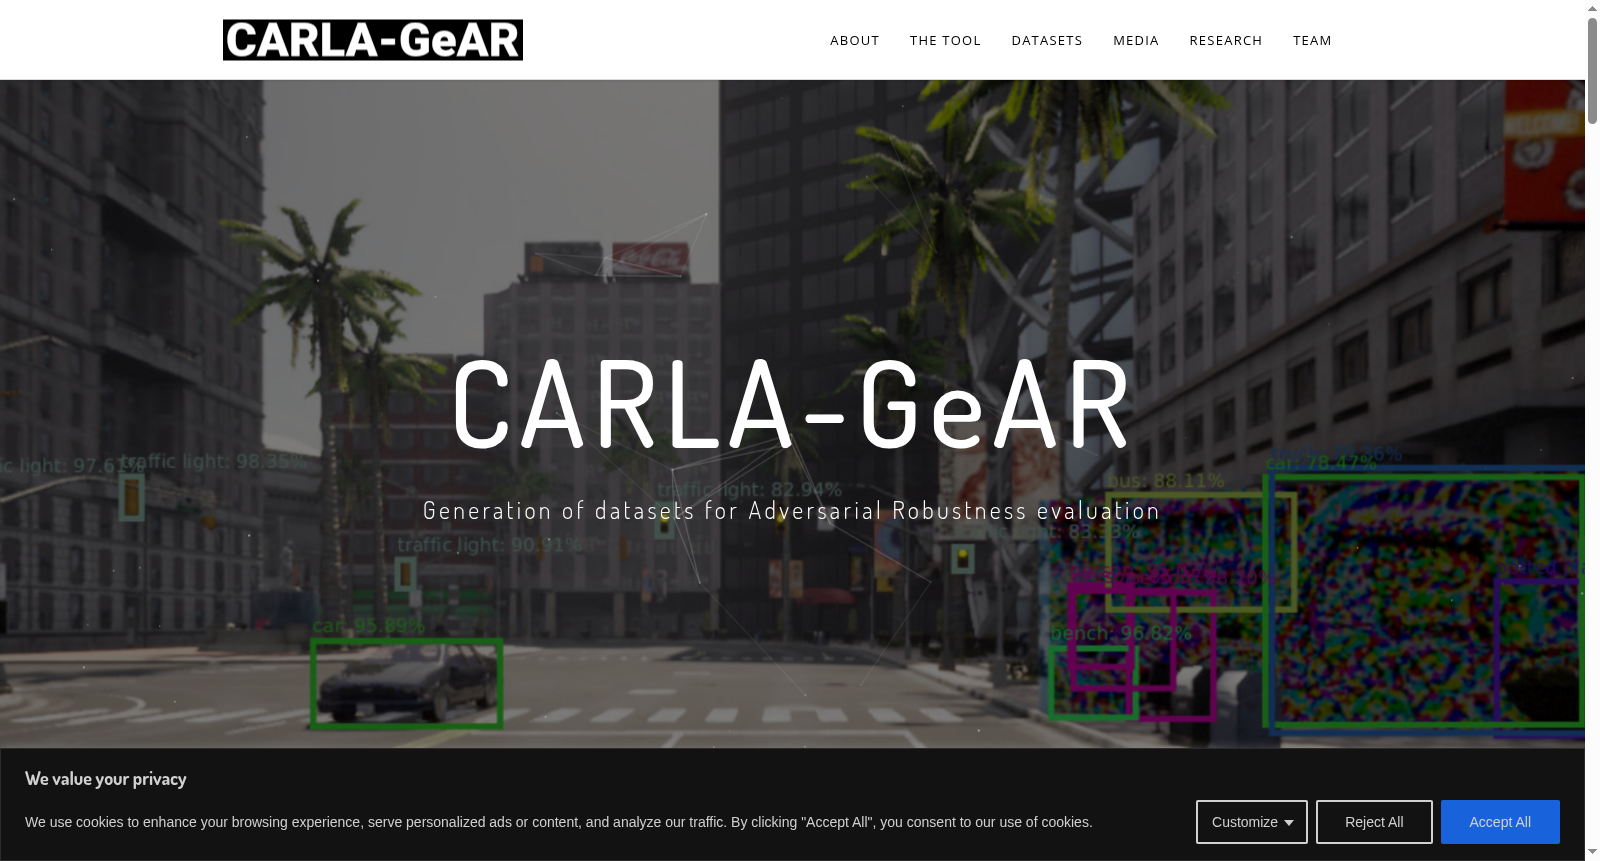
CARLA-GEAR是由意大利比萨圣安娜高等学校的卓越机器人与人工智能学院开发的数据集生成工具,旨在为自动驾驶场景中的视觉任务提供对抗性鲁棒性评估。该数据集包含10个不同的攻击场景,通过在模拟环境中添加对抗性补丁来生成数据,用于评估和比较不同的对抗防御/检测方法。数据集的创建过程涉及在CARLA模拟器中模拟真实世界的对抗攻击,通过Python API控制模拟环境,生成高分辨率的RGB图像和相应的地面实况标签。CARLA-GEAR的应用领域主要集中在自动驾驶技术中,特别是在评估和提高基于视觉感知的系统的安全性方面。
CARLA-GEAR is a dataset generation tool developed by the School of Advanced Robotics and Artificial Intelligence at Scuola Superiore Sant'Anna, Pisa, Italy, designed to provide adversarial robustness evaluation for visual tasks in autonomous driving scenarios. This dataset includes 10 distinct attack scenarios, generating data by adding adversarial patches in simulated environments, and is used to evaluate and compare different adversarial defense or detection methods. The dataset creation process involves simulating real-world adversarial attacks within the CARLA simulator, controlling the simulation environment via the Python API, and producing high-resolution RGB images alongside corresponding ground-truth labels. The application fields of CARLA-GEAR are primarily concentrated in autonomous driving technology, specifically in evaluating and improving the safety of vision-based perception systems.