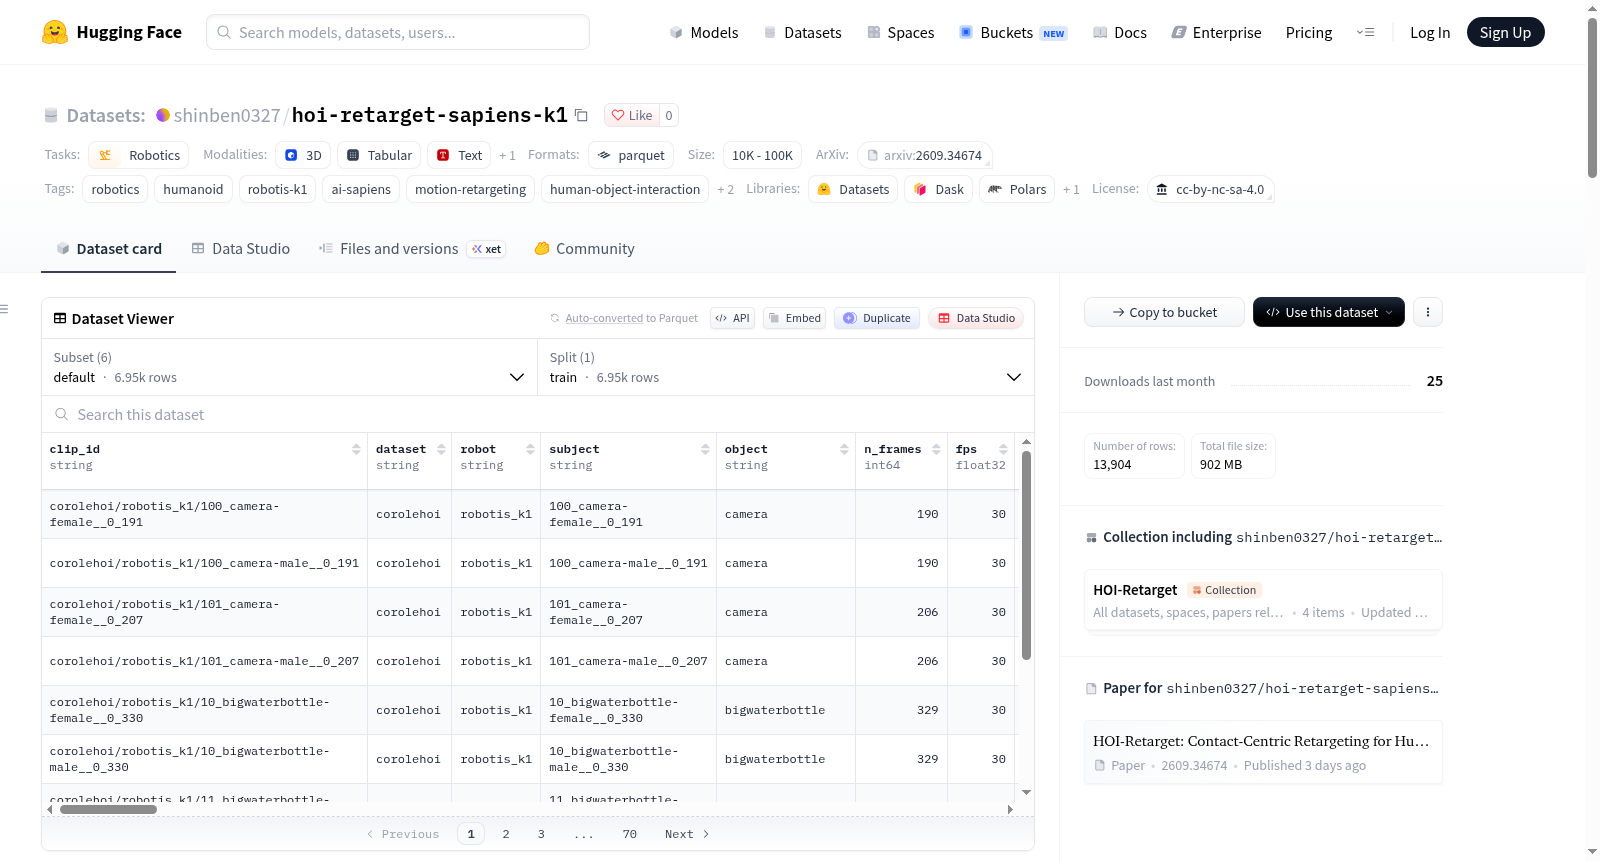
hoi-retarget-sapiens-k1
收藏资源简介:
HOI-Retarget — ROBOTIS AI Sapiens K1是一个专门为ROBOTIS AI Sapiens K1人形机器人重新定位的人-物交互运动数据集。该数据集基于HOI-Retarget(针对Unitree G1和H2)的原始数据,采用相同的方法、设置和质量控制流程,将运动重新定位到K1机器人上。数据集包含6,952个运动序列,总时长约828.1分钟,涉及75种不同的物体网格。每个样本记录了一组关节角度、浮动基座位姿、物体的6自由度位姿,以及双手和双脚每个连杆的接触标志。数据来源于5个公开数据集:OMOMO、ParaHome、NeuralDome、CoRoleHOI和IMHD²,其中CoRoleHOI包含协作运动对(228对,共456行)。机器人模型为ROBOTIS AI Sapiens K1,具有23个自由度,物体缩放比例为0.833。整体质量通过率为96%(6,672个样本)。数据集以parquet文件形式存储,支持按源数据集划分加载。提供视频预览列,每个样本包含一个320×320的渲染视频。适用于机器人运动重定向、人-物交互模拟、接触感知控制等研究。许可协议为CC BY-NC-SA 4.0。
HOI-Retarget — ROBOTIS AI Sapiens K1 is a human-object interaction (HOI) motion dataset specifically retargeted to the humanoid robot ROBOTIS AI Sapiens K1. It is based on the original data from HOI-Retarget (for Unitree G1 and H2), using the same method, setup, and quality control pipeline to retarget motions to the K1 robot. The dataset contains 6,952 motion sequences with a total duration of approximately 828.1 minutes, involving 75 different object meshes. Each sample records a set of joint angles, floating base pose, 6-DoF object pose, and contact flags for each link of both hands and feet. Data originates from five public datasets: OMOMO, ParaHome, NeuralDome, CoRoleHOI, and IMHD², where CoRoleHOI includes collaborative motion pairs (228 pairs, 456 sequences). The robot model is ROBOTIS AI Sapiens K1 with 23 degrees of freedom, and object scaling ratio is 0.833. The overall quality pass rate is 96% (6,672 samples). The dataset is stored in parquet files and supports loading by source dataset splits. A video preview column is provided, with each sample containing a 320×320 rendered video. It is suitable for research in robot motion retargeting, human-object interaction simulation, and contact-aware control. The license is CC BY-NC-SA 4.0.
HOI-Retarget — ROBOTIS AI Sapiens K1 数据集
基本信息
- 数据集地址:https://huggingface.co/datasets/shinben0327/hoi-retarget-sapiens-k1
- 许可证:CC BY-NC-SA 4.0
- 任务类别:robotics(机器人)
- 数据规模:1K < n < 10K
- 标签:robotics、humanoid、robotis-k1、ai-sapiens、motion-retargeting、human-object-interaction、motion-capture、contact
数据集概述
该数据集为 HOI-Retarget 动作(原针对 Unitree G1 和 H2),使用相同的方法、设置和质量控制(QC)重定向至 ROBOTIS AI Sapiens K1 机器人。其列结构、文件布局与加载代码均与公开版本一致,仅机器人不同。每一行代表一次动作,包含关节角度、浮动基座、物体的 6-DoF 位姿,以及双掌和双脚的逐连杆接触标志。
内容统计
| 项目 | 数值 |
|---|---|
| 源数据集 | 5 个 — OMOMO、ParaHome、NeuralDome、CoRoleHOI、IMHD² |
| 动作数量 | 6,952 |
| 物体数量 | 75 个不同网格 |
| 总时长 | 828.1 分钟 |
| 协作动作 | 456 行(228 对 CoRoleHOI) |
| 机器人 | ROBOTIS AI Sapiens K1,robotis_k1(23 自由度,物体缩放 0.833) |
| 通过 QC | 6,672(96.0%) |
各源数据集明细
| 数据集 | 动作数 | 物体数 | 时长(分钟) | QC 通过 | 保留率 % |
|---|---|---|---|---|---|
| OMOMO | 4,421 | 13 | 447.7 | 4,232 | 95.7 |
| ParaHome | 980 | 12 | 179.1 | 978 | 99.8 |
| NeuralDome | 915 | 20 | 127.8 | 851 | 93.0 |
| CoRoleHOI | 456 | 23 | 49.1 | 443 | 97.1 |
| IMHD² | 180 | 7 | 24.4 | 168 | 93.3 |
| 总计 | 6,952 | 75 | 828.1 | 6,672 | 96.0 |
配置(Configs)
- default:data///train-*.parquet
- omomo:data/omomo//train-.parquet
- parahome:data/parahome//train-.parquet
- neuraldome:data/neuraldome//train-.parquet
- corolehoi:data/corolehoi//train-.parquet
- imhd2:data/imhd2//train-.parquet
机器人模型
assets/robots/k1/ 存放求解所用模型:k1_hoi_mocap.xml(MuJoCo)、k1_hoi.urdf 及网格文件,来自 ROBOTIS 的 ai_sapiens_description 0.2.2。为接触目标添加了固定的手腕、掌垫和脚趾坐标系;assets/robots/k1/NOTICE 列出了所有更改。物体按机器人根缩放比例 0.833 缩放(scale_object_mesh 与 scale_object_trajectory 均为 true)。
物体网格
- 13 个 OMOMO 物体随
assets/objects/提供。通过export HOI_RETARGET_OBJECT_ROOTS=<this download>指向该下载。 - 其余四个数据集的网格不重新分发;需按
<root>/<dataset>/_assets/<object>.urdf布局放置。 - 物体名称在不同数据集间会重复,因此需以
(dataset, object)作为键。
快速开始
仓库为私有,需先登录(huggingface-cli login)且账户具有访问权限。
python from datasets import load_dataset import numpy as np
ds = load_dataset("shinben0327/hoi-retarget-sapiens-k1", split="train") # everything ds = load_dataset("shinben0327/hoi-retarget-sapiens-k1", "omomo", split="train") # one source dataset
clean = ds.filter(lambda r: r["qc_pass"]) r = clean[0] dof = np.array([np.asarray(x) for x in r["dof_pos"]]) # (T, 23) joint angles, radians obj = np.array([np.asarray(x) for x in r["object_pos"]]) # (T, 3) object position, metres print(r["clip_id"], dof.shape, r["object"], r["qc_flags"])
- 各列描述见
docs/SCHEMA.md;examples/to_pkl.py可将一行还原为流水线的contact_window.pkl。 examples/smplx_to_k1.json:所用 IK 配置;可用 HOI-Retarget--robot robotis_k1复现。
质量控制
公开版本的规则未变:
qc_pass = False if wrist_runfrac > 0.50 # wrist_sustained or foldx_p80 >= 50 # body_folded or (limit_sat_pct >= 15 and foldx_p80 >= 15) # body_folded
K1 的两处适配:
- K1 手腕滚转范围为 ±180°,无机械限位,因此
wrist_runfrac以 G1 的半量程衡量(“接近限位”线同样位于 90.4°)。 limit_sat_pct仅统计 14 个具有真实限位的铰链。object_floating在 IMHD² 滑板行上手动设置,与公开版本一致:源数据中滑板漂浮于地面之上 20–30 cm。
预览
video 列包含每行一个 320 × 320 渲染视频。CoRoleHOI 行显示一对中的两个 K1,本行机器人为正常颜色,协作为着色显示。
许可
采用 CC BY-NC-SA 4.0,为各源数据集中最严格的条款。
| 源数据集 | 其许可证 |
|---|---|
| OMOMO | MIT |
| ParaHome | CC BY-NC-SA 4.0 |
| NeuralDome / HODome | CC BY-NC-SA 4.0 |
| CoRoleHOI | CC BY 4.0 |
| IMHD² | CC BY-NC-SA 4.0 |
- 轨迹为源动作捕捉的衍生作品;接触标注源自 InterAct(CC BY-NC-SA 4.0)。
- 使用任一片段需引用其源数据集;
NOTICE.md提供参考文献。 - OMOMO 物体网格从 InterMimic 以 MIT 许可重新分发(
assets/objects/LICENSE-OBJECTS)。 - K1 模型为 ROBOTIS 所有,Apache-2.0(
assets/robots/k1/LICENSE、assets/robots/k1/NOTICE)。
引用
bibtex @article{shin2026hoiretarget, title = {HOI-Retarget: Contact-Centric Retargeting for Human-Object Interaction}, author = {Shin, Jihwan and L'opez Escoriza, Adri`a and He, Junzhe and Heyrman, Matthias and Hutter, Marco}, journal = {arXiv preprint arXiv:2609.34674}, year = {2026}, url = {https://arxiv.org/abs/2609.34674} }