
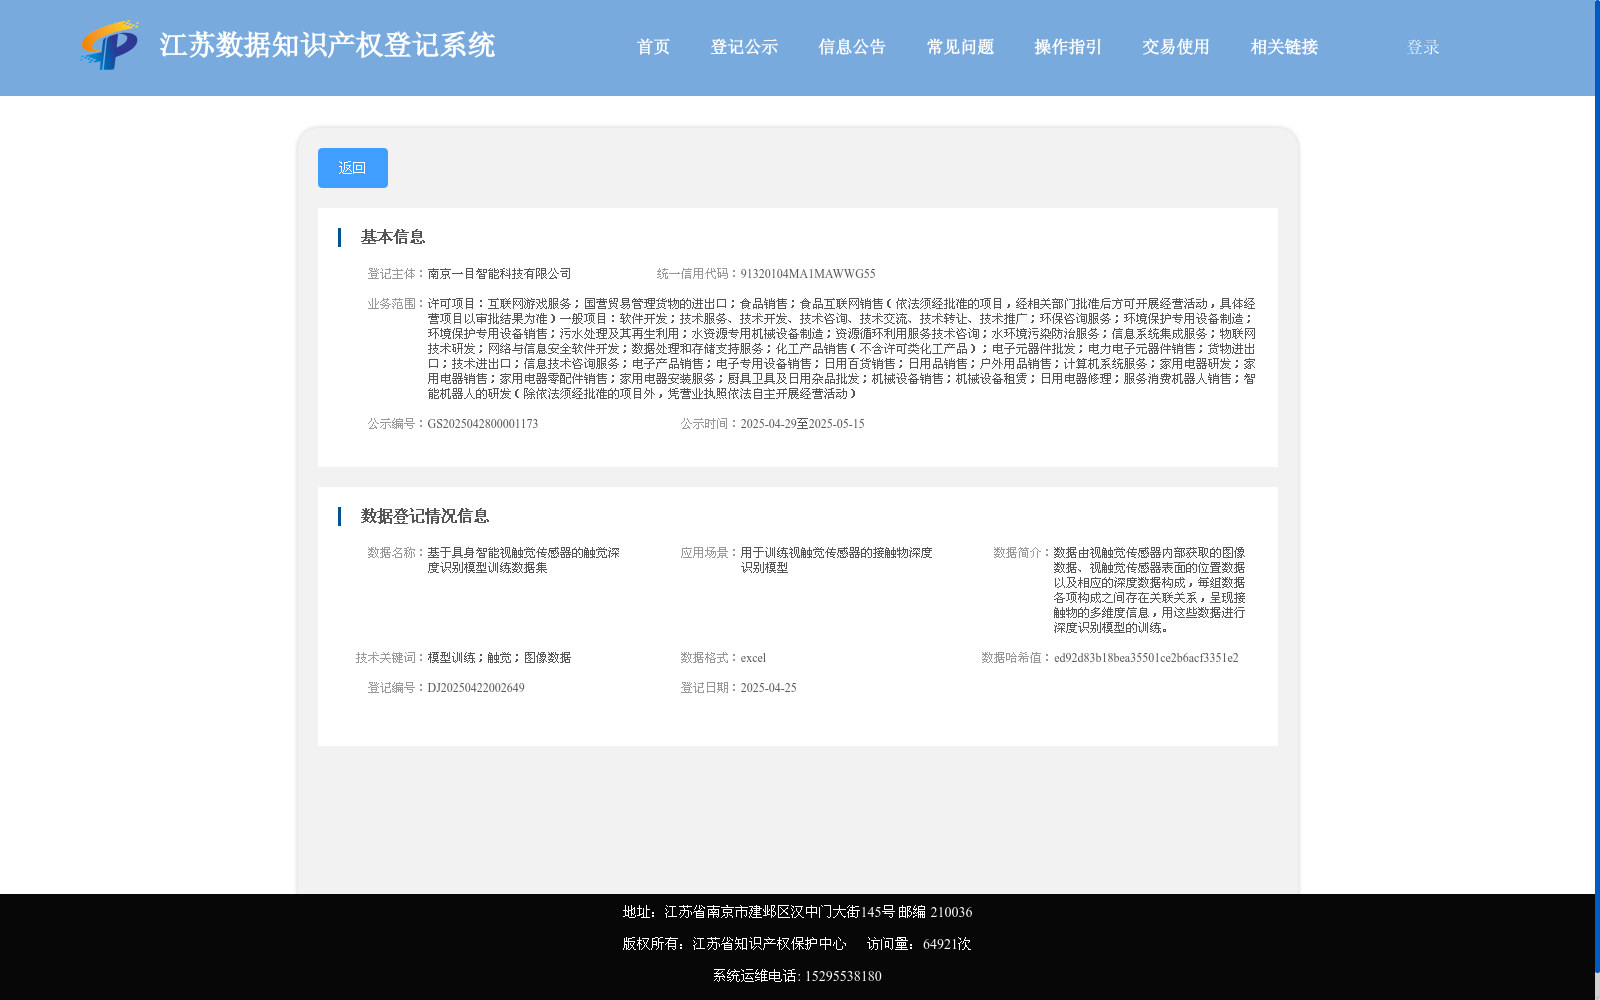
基于具身智能视触觉传感器的触觉深度识别模型训练数据集
收藏数据链接:
官方服务:
资源简介:
数据由视触觉传感器内部获取的图像数据、视触觉传感器表面的位置数据以及相应的深度数据构成,每组数据各项构成之间存在关联关系,呈现接触物的多维度信息,用这些数据进行深度识别模型的训练。
The dataset comprises image data acquired internally by the visuo-tactile sensor, position data obtained on the sensor's surface, and corresponding depth data. Inherent correlations exist among the components of each data set, which convey the multi-dimensional information of the contacted objects. These data are employed for the training of depth recognition models.
提供机构:
南京一目智能科技有限公司搜集汇总
数据集介绍
背景与挑战
背景概述
该数据集是基于具身智能视触觉传感器的触觉深度识别模型训练数据集,包含图像数据、位置数据和深度数据,用于训练深度识别模型。数据格式为excel,技术关键词包括模型训练、触觉和图像数据。
以上内容由遇见数据集搜集并总结生成


