TrossenRoboticsCommunity/dq_test
收藏资源简介:
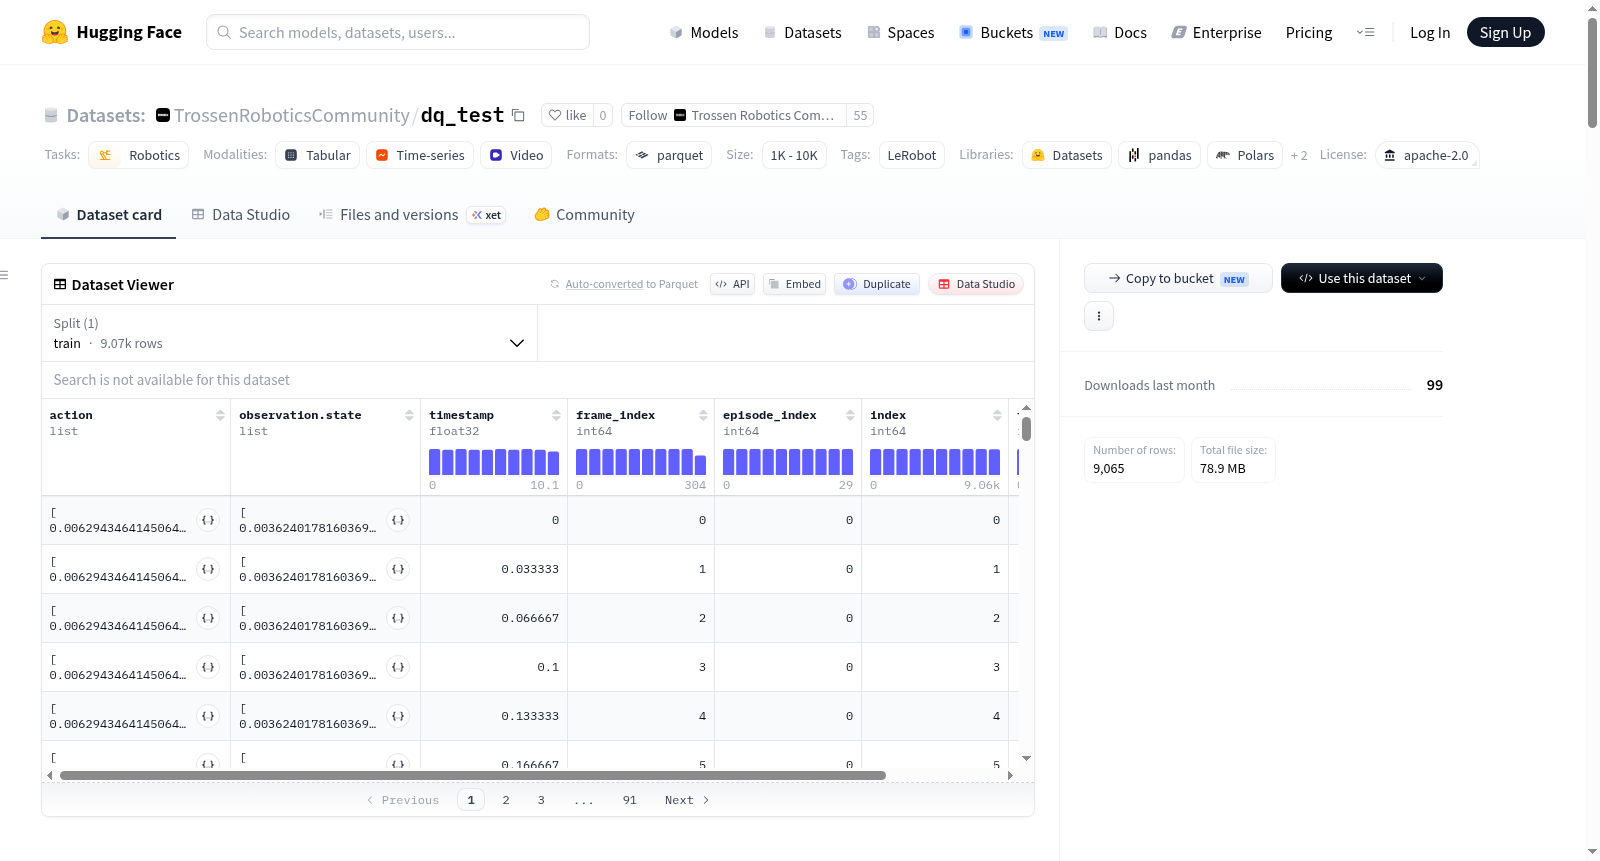
该数据集是一个机器人学数据集,使用LeRobot工具创建,并通过Trossen SDK的trossen_mcap_to_lerobot_v2工具从TrossenMCAP格式转换而来。数据集基于Trossen静止AI机器人平台,包含30个情节,总计9065帧,帧率为30fps。数据以Parquet文件格式存储,总数据文件大小为100MB,视频文件大小为200MB。数据集特征包括观测状态(14个关节位置,如joint_0到joint_6)、动作(14个关节控制)、以及来自多个摄像头的视频观测:高分辨率摄像头、低分辨率摄像头、左腕摄像头和右腕摄像头,每个视频分辨率为480x640像素、3通道(RGB),使用AV1编解码器。此外,还包含时间戳、帧索引、情节索引、索引和任务索引等元数据。数据集仅用于训练,使用Apache 2.0许可证,但主页和论文信息暂未提供。
This dataset is a robotics dataset created using LeRobot and converted from TrossenMCAP format using the Trossen SDK trossen_mcap_to_lerobot_v2 tool. It is based on the Trossen stationary AI robot platform, containing 30 episodes with a total of 9065 frames at 30 fps. The data is stored in Parquet file format, with a total data file size of 100 MB and video file size of 200 MB. Dataset features include observation state (14 joint positions, e.g., joint_0 to joint_6), actions (14 joint controls), and video observations from multiple cameras: high camera, low camera, left wrist camera, and right wrist camera, each with a resolution of 480x640 pixels, 3 channels (RGB), using AV1 codec. Additionally, metadata such as timestamps, frame index, episode index, index, and task index are included. The dataset is intended for training only, licensed under Apache 2.0, but homepage and paper information are currently missing.