ur_box_lid_assembly
收藏资源简介:
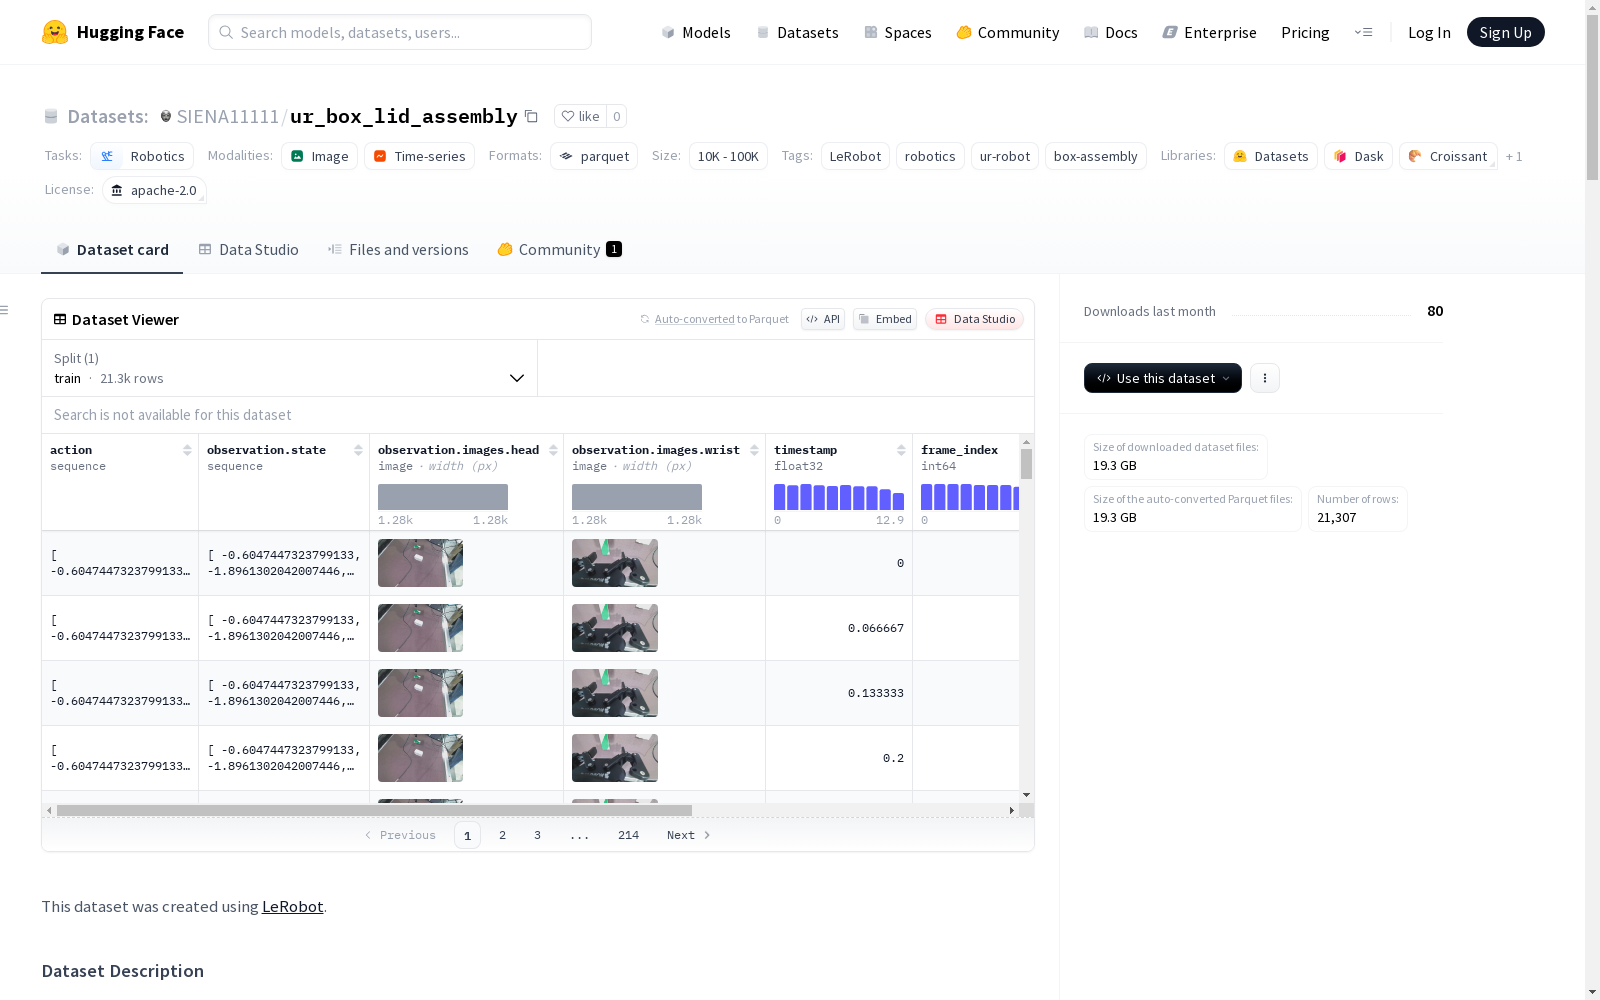
这是一个用于UR机器人盒子装配任务的数据集,包含91个训练集,总共17106帧,采样率为15FPS。动作空间为7维(6个关节加一个夹爪),状态空间为31维,包括关节位置、TCP姿态、关节速度、TCP线性和角速度、TCP力和扭矩等信息。数据集提供两种摄像头视角:头部摄像头和手腕摄像头,均为720x1280x3的分辨率。
This is a dataset for the UR robot box assembly task. It includes 91 training sets, with a total of 17106 frames and a sampling rate of 15 FPS. The action space is 7-dimensional (6 joints plus 1 gripper), while the state space is 31-dimensional, covering joint positions, TCP poses, joint velocities, TCP linear and angular velocities, TCP force and torque information, and other related data. The dataset provides two camera views: the head camera and the wrist camera, both with a resolution of 720x1280x3.
数据集概述
基本信息
- 名称: UR Robot Box and Lid Assembly Dataset
- 作者: SIENA11111
- 发布年份: 2024
- 发布平台: Hugging Face Hub
- 许可证: Apache-2.0
- 任务类别: 机器人学
- 标签: LeRobot, robotics, ur-robot, box-assembly
数据集描述
- 用途: UR机器人执行盒子组装任务的数据集
- 训练集: 91个训练片段
- 总帧数: 17,106帧
- 采样率: 15 FPS
- 动作空间: 7维(6个关节 + 夹爪)
- 状态空间: 31维,包括:
- 关节位置(6个关节 + 夹爪)
- TCP位姿(位置和方向)
- 关节速度
- TCP线速度和角速度
- TCP力和扭矩
- 摄像头视图:
- 头部摄像头: 720x1280x3
- 手腕摄像头: 720x1280x3
数据集结构
- 数据格式: Parquet文件
- 数据路径:
data/chunk-{episode_chunk:03d}/episode_{episode_index:06d}.parquet - 特征:
action: 7维浮点数组,表示关节和夹爪动作observation.state: 31维浮点数组,表示机器人状态observation.images.head: 头部摄像头图像(720x1280x3)observation.images.wrist: 手腕摄像头图像(720x1280x3)timestamp: 时间戳frame_index: 帧索引episode_index: 片段索引index: 索引task_index: 任务索引
元数据
- 代码库版本: v2.1
- 机器人类型: ur
- 总片段数: 100
- 总帧数: 18,757
- 总任务数: 1
- 总视频数: 0
- 总块数: 1
- 块大小: 1,000
- FPS: 15
- 分割: 训练集(0:100)
引用
bibtex @misc{ur_box_lid_assembly, author = {SIENA11111}, title = {UR Robot Box and Lid Assembly Dataset}, year = {2024}, publisher = {Hugging Face}, journal = {Hugging Face Hub}, howpublished = {url{https://huggingface.co/datasets/SIENA11111/ur_box_lid_assembly}} }
相关链接
- 主页: https://github.com/huggingface/lerobot