tv-config1-green-red-blue
收藏资源简介:
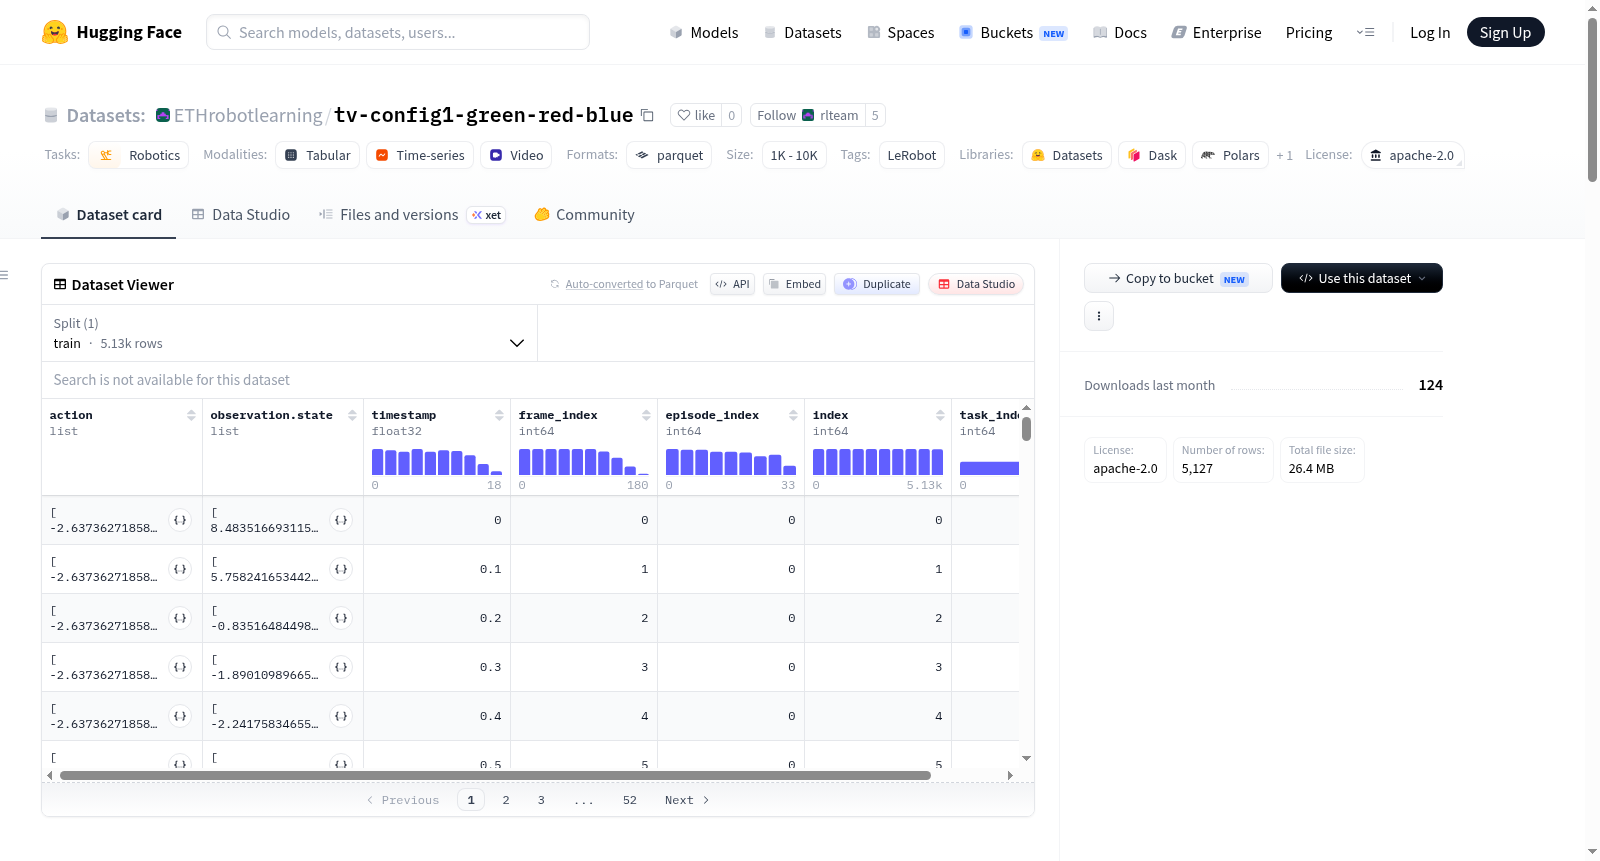
该数据集由LeRobot项目创建,是一个用于机器人学研究的演示数据集。数据集包含机器人执行任务时的动作、状态观测和视觉观测记录。具体而言,数据记录了6自由度机器人(关节包括肩部平移、肩部抬升、肘部弯曲、腕部弯曲、腕部旋转和夹爪)的关节位置动作(action)和对应的关节位置状态观测(observation.state)。同时,数据集提供了来自机器人前置摄像头的RGB视频观测(observation.images.front),分辨率为640x480,帧率为10 fps。数据集共包含34个episodes(总帧数5127),涵盖了3个不同的任务。数据以分块的Parquet文件格式组织,并已预先划分为训练集。该数据集适用于机器人模仿学习、策略学习、状态估计等任务。
This dataset is created by the LeRobot project and serves as a demonstration dataset for robotics research. It contains recordings of robot actions, state observations, and visual observations during task execution. Specifically, the data includes joint position actions (action) and corresponding joint position state observations (observation.state) for a 6-degree-of-freedom robot (joints include shoulder translation, shoulder elevation, elbow flexion, wrist flexion, wrist rotation, and gripper). Additionally, the dataset provides RGB video observations (observation.images.front) from the robots front camera, with a resolution of 640x480 and a frame rate of 10 fps. The dataset comprises 34 episodes (total frames 5127), covering 3 different tasks. The data is organized in chunked Parquet file format and is pre-divided into a training set. It is suitable for tasks such as robot imitation learning, policy learning, and state estimation.