gherrera-22/so101_pick_spell
收藏资源简介:
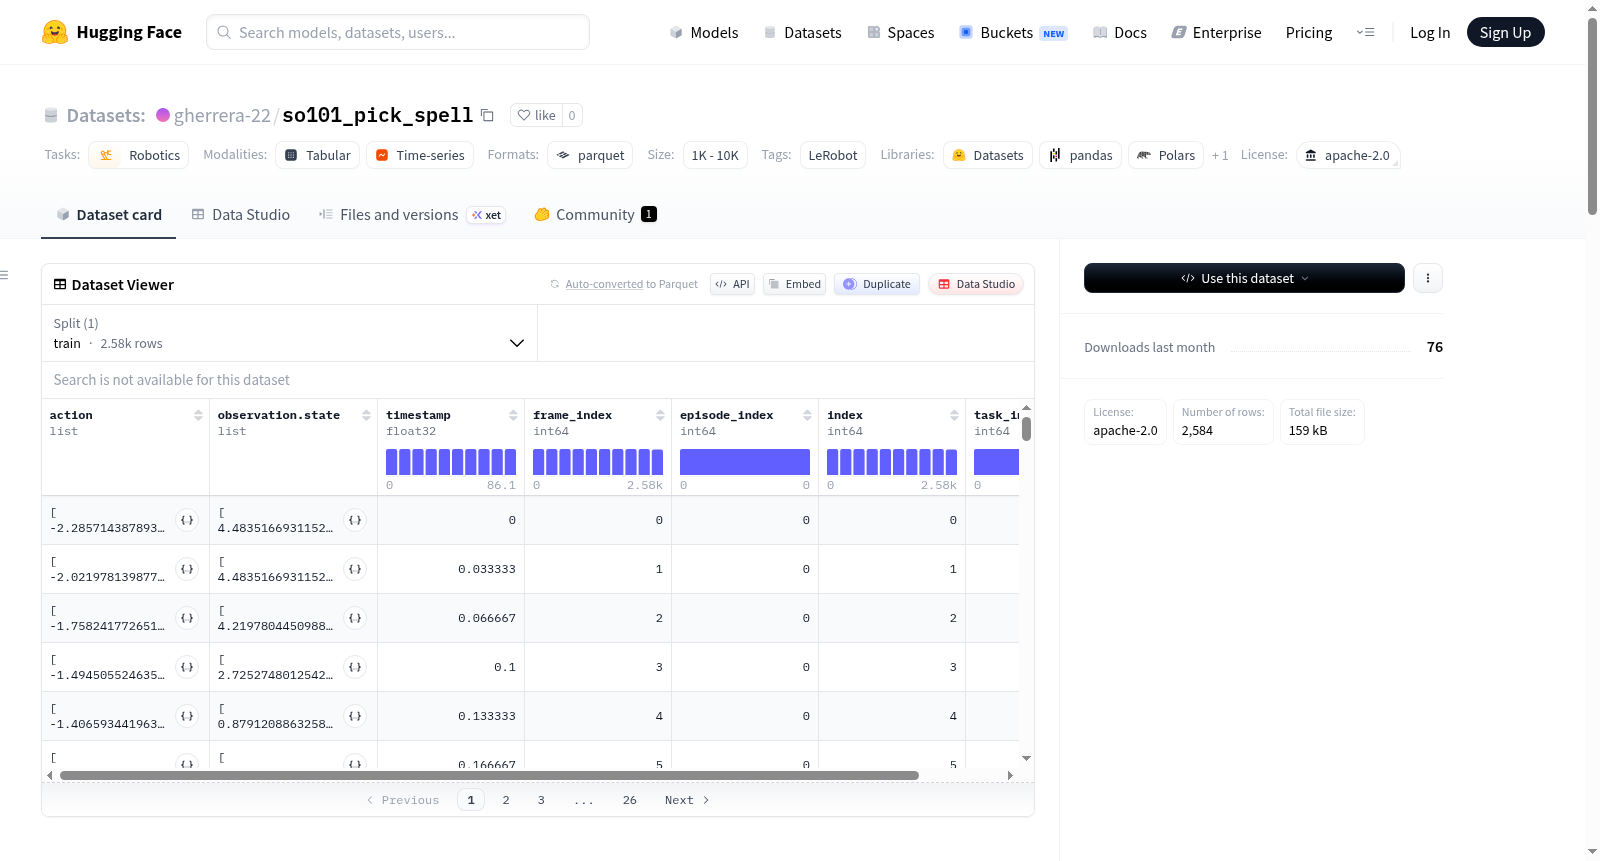
该数据集使用LeRobot创建,包含机器人操作相关的数据。数据集结构包括:代码库版本v3.0,机器人类型为so_follower,总帧数为2584,总任务数为1,数据文件大小为100MB,视频文件大小为200MB,帧率为30fps。数据特征包括动作(action)、观测状态(observation.state)、时间戳(timestamp)、帧索引(frame_index)、片段索引(episode_index)、索引(index)和任务索引(task_index)。动作和观测状态包含6个浮点型数据,分别对应机器人的肩部、肘部、腕部和夹爪的位置信息。
This dataset was created using LeRobot and contains data related to robotic operations. The dataset structure includes: codebase version v3.0, robot type so_follower, total frames 2584, total tasks 1, data file size 100MB, video file size 200MB, frame rate 30fps. Data features include action, observation.state, timestamp, frame_index, episode_index, index, and task_index. Action and observation.state contain 6 float32 data corresponding to the position information of the robots shoulder, elbow, wrist, and gripper.