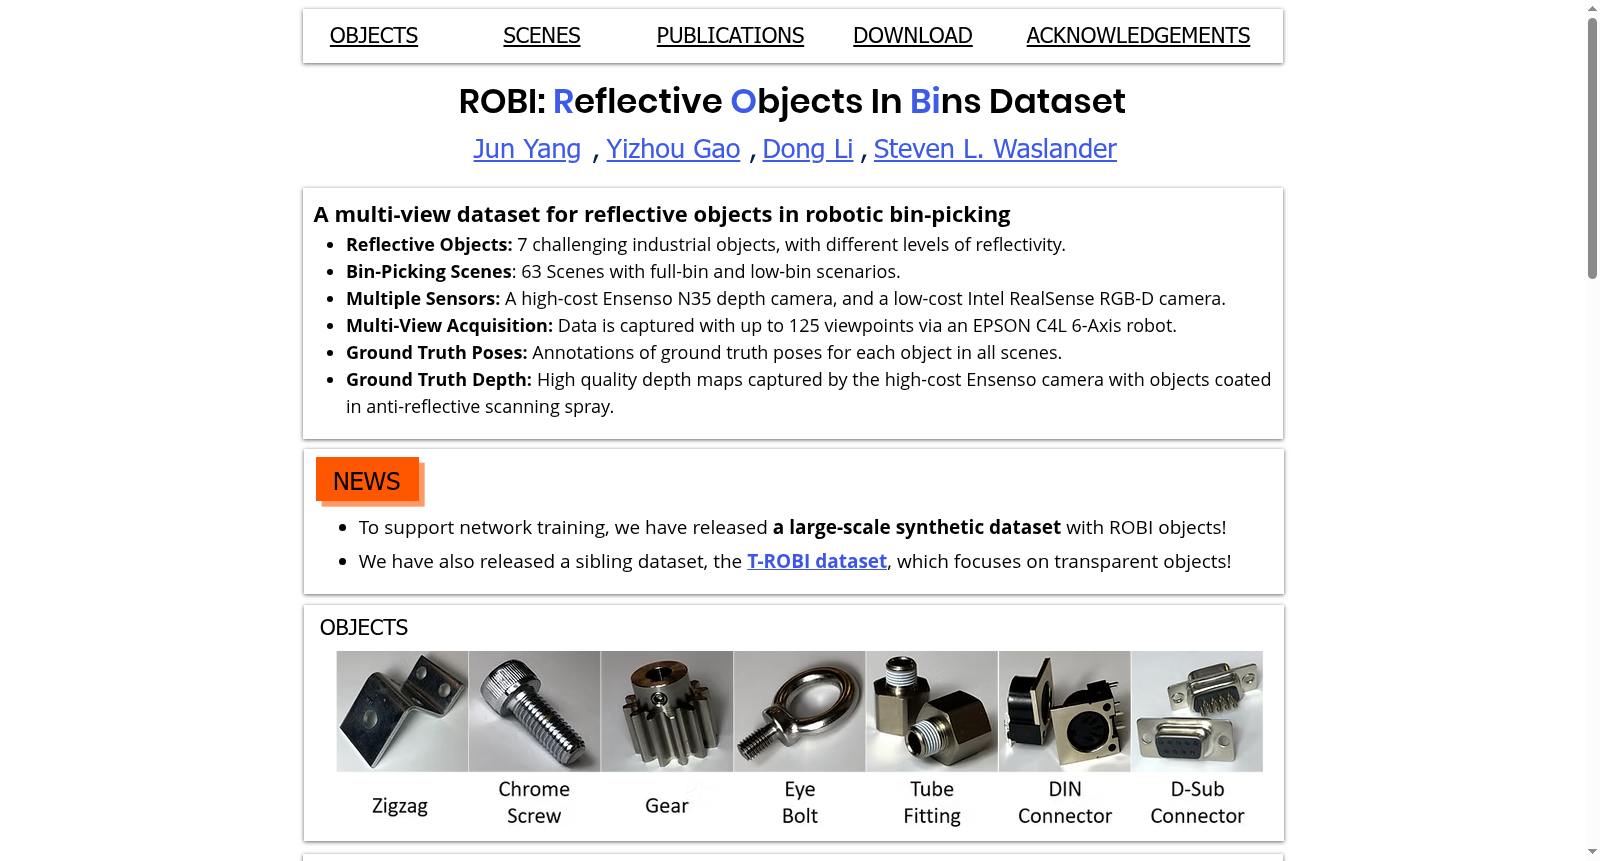
ROBI (Reflective Objects in BIns) dataset
收藏资源简介:
ROBI数据集是由多伦多大学航空航天研究所和机器人研究所创建的,专注于机器人拣选场景中反射性物体的6D姿态估计和多视角深度融合。数据集包含63个拣选场景,使用高成本的Ensenso传感器和低成本的RealSense传感器捕捉,总计约8000张图像。数据集创建过程中,通过在物体上喷涂反反射扫描喷雾来获取高质量的地面实况深度图。ROBI数据集旨在解决工业环境中由于反射性物体导致的深度数据质量下降和场景严重混乱的问题,为机器人感知技术提供挑战性的基准数据。
The ROBI dataset was created by the Aerospace Institute and the Robotics Institute at the University of Toronto, focusing on 6D pose estimation and multi-view depth fusion for reflective objects in robotic bin-picking scenarios. The dataset consists of 63 bin-picking scenarios, captured using both high-cost Ensenso sensors and low-cost RealSense sensors, with a total of approximately 8,000 images. During the dataset construction process, high-quality ground-truth depth maps were obtained by spraying anti-reflective scanning spray onto the objects. The ROBI dataset aims to address the issues of degraded depth data quality and severe scene clutter caused by reflective objects in industrial environments, providing challenging benchmark data for robotic perception technologies.