Kubric; HUMOTO
收藏资源简介:
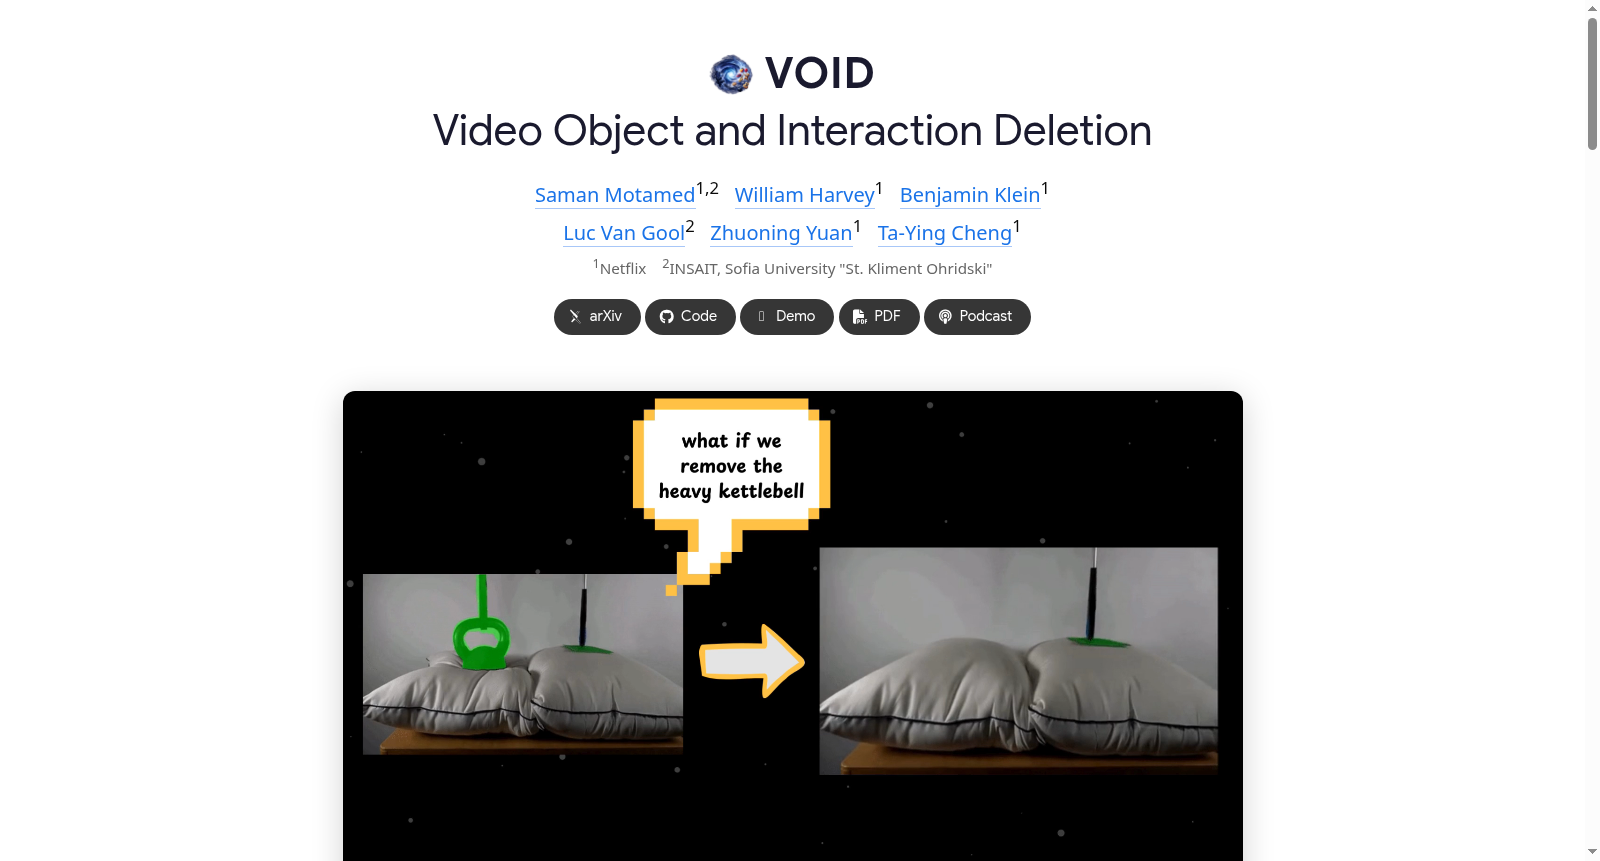
该研究构建了基于Kubric物理仿真引擎和HUMOTO人体运动捕捉的双模态数据集,旨在解决动态物体移除后的物理一致性推理问题。Kubric数据集包含1900组刚性物体交互视频对,模拟碰撞、坠落等场景;HUMOTO提供4500组人体-物体互动数据,通过随机化纹理和摄像机轨迹增强泛化能力。数据集通过精确标注物体移除前后的时空变化,为视频编辑模型提供物理因果关系的监督信号,主要应用于影视特效和智能视频编辑领域,推动生成模型在动态场景中的因果推理能力。
This study constructs a bimodal dataset based on the Kubric physics simulation engine and HUMOTO human motion capture, aiming to solve the problem of physical consistency reasoning after dynamic object removal. The Kubric dataset includes 1,900 rigid object interaction video pairs, simulating scenarios such as collisions and falls; the HUMOTO dataset provides 4,500 sets of human-object interaction data, enhancing generalization capability by randomizing textures and camera trajectories. The dataset provides supervision signals of physical causal relationships for video editing models through precise annotations of spatiotemporal changes before and after object removal. It is mainly applied in the fields of visual effects and intelligent video editing, promoting the causal reasoning capability of generative models in dynamic scenes.