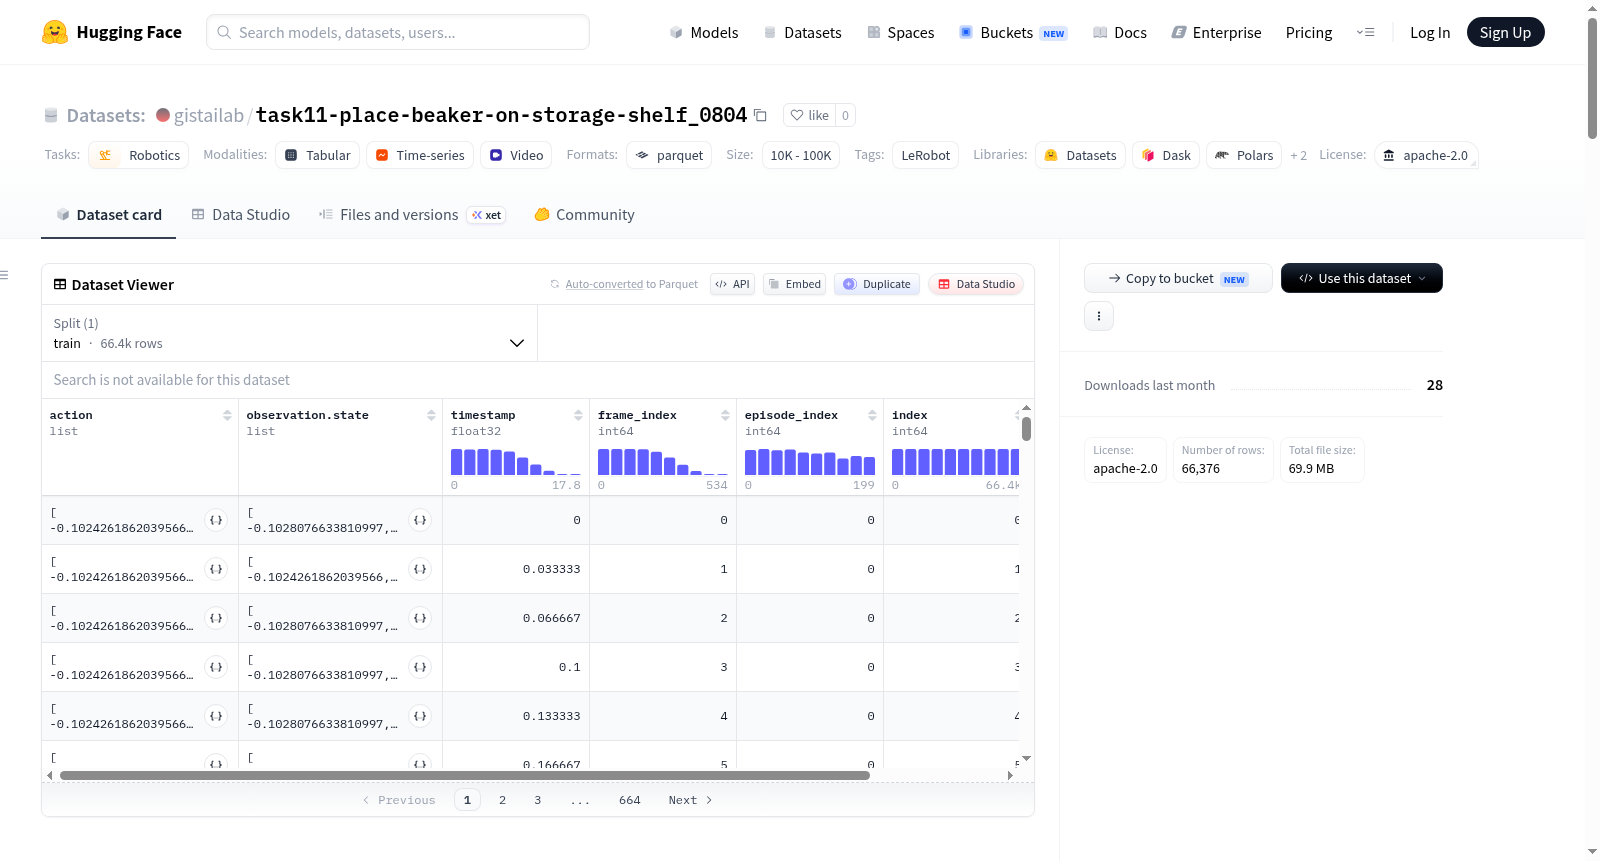
task11-place-beaker-on-storage-shelf_0804
收藏资源简介:
该数据集是用于机器人操作任务的开源数据集,具体任务为“将烧杯放置在存储架上”(place beaker on storage shelf)。数据集采用LeRobot格式,由移动AI机器人(mobileai_robot)收集。数据包含200个演示片段(episodes),总计66376帧,帧率为30fps,所有数据均用于训练(无验证/测试划分)。每个样本包含:16维动作向量(左右手臂各6个关节位置以及移动基座的线速度和角速度)、16维观测状态(与动作结构相同,代表当前机器人状态)、三个摄像头视角的高清图像(高视角cam_high、左腕cam_left_wrist、右腕cam_right_wrist,均为480×640像素,RGB,H.264编码视频),以及时间戳、帧索引、片段索引、全局索引和任务索引等元数据。数据以Parquet文件存储结构化数据,视频以MP4文件存储。该数据集适用于机器人模仿学习、行为克隆、强化学习等任务,尤其适合需要多视角视觉输入和连续控制的研究场景。
This dataset is an open-source dataset for robot manipulation tasks, specifically the task of place beaker on storage shelf. It is formatted in LeRobot format and collected by a mobile AI robot (mobileai_robot). The dataset contains 200 demonstration episodes, totaling 66,376 frames at 30 fps, all used for training (no validation/test split). Each sample includes: a 16-dimensional action vector (6 joint positions for each arm plus linear and angular velocity of the mobile base), a 16-dimensional observation state (same structure as actions, representing current robot state), high-definition images from three camera views (cam_high, cam_left_wrist, cam_right_wrist, all 480×640 pixels, RGB, H.264 encoded video), as well as metadata such as timestamps, frame indices, episode indices, global indices, and task indices. Data is stored as Parquet files for structured data and MP4 files for videos. The dataset is suitable for robot imitation learning, behavioral cloning, reinforcement learning, and other tasks, especially for research scenarios requiring multi-view visual input and continuous control.
数据集概述
基本信息
- 数据集名称:task11-place-beaker-on-storage-shelf_0804
- 许可证:Apache-2.0
- 任务类别:机器人(Robotics)
- 标签:LeRobot
- 创建工具:由LeRobot创建
数据集结构
- 版本:codebase v3.0
- 机器人类型:mobileai_robot
- 总轨迹数:200
- 总帧数:66,376
- 任务数:1
- 块大小:1,000
- 数据文件大小:约100 MB
- 视频文件大小:约200 MB
- 帧率:30 fps
数据划分
- 训练集:0至200(全部200个轨迹用于训练)
数据特征
动作与状态特征
- 动作:包含16维特征,涉及左右机械臂各6个关节位置、左右托架关节位置、移动速度(x.vel)和角速度(theta.vel)。
- 观测状态:与动作特征维度相同,共16维。
图像观测
- cam_high:高视角摄像头,分辨率480×640,3通道,H.264编码,30 fps。
- cam_left_wrist:左手腕摄像头,分辨率480×640,3通道,H.264编码,30 fps。
- cam_right_wrist:右手腕摄像头,分辨率480×640,3通道,H.264编码,30 fps。
其他特征
- timestamp:时间戳(float32)
- frame_index:帧索引(int64)
- episode_index:轨迹索引(int64)
- index:索引(int64)
- task_index:任务索引(int64)
数据存储路径
- 数据文件:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频文件:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
引用信息
- BibTeX:暂无可用引用信息。