SemanticSpray++
收藏资源简介:
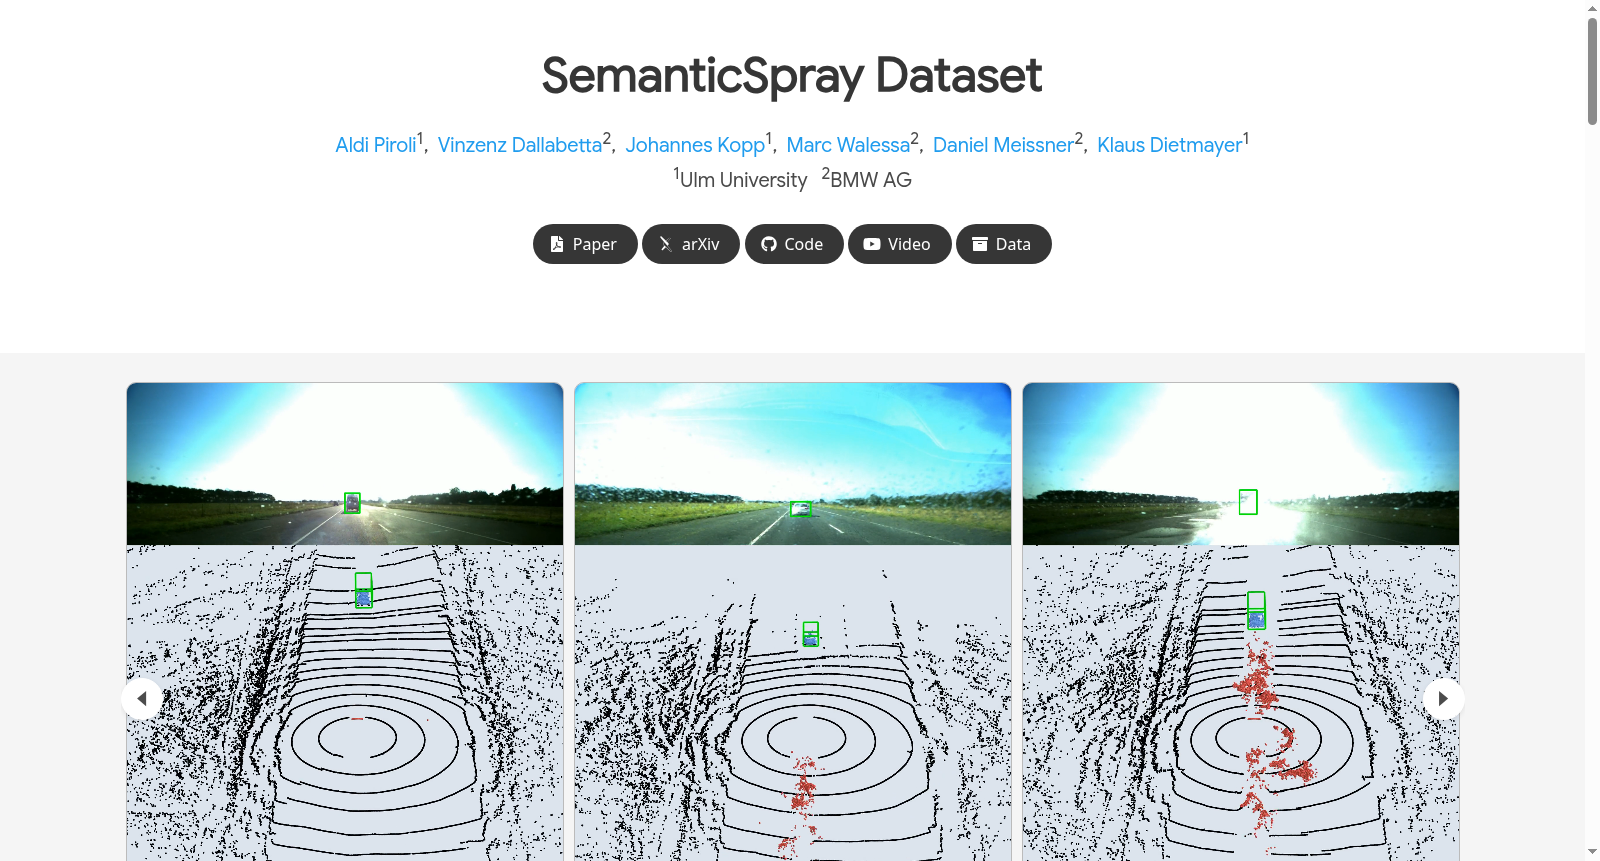
SemanticSpray++数据集由乌尔姆大学测量、控制及微技术研究所创建,专注于自动驾驶在湿滑路面条件下的多模态数据标注。该数据集包含36个场景,涵盖不同速度和车辆距离,提供相机、激光雷达和雷达的数据标注,包括2D边界框、3D边界框和雷达目标的语义标签。创建过程中,数据集基于RoadSpray数据集,通过增加标注扩展了其功能。SemanticSpray++数据集主要用于评估和改进自动驾驶系统在湿滑路面条件下的感知能力,解决现有数据集中缺乏此类条件下多模态标注的问题。
The SemanticSpray++ dataset was developed by the Institute of Measurement, Control and Microtechnology at Ulm University, focusing on multi-modal data annotation for autonomous driving under slippery road conditions. This dataset comprises 36 scenarios covering various driving speeds and inter-vehicle distances, and provides annotated data from cameras, LiDAR and radar sensors, including 2D bounding boxes, 3D bounding boxes and semantic labels for radar targets. Built upon the original RoadSpray dataset, its functionality was expanded by adding additional annotations during the development process. The SemanticSpray++ dataset is primarily designed to evaluate and enhance the perception capabilities of autonomous driving systems under slippery road conditions, addressing the gap in existing datasets that lack multi-modal annotations for such scenarios.