Lisette1231/20260425_flipbreadtopot3
收藏资源简介:
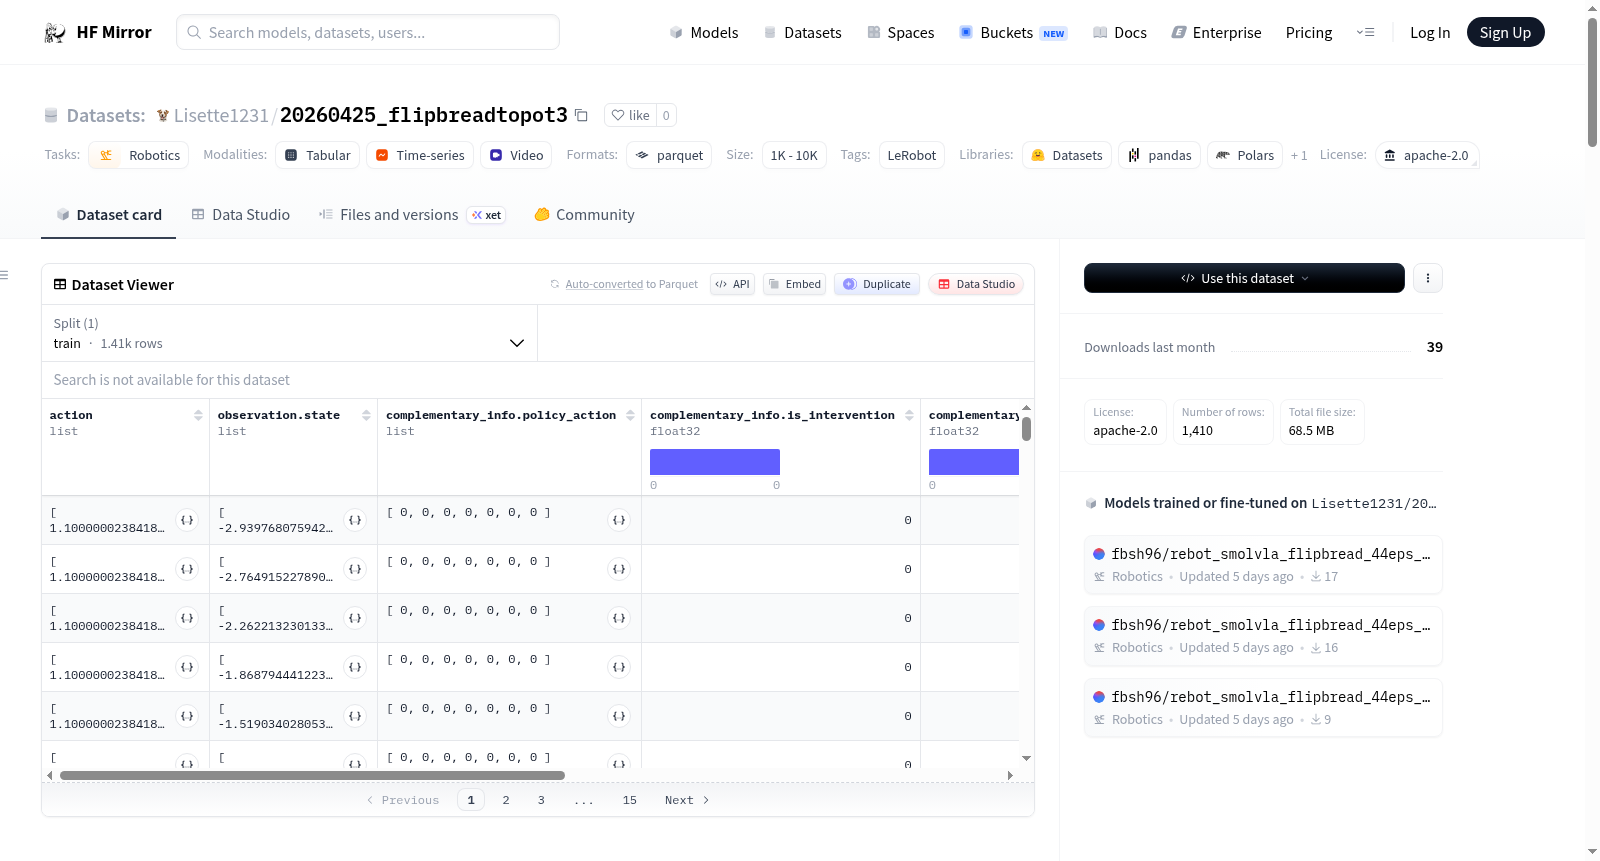
这是一个机器人操作数据集,包含4个完整操作序列(episodes),总计1410帧数据,涉及1个特定任务。数据集记录了机器人7个关节(肩部平移、肩部升降、肘部弯曲、腕部弯曲、腕部偏航、腕部旋转和夹持器)的位置动作和观测状态,以及来自手腕和前置摄像头的视频数据(分辨率480x640,30帧/秒)。此外还包含干预标记、时间戳、帧索引等补充信息。数据以parquet格式存储,总数据量约100MB,视频文件约200MB。
This is a robotic manipulation dataset containing 4 complete episodes with a total of 1410 frames for 1 specific task. It records positional actions and observation states of 7 robot joints (shoulder pan, shoulder lift, elbow flex, wrist flex, wrist yaw, wrist roll, and gripper), along with video data from wrist and front cameras (480x640 resolution, 30fps). Additional information includes intervention flags, timestamps, frame indices, etc. Data is stored in parquet format with approximately 100MB for data files and 200MB for video files.