ywxia/fold_new_gt
收藏资源简介:
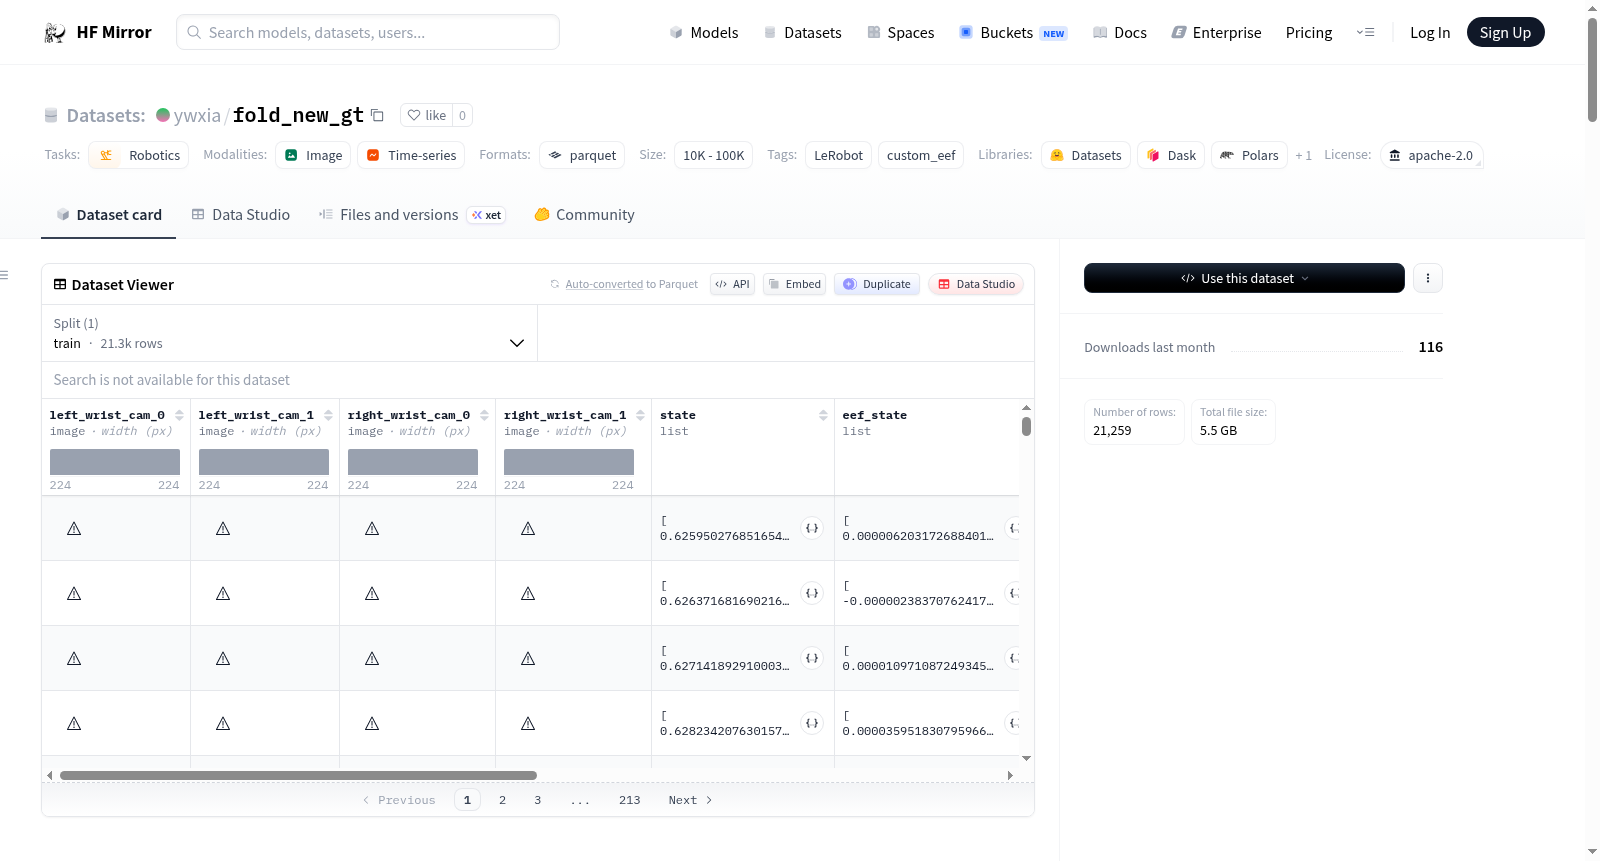
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot - custom_eef configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). ## Dataset Description ## Data Distribution Overview  This figure summarizes the data distribution of the **ywxia/fold_new_gt** dataset, auto-generated after each conversion via `analysis/postprocess_with_overview.py`. It shows episode-length distribution, the 3-D EEF workspace, per-dimension state histograms, per-arm action magnitudes, and a sample of frames from each camera. **Task:** fold the box on the desk **Episodes:** 59 | **Frames:** 21259 | **FPS:** 15 | **Robot:** custom_eef ## Gripper Data Distribution Raw exported action-space gripper channels: | Arm | Action dim | Mean | Std | Min | Max | Median | P99 | Exact zero | | --- | ---: | ---: | ---: | ---: | ---: | ---: | ---: | ---: | | left | 6 | 1.0000 | 0.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 0.0% | | right | 13 | 1.0000 | 0.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 0.0% | These numbers are computed from the raw dataset action channels before any ACT delta or rot6d transforms. - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v2.1", "robot_type": "custom_eef", "total_episodes": 59, "total_frames": 21259, "total_tasks": 1, "total_videos": 0, "total_chunks": 1, "chunks_size": 1000, "fps": 15, "splits": { "train": "0:59" }, "data_path": "data/chunk-{episode_chunk:03d}/episode_{episode_index:06d}.parquet", "video_path": "videos/chunk-{episode_chunk:03d}/{video_key}/episode_{episode_index:06d}.mp4", "features": { "left_wrist_cam_0": { "dtype": "image", "shape": [ 224, 224, 3 ], "names": [ "height", "width", "channel" ] }, "left_wrist_cam_1": { "dtype": "image", "shape": [ 224, 224, 3 ], "names": [ "height", "width", "channel" ] }, "right_wrist_cam_0": { "dtype": "image", "shape": [ 224, 224, 3 ], "names": [ "height", "width", "channel" ] }, "right_wrist_cam_1": { "dtype": "image", "shape": [ 224, 224, 3 ], "names": [ "height", "width", "channel" ] }, "state": { "dtype": "float32", "shape": [ 7 ], "names": [ "state" ] }, "eef_state": { "dtype": "float32", "shape": [ 14 ], "names": [ "eef_state" ] }, "actions": { "dtype": "float32", "shape": [ 14 ], "names": [ "actions" ] }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
--- 许可证:Apache-2.0 任务类别: - 机器人学 标签: - LeRobot - custom_eef 配置项: - 配置名称:default 数据文件:data/*/*.parquet --- 本数据集基于[LeRobot](https://github.com/huggingface/lerobot)构建。 ## 数据集说明 ## 数据分布概览  本图表汇总了**ywxia/fold_new_gt**数据集的数据分布情况,该图表通过`analysis/postprocess_with_overview.py`在每次数据转换后自动生成。其涵盖了回合长度分布、三维末端执行器(End Effector, EEF)工作空间、各维度状态直方图、各机械臂动作幅值分布,以及各摄像头采集的帧样本。 **任务:** 将桌面上的纸盒折叠完成 **回合数:** 59 | **总帧数:** 21259 | **帧率:** 15 | **机械臂:** custom_eef ## 夹持器数据分布 原始导出的动作空间夹持器通道数据如下: | 机械臂 | 动作维度 | 均值 | 标准差 | 最小值 | 最大值 | 中位数 | 99分位数 | 零值占比 | | --- | ---: | ---: | ---: | ---: | ---: | ---: | ---: | ---: | | 左机械臂 | 6 | 1.0000 | 0.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 0.0% | | 右机械臂 | 13 | 1.0000 | 0.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 0.0% | 上述统计值均基于未经ACT增量变换或rot6d旋转变换的原始数据集动作通道计算得到。 - **项目主页:** [需补充更多信息] - **论文:** [需补充更多信息] - **许可证:** Apache-2.0 ## 数据集结构 [meta/info.json](meta/info.json): json { "codebase_version": "v2.1", "robot_type": "custom_eef", "total_episodes": 59, "total_frames": 21259, "total_tasks": 1, "total_videos": 0, "total_chunks": 1, "chunks_size": 1000, "fps": 15, "splits": { "train": "0:59" }, "data_path": "data/chunk-{episode_chunk:03d}/episode_{episode_index:06d}.parquet", "video_path": "videos/chunk-{episode_chunk:03d}/{video_key}/episode_{episode_index:06d}.mp4", "features": { "left_wrist_cam_0": { "dtype": "image", "shape": [ 224, 224, 3 ], "names": [ "height", "width", "channel" ] }, "left_wrist_cam_1": { "dtype": "image", "shape": [ 224, 224, 3 ], "names": [ "height", "width", "channel" ] }, "right_wrist_cam_0": { "dtype": "image", "shape": [ 224, 224, 3 ], "names": [ "height", "width", "channel" ] }, "right_wrist_cam_1": { "dtype": "image", "shape": [ 224, 224, 3 ], "names": [ "height", "width", "channel" ] }, "state": { "dtype": "float32", "shape": [ 7 ], "names": [ "state" ] }, "eef_state": { "dtype": "float32", "shape": [ 14 ], "names": [ "eef_state" ] }, "actions": { "dtype": "float32", "shape": [ 14 ], "names": [ "actions" ] }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } } } ## 引用 **BibTeX格式:** bibtex [需补充更多信息]