salmonHan/record-test_20260527_235303
收藏资源简介:
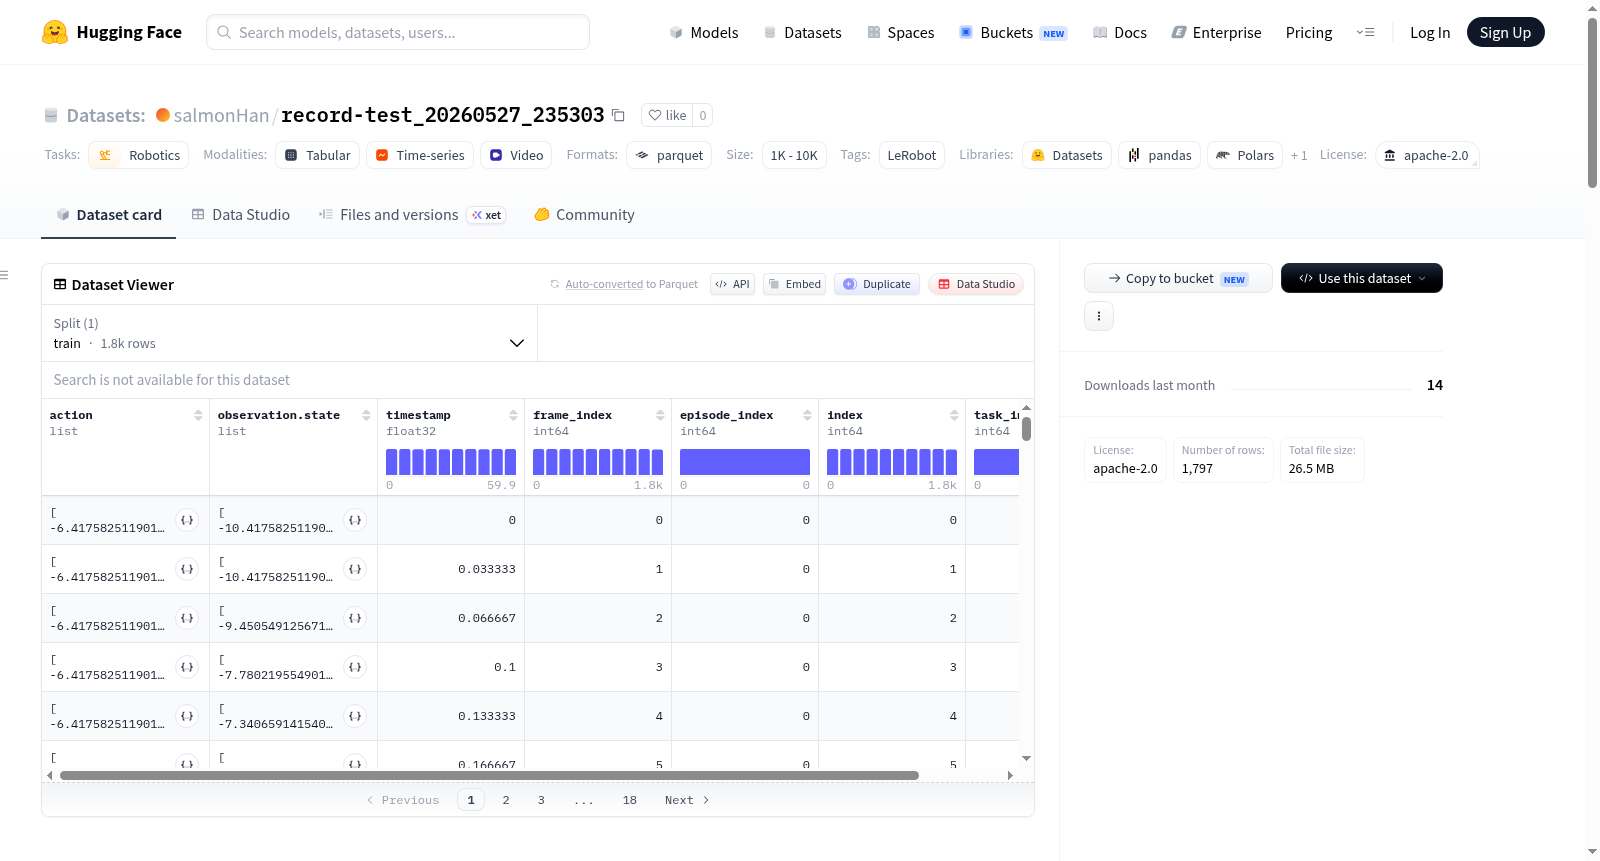
该数据集是一个机器人数据集,使用LeRobot工具创建,专为机器人学习和控制任务设计。数据集包含一个完整的episode,总计1797个帧,对应一个任务。数据以parquet文件格式存储,视频文件以mp4格式存储,帧率为30fps。数据集的特征包括动作(action)、观察状态(observation.state)、前摄像头图像(observation.images.front)、时间戳(timestamp)、帧索引(frame_index)、episode索引(episode_index)、索引(index)和任务索引(task_index)。动作和观察状态均涉及机器人的6个关节位置:肩部平移(shoulder_pan.pos)、肩部提升(shoulder_lift.pos)、肘部弯曲(elbow_flex.pos)、手腕弯曲(wrist_flex.pos)、手腕旋转(wrist_roll.pos)和夹爪位置(gripper.pos),数据类型为float32。前摄像头图像的分辨率为720x1280,3通道(RGB),采用av1编解码器,无音频。数据集适用于机器人控制、模仿学习或强化学习等研究,许可证为Apache-2.0。
This is a robotics dataset developed with the LeRobot toolkit, tailored for robotics learning and control tasks. The dataset contains one full episode, totaling 1797 frames corresponding to a single task. The data is stored in Parquet file format, while the video files are in MP4 format with a frame rate of 30 fps. The dataset includes the following features: action, observation.state, front camera image (observation.images.front), timestamp, frame_index, episode_index, index, and task_index. Both the action and observation.state encompass 6 joint positions of the robot: shoulder_pan.pos, shoulder_lift.pos, elbow_flex.pos, wrist_flex.pos, wrist_roll.pos, and gripper.pos, with a data type of float32. The front camera images have a resolution of 720x1280, 3 RGB channels, utilize the AV1 codec, and contain no audio. This dataset is applicable to research in robotics control, imitation learning, reinforcement learning, and related fields. The license for this dataset is Apache-2.0.