fingernet-100k
收藏资源简介:
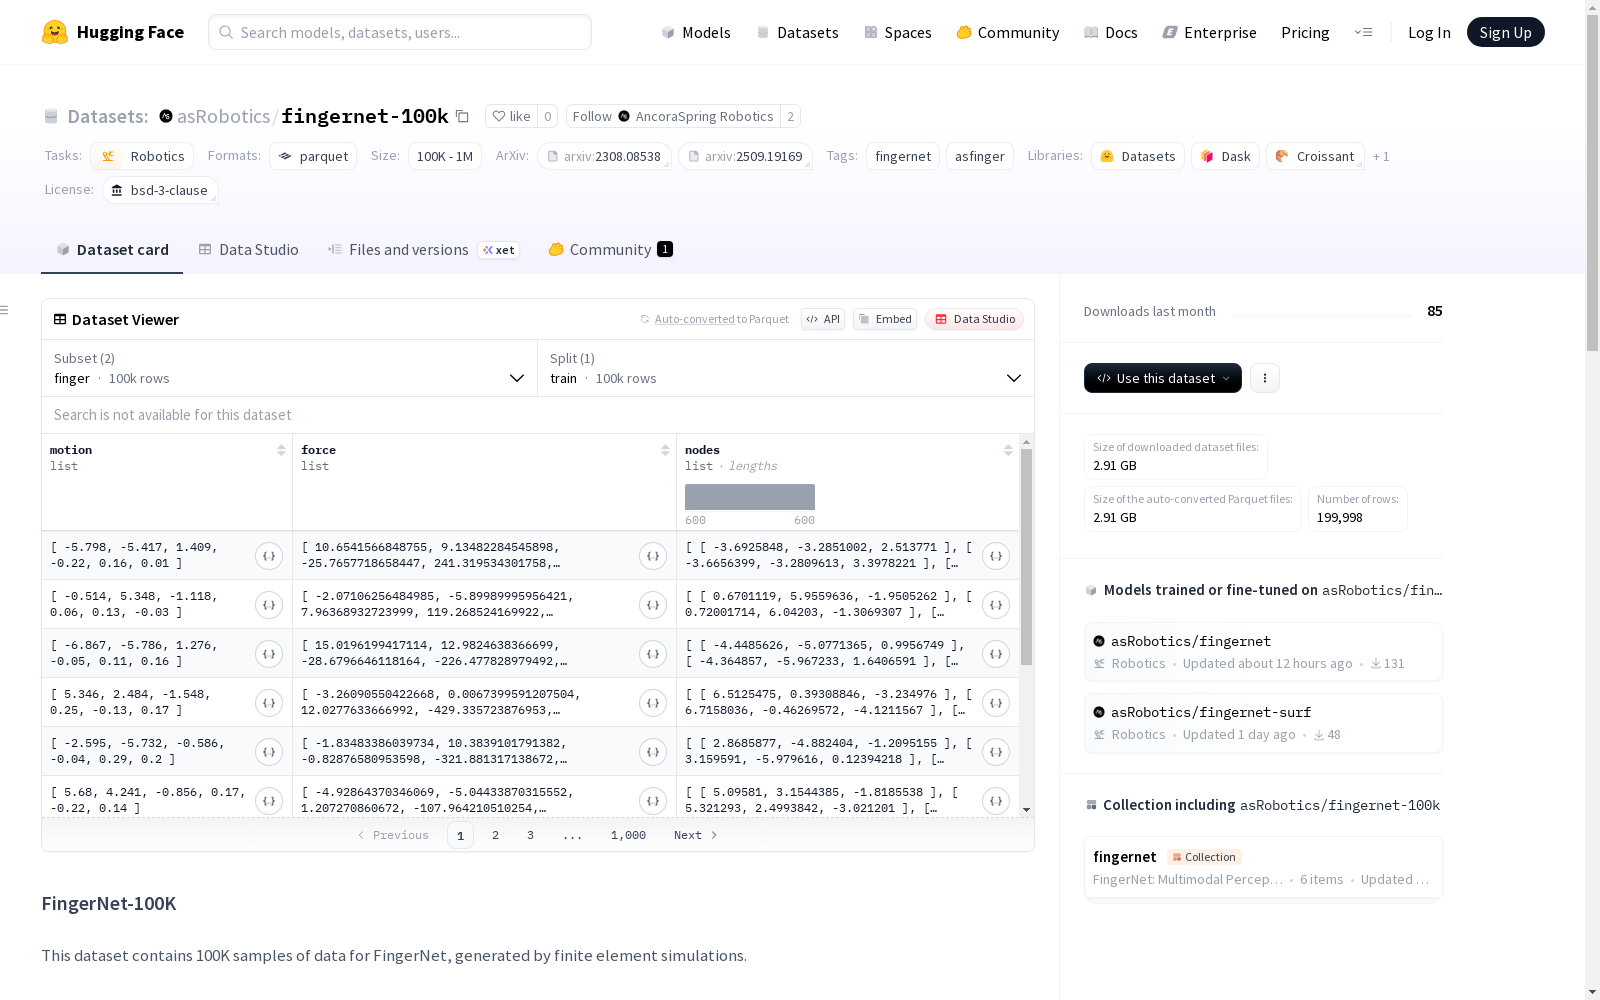
FingerNet-100K数据集包含10万个由有限元仿真生成的FingerNet数据样本。数据集分为两个子集:finger和finger_surf。finger子集包含10万个典型的asFinger样本,而finger_surf子集包含10万个带接触表面的asFinger样本。每个样本包含三个组成部分:手指的6D运动(包括平移和旋转)、手指底面的6D力和力矩以及手指表面节点的3D位移。
The FingerNet-100K dataset contains 100,000 data samples generated via finite element simulation. The dataset is divided into two subsets: finger and finger_surf. The finger subset includes 100,000 typical asFinger samples, while the finger_surf subset contains 100,000 asFinger samples with contact surfaces. Each sample consists of three components: the 6D motion of the finger (including translation and rotation), the 6D force and torque on the bottom surface of the finger, and the 3D displacement of the finger surface nodes.
FingerNet-100K 数据集概述
数据集基本信息
- 许可证:BSD-3-Clause
- 任务类别:机器人学
- 模态:表格数据
- 数据规模:100K<n<1M
- 标签:fingernet, asfinger
数据集配置
数据集包含两个子集配置:
- finger:数据文件路径为
data/finger/data_*.parquet - finger_surf:数据文件路径为
data/finger_surf/data_*.parquet
数据内容
- 数据来源:通过有限元仿真生成的100,000个样本
- finger子集:包含100,000个典型asFinger样本
- finger_surf子集:包含100,000个带接触表面的asFinger样本
数据模式
每个样本包含三个组件:
| 字段名称 | 类型 | 形状 | 描述 |
|---|---|---|---|
motion |
List[float64] |
[6] |
手指的6维运动,包含平移(dx, dy, dz)和旋转(rx, ry, rz),单位分别为mm和rad |
force |
List[float64] |
[6] |
手指底面的6维力和力矩,对应(fx, fy, fz, tx, ty, tz),单位分别为N和Nmm |
nodes |
List[List[float64]] |
[N,3] |
手指N个表面节点的3维位移,每个节点表示为[dx, dy, dz],单位为mm |
使用方法
python from datasets import load_dataset
dataset = load_dataset("asRobotics/fingernet-100k")
访问finger子集
for sample in dataset[finger]: motion = sample[motion] force = sample[force] nodes = sample[nodes]
访问finger_surf子集
for sample in dataset[finger_surf]: motion = sample[motion] force = sample[force] nodes = sample[nodes]
引用信息
如果使用此数据集,请引用以下论文:
bibtex @article{liu2024proprioceptive, title={Proprioceptive learning with soft polyhedral networks}, author={Liu, Xiaobo and Han, Xudong and Hong, Wei and Wan, Fang and Song, Chaoyang}, journal={The International Journal of Robotics Research}, volume = {43}, number = {12}, pages = {1916-1935}, year = {2024}, publisher={SAGE Publications Sage UK: London, England}, doi = {10.1177/02783649241238765} }
bibtex @article{wu2025magiclaw, title={MagiClaw: A Dual-Use, Vision-Based Soft Gripper for Bridging the Human Demonstration to Robotic Deployment Gap}, author={Wu, Tianyu and Han, Xudong and Sun, Haoran and Zhang, Zishang and Huang, Bangchao and Song, Chaoyang and Wan, Fang}, journal={arXiv preprint arXiv:2509.19169}, year={2025} }