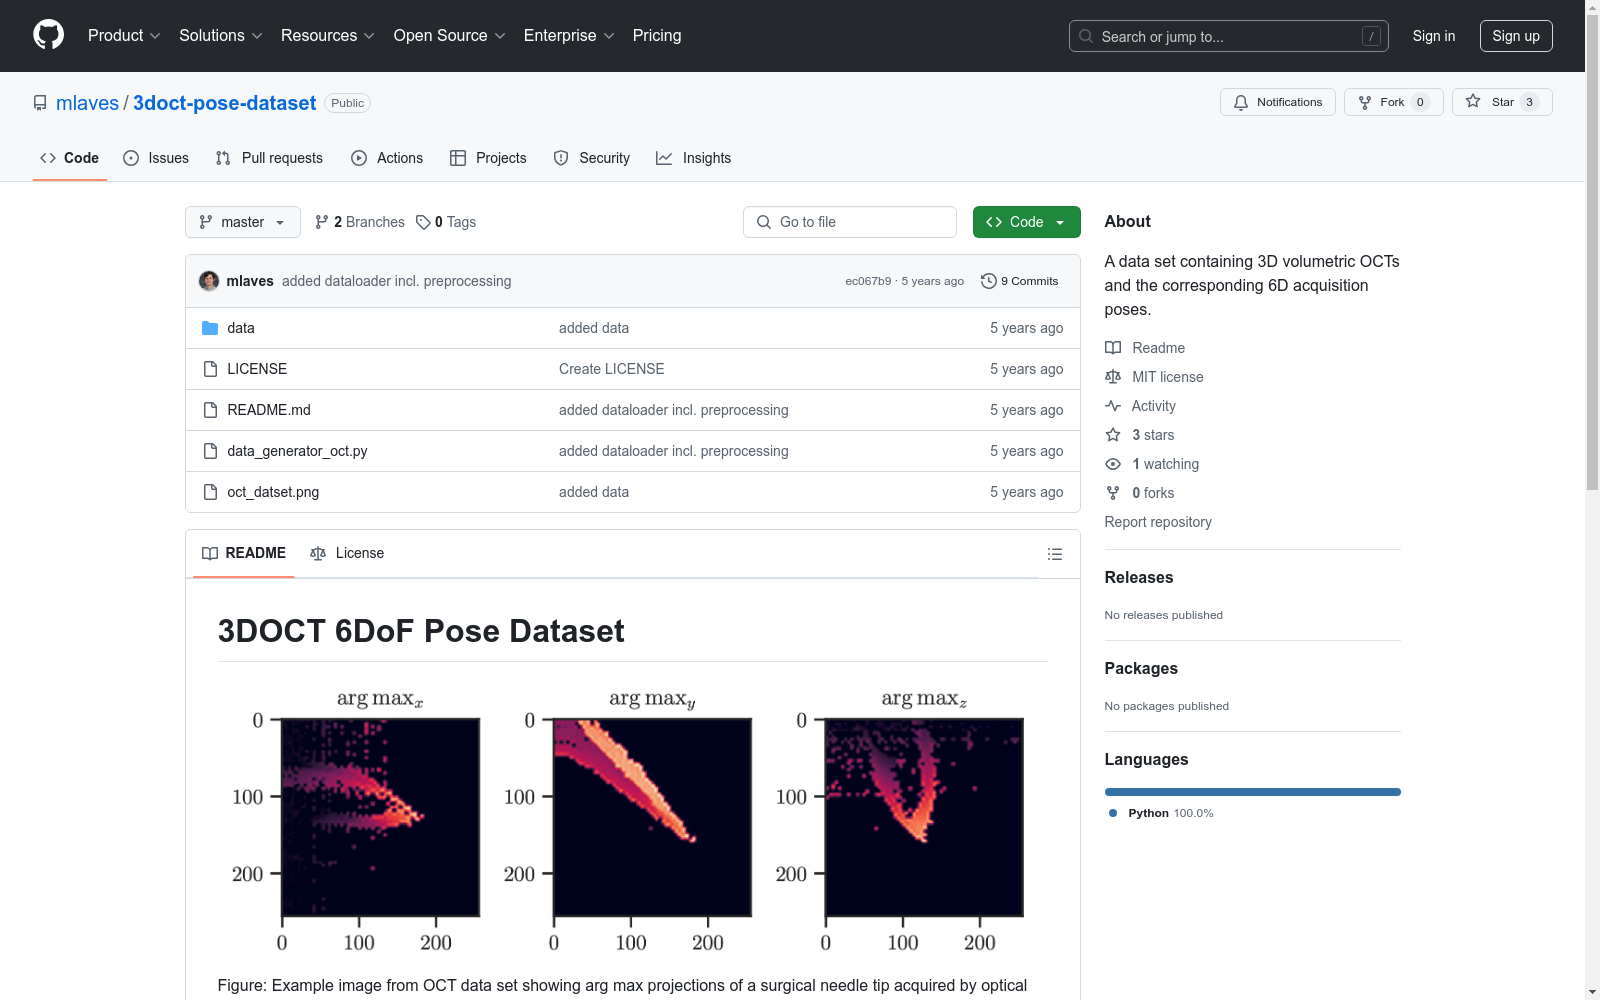
3DOCT 6DoF Pose Dataset
收藏资源简介:
该数据集由将手术针连接到高精度六轴六足机器人(H-826,Physik Instrumente GmbH & Co. KG,德国)上,并通过3D光学相干断层扫描(OCS1300SS,Thorlabs Inc.,美国)观察针尖创建。数据集包含5,000次OCT采集,具有64×64×512体素,覆盖约3×3×3 mm的体积。每次采集都在不同的机器人配置下进行,并标有相应的6DoF姿态。数据具有大量的散斑噪声,这是光学相干断层扫描中的典型现象。
This dataset was created by attaching a surgical needle to a high-precision six-axis hexapod robot (H-826, Physik Instrumente GmbH & Co. KG, Germany) and observing the needle tip through 3D optical coherence tomography (OCS1300SS, Thorlabs Inc., USA). The dataset comprises 5,000 OCT acquisitions, each with a voxel size of 64×64×512, covering a volume of approximately 3×3×3 mm. Each acquisition was performed under different robot configurations and is labeled with the corresponding 6DoF pose. The data exhibits significant speckle noise, a typical phenomenon in optical coherence tomography.
3DOCT 6DoF Pose Dataset 概述
数据集描述
- 创建方式:通过将手术针固定在精密六轴六足机器人(H-826, Physik Instrumente GmbH & Co. KG, Germany)上,并使用3D光学相干断层扫描技术(OCS1300SS, Thorlabs Inc., USA)观察针尖。
- 数据组成:包含5,000次光学相干断层扫描采集,每个采集具有64×64×512体素,覆盖约3×3×3 mm的体积。
- 数据特点:每次采集都是在不同的机器人配置下进行,并标记了相应的6自由度(6DoF)姿态。数据集具有大量的散斑噪声,这是光学相干断层扫描中的典型现象。
数据使用
-
数据加载:可以使用Python代码加载数据集,具体代码示例如下: python import numpy as np
f = np.load("1565077565.9816186.npz") img = f[data] pos = f[pos] img = img.transpose(2, 0, 1) # 调整数据顺序以符合FORTRAN顺序
-
数据预处理:PyTorch数据加载器及预处理代码可在文件
data_generator_oct.py中找到。
引用信息
若使用此数据集,请引用以下文献:
- Laves, MH., Ihler, S., Fast, JF., Kahrs, LA., Ortmaier, T. Well-Calibrated Regression Uncertainty in Medical Imaging with Deep Learning. Medical Imaging with Deep Learning (MIDL), 2020.