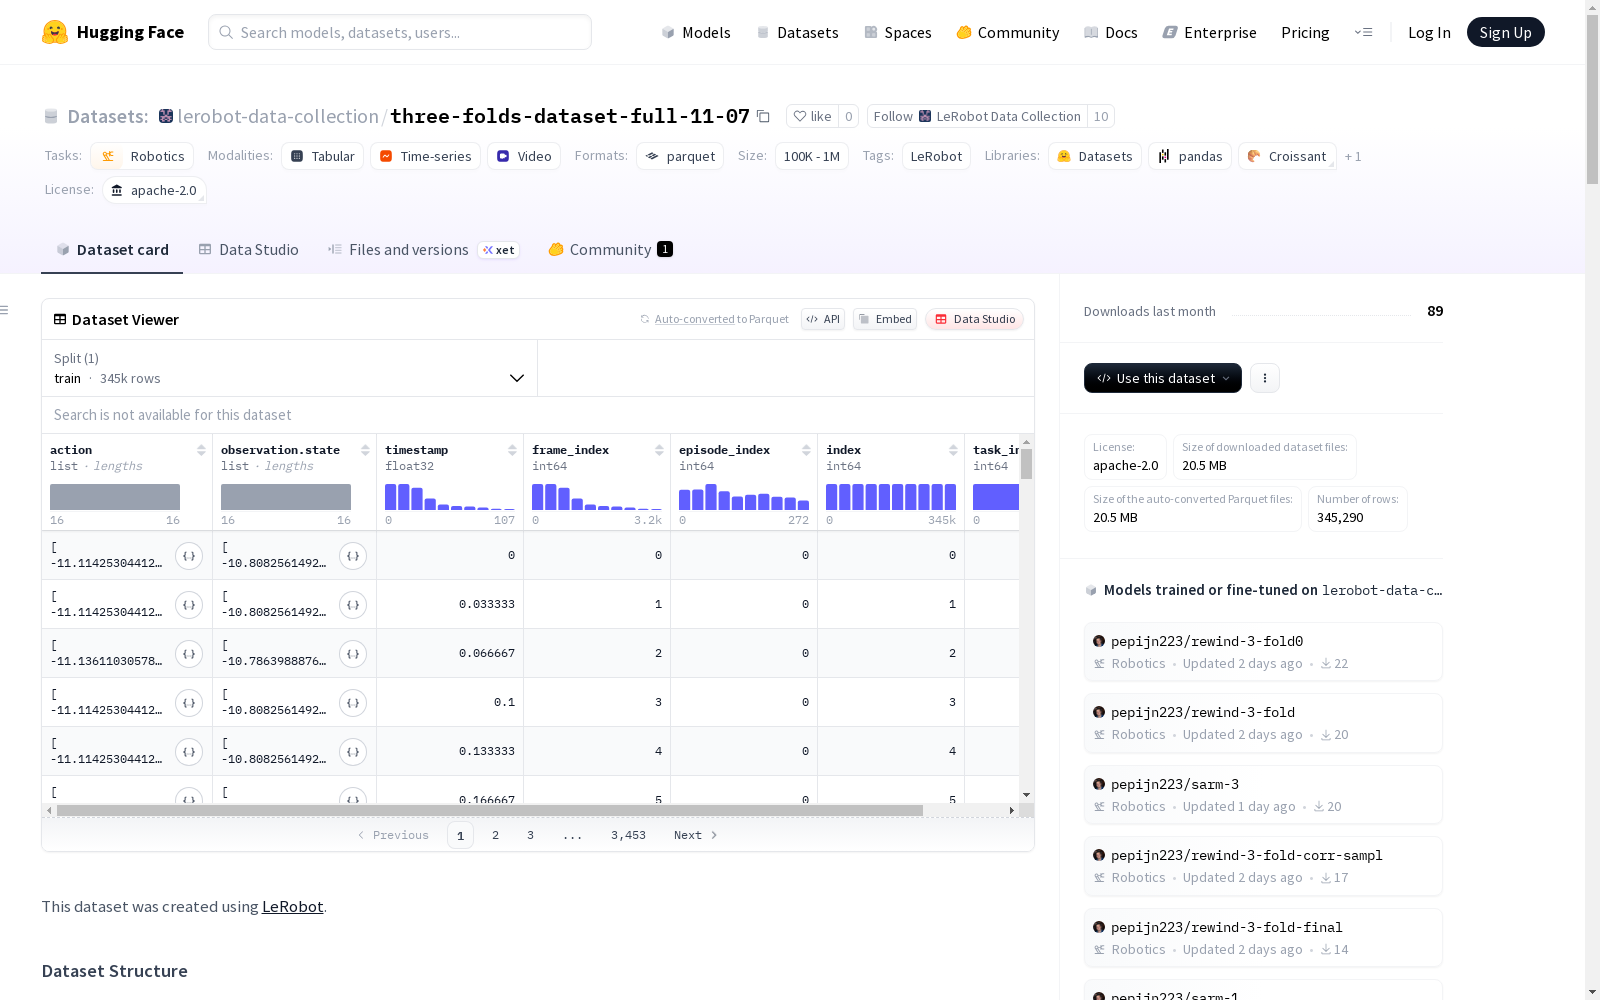
three-folds-dataset-full-11-07
收藏资源简介:
这是一个关于机器人操作的数据集,包含了273个剧集,共计345290帧。数据集使用 Apache-2.0 许可,专注于机器人学任务,特别是机器人手臂的跟踪。数据集以 Parquet 文件格式存储,并伴有相应的视频文件。每个文件包含机器人关节和夹子的位置信息,以及机器人左手腕、右手腕和基部的视频图像。数据集的总数据文件大小为100MB,视频文件大小为500MB,帧率为30fps。训练集包含了所有数据。
This is a robotic manipulation dataset consisting of 273 episodes and a total of 345,290 frames. Licensed under the Apache-2.0 license, this dataset focuses on robotics tasks, specifically robotic arm tracking. It is stored in Parquet file format, paired with corresponding video files. Each file contains the position data of the robot's joints and grippers, alongside video images captured from the robot's left wrist, right wrist, and base. The total size of the data files is 100 MB, while the video files amount to 500 MB, with a frame rate of 30 fps. The training set encompasses all the data in this dataset.
数据集概述
基本信息
- 许可证: Apache-2.0
- 任务类别: 机器人学
- 标签: LeRobot
- 代码库版本: v3.0
- 机器人类型: openarms_follower
数据集规模
- 总情节数: 273
- 总帧数: 345290
- 总任务数: 1
- 数据切块大小: 1000
- 数据文件大小: 100 MB
- 视频文件大小: 500 MB
- 帧率: 30 FPS
数据划分
- 训练集: 所有273个情节
数据结构
数据文件路径
- 数据路径:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频路径:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
特征描述
动作特征
- 名称: action
- 数据类型: float32
- 形状: [16]
- 关节位置:
- 右侧关节1-7位置
- 右侧夹爪位置
- 左侧关节1-7位置
- 左侧夹爪位置
状态观测
- 名称: observation.state
- 数据类型: float32
- 形状: [16]
- 关节位置:
- 右侧关节1-7位置
- 右侧夹爪位置
- 左侧关节1-7位置
- 左侧夹爪位置
图像观测
-
左腕摄像头:
- 分辨率: 480×640×3
- 视频编码: AV1
- 像素格式: yuv420p
- 非深度图
- 无音频
-
右腕摄像头:
- 分辨率: 480×640×3
- 视频编码: AV1
- 像素格式: yuv420p
- 非深度图
- 无音频
-
基座摄像头:
- 分辨率: 480×640×3
- 视频编码: AV1
- 像素格式: yuv420p
- 非深度图
- 无音频
索引特征
- 时间戳: float32, 形状[1]
- 帧索引: int64, 形状[1]
- 情节索引: int64, 形状[1]
- 索引: int64, 形状[1]
- 任务索引: int64, 形状[1]
创建信息
- 创建工具: LeRobot (https://github.com/huggingface/lerobot)