02062026_single_plate_pick
收藏资源简介:
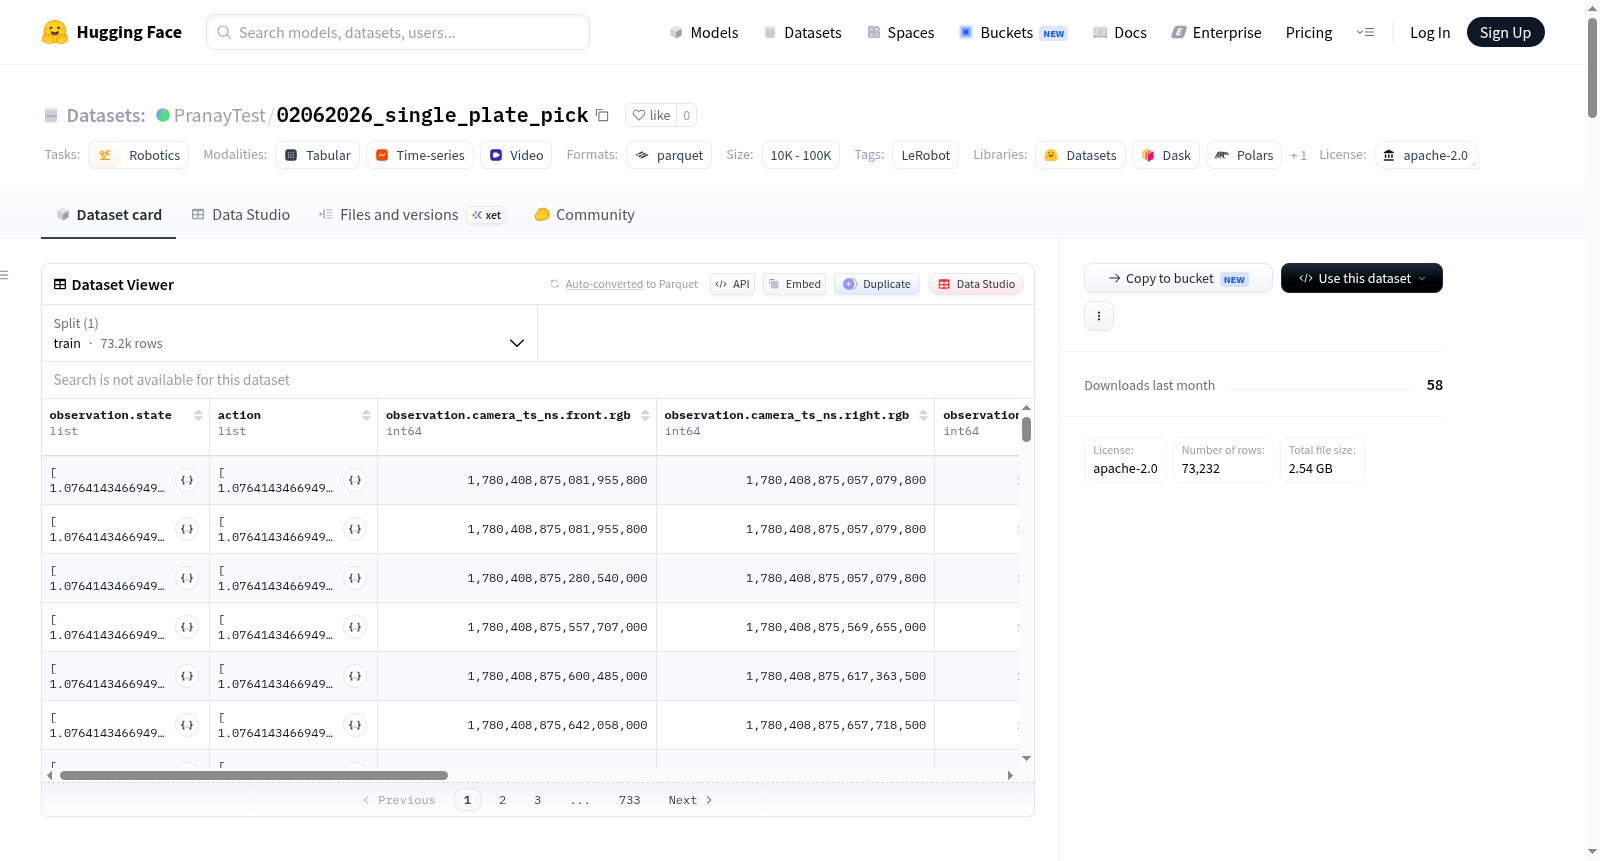
该数据集是使用LeRobot平台创建的机器人操作数据集,记录了AgileX Piper双手机器人执行单一任务(总任务数为1)时的多模态交互数据。数据规模包含113个episodes,共计73,232帧数据(以20fps采样),以分块形式存储(块大小1000),总数据文件约100MB,视频文件约200MB。数据集包含训练集分割(所有113个episodes)。数据内容包括:1) 观察状态:14维浮点向量,表示机器人左右臂各6个关节角度以及左右夹爪的状态;2) 动作:14维浮点向量,对应左右臂各关节和夹爪的控制指令;3) 多视角视觉观测:来自三个相机(front, right, left)的RGB视频流,每帧分辨率为640x480,3通道,采用h264编码,帧率20fps;4) 时间信息:每个视觉观测对应的时间戳(纳秒级);5) 遥测数据:左右臂各6个关节的角度(度);6) 索引信息:时间戳、帧索引、episode索引、全局索引和任务索引。该数据集适用于机器人学习任务,特别是涉及双手机器人操作、模仿学习、强化学习或从多模态感知数据中学习策略的研究。
This robotic manipulation dataset was created using the LeRobot platform, which records multimodal interaction data from the AgileX Piper dual-arm robot executing a single task (total 1 task). The dataset includes 113 episodes, totaling 73,232 frames sampled at 20 fps, and is stored in chunks with a chunk size of 1000. The total size of non-video data files is approximately 100 MB, while the video files amount to around 200 MB. The dataset provides a training split covering all 113 episodes. The dataset includes the following components: 1) Observation state: A 14-dimensional floating-point vector representing the joint angles of the robot's left and right arms (6 joints per arm) and the states of the left and right grippers. 2) Action: A 14-dimensional floating-point vector corresponding to the control commands for each joint and gripper of the left and right arms. 3) Multi-view visual observations: RGB video streams from three cameras (front, right, left). Each frame has a resolution of 640×480 with 3 channels, encoded with the h264 codec, and captured at 20 fps. 4) Timing information: Nanosecond-precision timestamps corresponding to each visual observation. 5) Telemetry data: Joint angles (in degrees) of the 6 joints for each of the left and right arms. 6) Index information: Timestamps, frame indices, episode indices, global indices, and task indices. This dataset is suitable for robotic learning tasks, particularly research involving dual-arm robot manipulation, imitation learning, reinforcement learning, or policy learning from multimodal perceptual data.
数据集概述
- 数据集名称:
PranayTest/02062026_single_plate_pick - 许可证: Apache-2.0
- 任务类别: 机器人(Robotics)
- 标签: LeRobot
- 创建工具: 使用 LeRobot 创建
数据集结构
- 代码库版本: v3.0
- 机器人类型: Agilex Piper 双臂机器人(
agilex_piper_bimanual) - 总片段数: 113
- 总帧数: 73,232
- 总任务数: 1
- 数据块大小: 1000
- 数据文件大小: 100 MB
- 视频文件大小: 200 MB
- 帧率: 20 FPS
- 数据集分割: 训练集(第0到112片段)
特征字段
| 字段名称 | 数据类型 | 形状 | 说明 |
|---|---|---|---|
observation.state |
float32 | (14,) | 机器人关节状态(右臂6关节 + 左臂6关节 + 右夹爪 + 左夹爪) |
action |
float32 | (14,) | 动作指令(与状态维度一致) |
observation.images.front |
video | (640, 480, 3) | 前置摄像头视频,H.264编码,20 FPS |
observation.camera_ts_ns.front.rgb |
int64 | (1,) | 前置摄像头时间戳(纳秒) |
observation.images.right |
video | (640, 480, 3) | 右侧摄像头视频 |
observation.camera_ts_ns.right.rgb |
int64 | (1,) | 右侧摄像头时间戳 |
observation.images.left |
video | (640, 480, 3) | 左侧摄像头视频 |
observation.camera_ts_ns.left.rgb |
int64 | (1,) | 左侧摄像头时间戳 |
observation.telemetry.right.joint_angles_deg |
float32 | (6,) | 右臂关节角度(度) |
observation.telemetry.left.joint_angles_deg |
float32 | (6,) | 左臂关节角度(度) |
timestamp |
float32 | (1,) | 时间戳 |
frame_index |
int64 | (1,) | 帧索引 |
episode_index |
int64 | (1,) | 片段索引 |
index |
int64 | (1,) | 全局索引 |
task_index |
int64 | (1,) | 任务索引 |
数据存储格式
- 数据路径:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频路径:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
可视化与引用
- 可视化链接: 可视化数据集
- 引用: 暂无(需更多信息)