maysmile/icra_0522_can_sub
收藏资源简介:
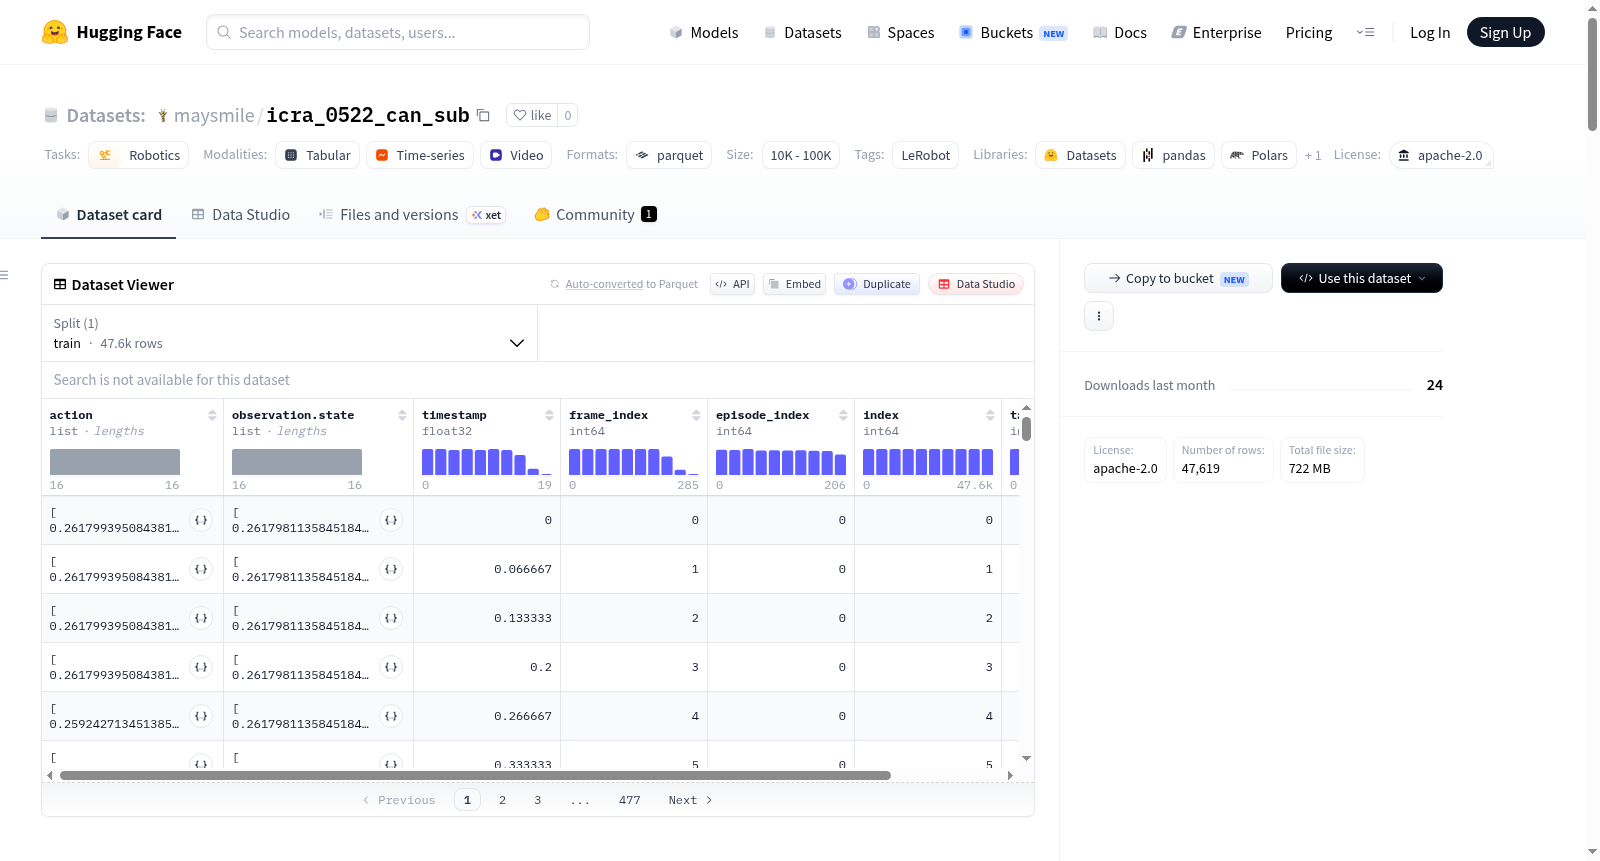
该数据集是使用LeRobot创建的机器人学数据集,专注于双机械臂控制任务。数据集包含动作数据(右臂7个关节、左臂7个关节、右夹爪和左夹爪共16个维度)、状态观测数据(与动作相同的16维关节状态)、以及来自三个视角(前、右、左)的视频观测数据(前视角分辨率为480x640,右和左视角为640x480,均为RGB视频)。数据以parquet格式组织,总共有207个episodes,47619帧,帧率为15fps。数据集还包含时间戳、帧索引、episode索引、任务索引等元数据,适用于机器人模仿学习或强化学习研究。
This dataset is a robotics dataset developed using LeRobot, focusing on dual-arm robotic control tasks. It includes action data with 16 total dimensions: 7 joints for the right arm, 7 joints for the left arm, plus the right and left grippers. It also contains state observation data, which consists of 16-dimensional joint states consistent with the action dimensions. Additionally, the dataset provides video observation data from three perspectives: front, right, and left. The front-view camera has a resolution of 480×640, while the right and left-view cameras have a resolution of 640×480, with all videos being in RGB format. The data is organized in Parquet format, with a total of 207 episodes, 47619 frames, and a frame rate of 15 fps. Metadata such as timestamps, frame indices, episode indices, and task indices is also included in the dataset. This dataset is suitable for research in robotic imitation learning or reinforcement learning.