jellyho/aloha_handover_box_joint_pos_rl
收藏资源简介:
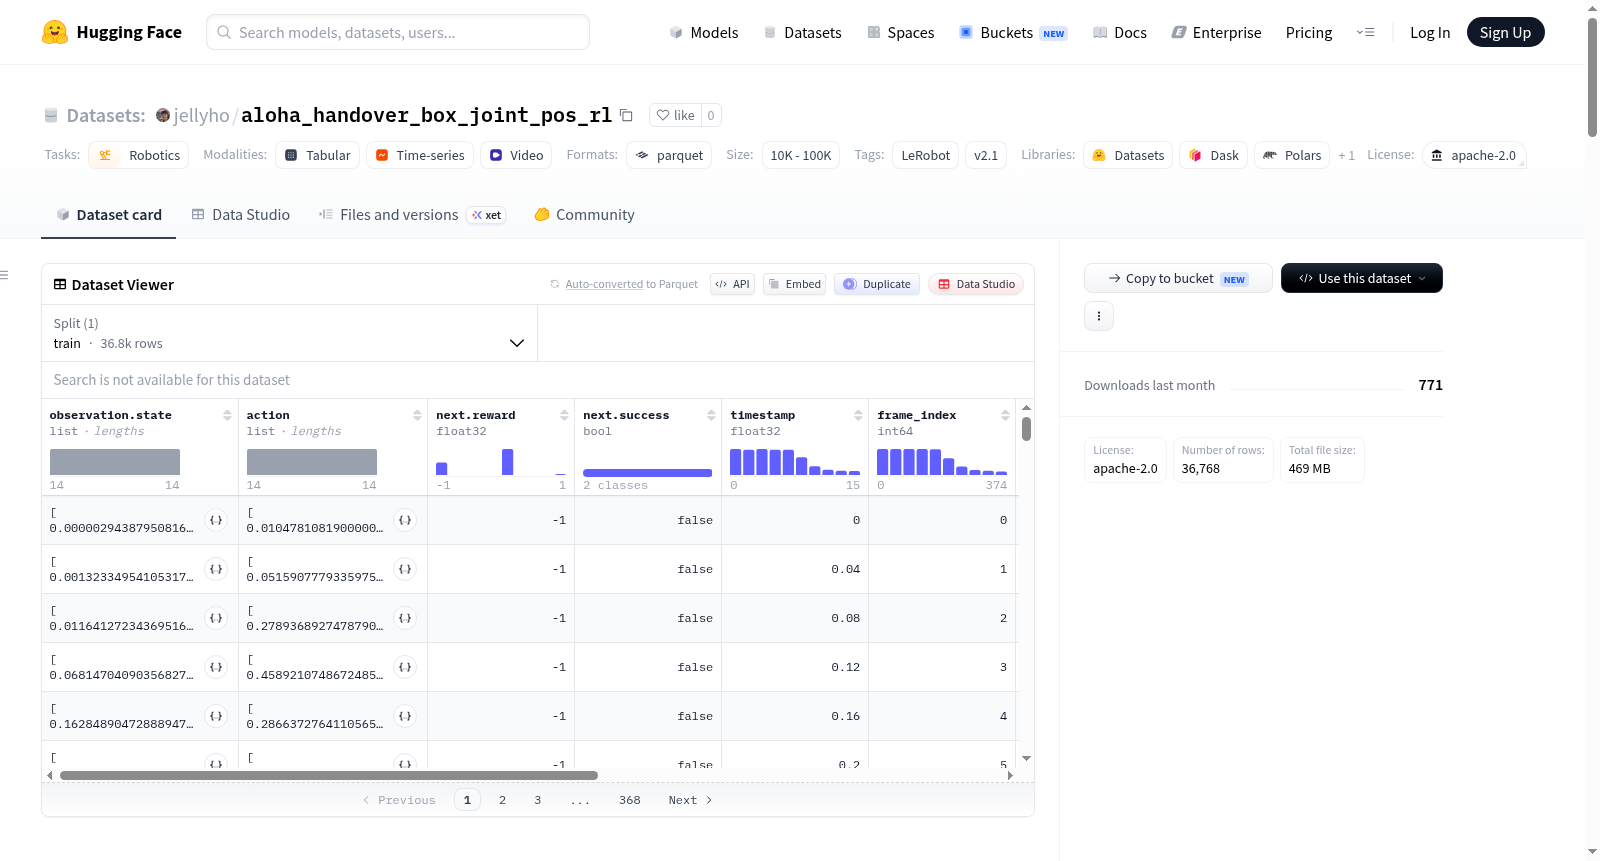
该数据集是使用LeRobot创建的机器人学数据集,包含50个episodes、11829帧和150个视频。数据集结构包括观察状态(14个浮点数,代表左右机械臂的6个关节和夹爪位置)、动作(相同维度的浮点数)、来自三个摄像头的图像(背部摄像头分辨率为480x640,左右腕部摄像头分辨率为240x320,均为RGB视频)、奖励(浮点数)、成功标志(布尔值)、时间戳、帧索引、episode索引等特征。数据以parquet格式存储,视频以mp4格式(AV1编解码器)存储,帧率为25fps。数据集仅包含训练集,使用Apache 2.0许可证。
This is a robotics dataset built using LeRobot. It comprises 50 episodes, 11,829 frames, and 150 videos. The dataset structure includes observation states (14 floating-point values corresponding to the 6 joints and gripper positions of both the left and right robotic arms), actions (floating-point values with identical dimensionality), images from three cameras (the rear camera has a resolution of 480×640, while the left and right wrist cameras have a resolution of 240×320; all videos are in RGB format), rewards (floating-point numbers), success flags (boolean values), timestamps, frame indices, episode indices, and other features. The tabular data is stored in Parquet format, while the videos are saved in MP4 format with the AV1 codec at a frame rate of 25 fps. The dataset only includes a training split and is released under the Apache 2.0 license.