jellyho/aloha_handover_box_joint_pos_bc_orig
收藏资源简介:
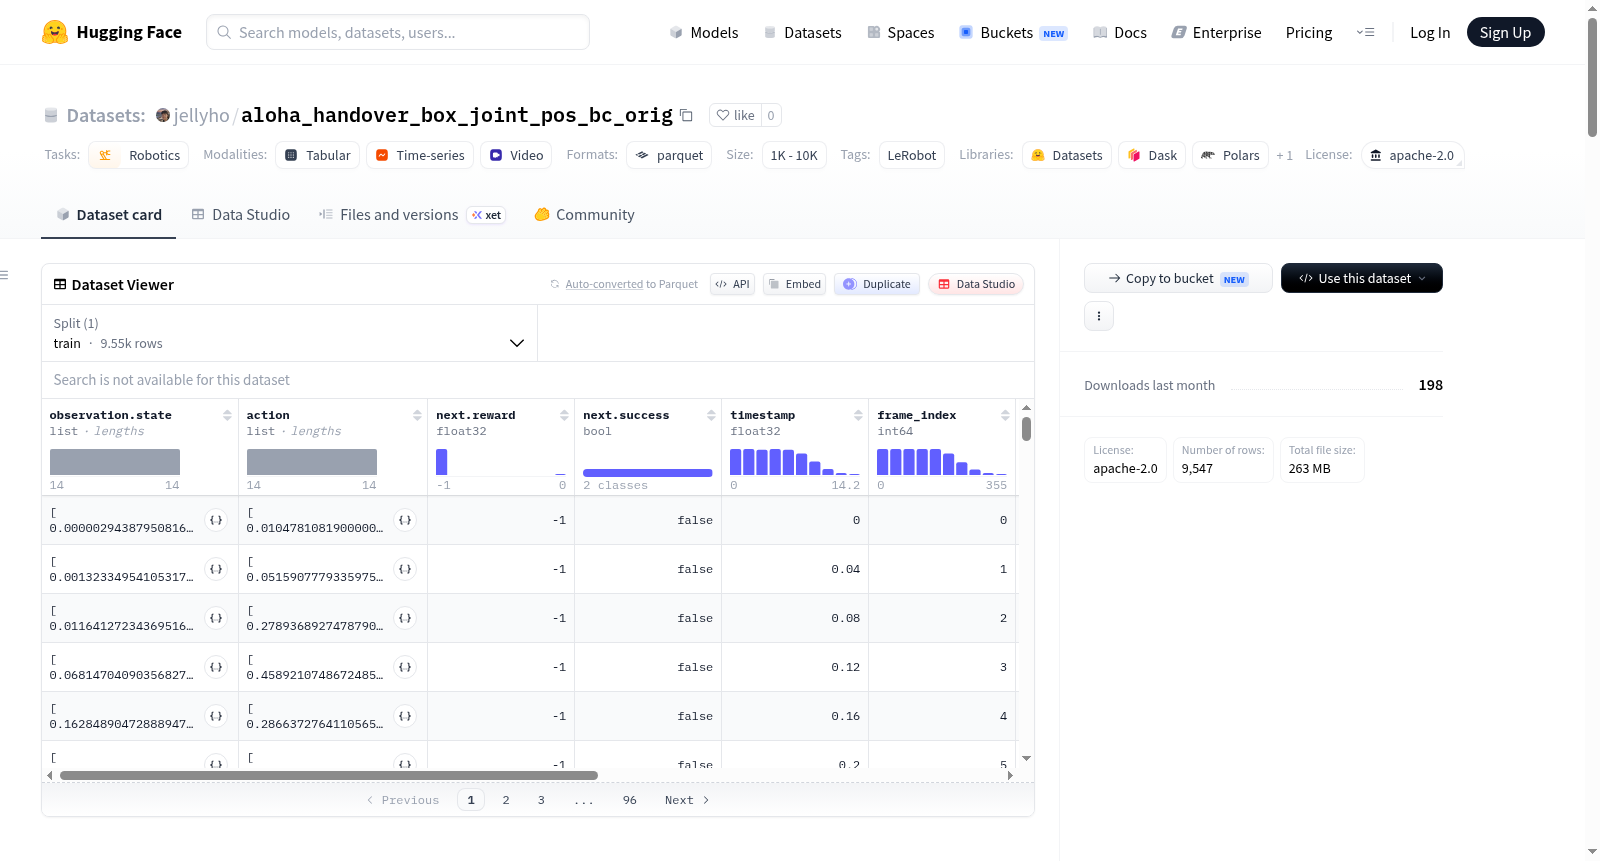
该数据集是一个机器人控制数据集,使用LeRobot工具创建。它包含40个训练集,总计9547帧数据,帧率为25fps,并包含120个视频。数据集中每个样本包含机器人状态观测(如左右机械臂的6个关节角度和夹爪状态,共14维浮点数)、动作(同样为14维浮点数,对应关节和夹爪控制)、来自不同视角的图像观测(包括背部摄像头(分辨率480x640)和左右手腕摄像头(分辨率240x320)的视频数据),以及奖励、成功标志、时间戳、帧索引、集索引等元数据。数据集主要用于机器人模仿学习或强化学习任务,支持训练模型以控制双机械臂系统执行特定操作。
This robotic control dataset was constructed using the LeRobot toolkit. It consists of 40 training splits, with a total of 9547 frames at a frame rate of 25 fps, and includes 120 videos. Each sample in the dataset contains robotic state observations (e.g., 6 joint angles and gripper states for both the left and right robotic arms, totaling 14-dimensional floating-point values), actions (also 14-dimensional floating-point values corresponding to joint and gripper control commands), image observations from multiple perspectives (including video data from the rear camera with a resolution of 480x640 and the left/right wrist cameras with a resolution of 240x320), as well as metadata such as rewards, success flags, timestamps, frame indices, and split indices. This dataset is mainly designed for robotic imitation learning or reinforcement learning tasks, enabling the training of models to control dual-arm robotic systems to perform specific operations.