
Benchmark for Autonomous Robot Navigation (BARN)
收藏资源简介:
Benchmark for Autonomous Robot Navigation (BARN)数据集由德克萨斯大学奥斯汀分校计算机科学系创建,包含300个模拟导航环境,用于评估和比较不同自主移动机器人导航系统的性能。该数据集通过细胞自动机方法生成,涵盖多种难度级别的障碍环境。数据集的创建过程中,使用了多种难度量化指标,并通过学习函数逼近器来综合这些指标,以评估特定环境的导航难度。BARN数据集适用于预测新环境的导航难度、比较不同导航系统,并可作为基于规划和学习的导航系统的成本函数和课程。
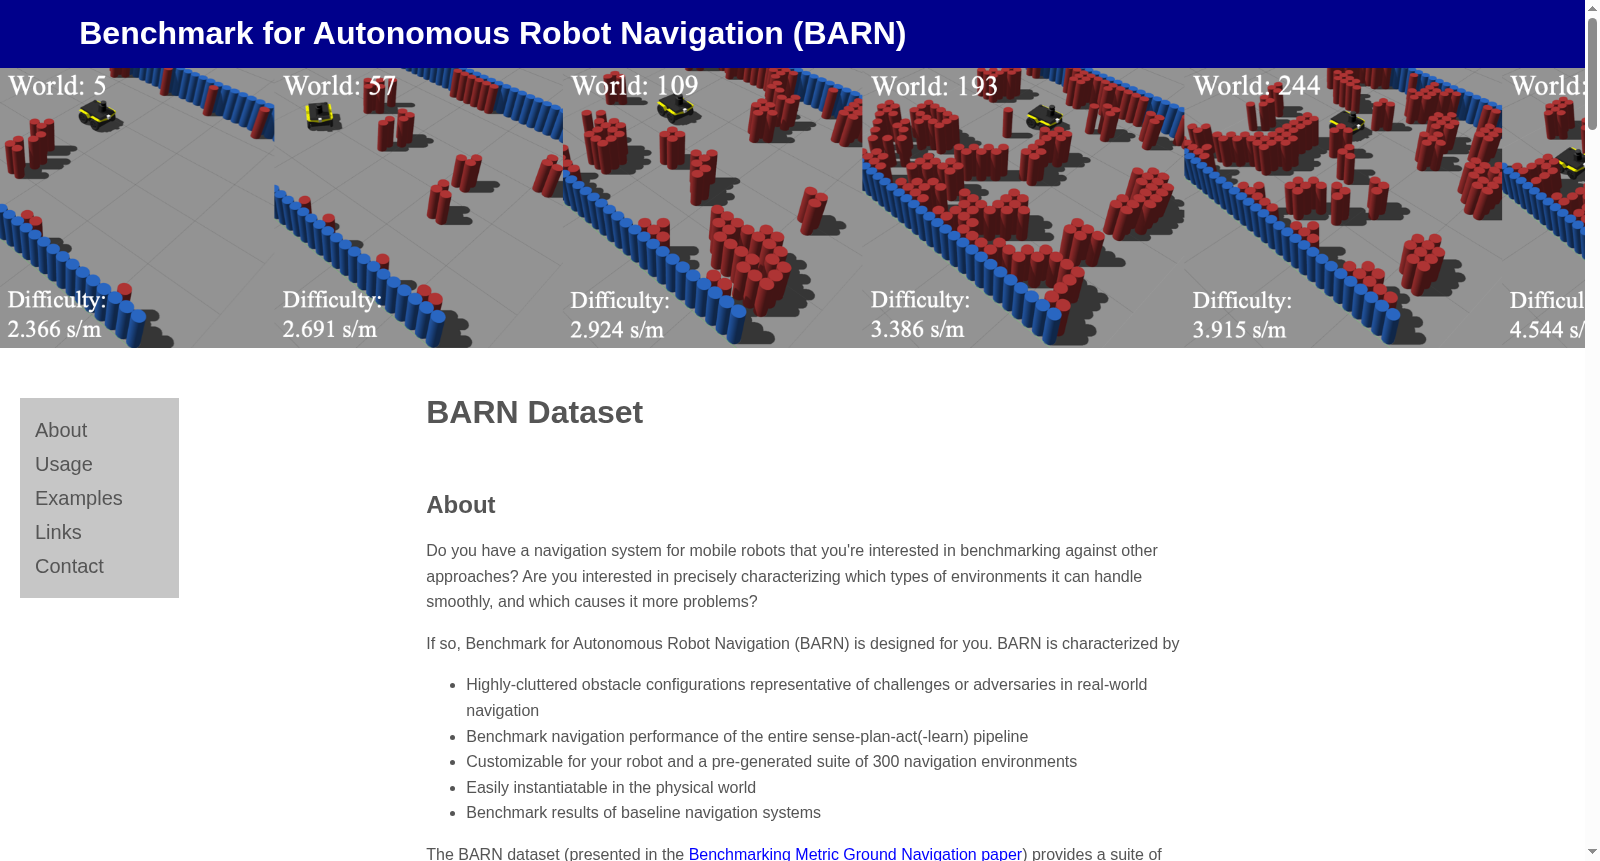
The Benchmark for Autonomous Robot Navigation (BARN) dataset was developed by the Department of Computer Science at The University of Texas at Austin. It comprises 300 simulated navigation environments designed to evaluate and compare the performance of various autonomous mobile robot navigation systems. Generated using cellular automaton methods, this dataset covers obstacle environments with multiple difficulty levels. During the dataset creation process, multiple difficulty quantification metrics were adopted, and a learned function approximator was utilized to synthesize these metrics for assessing the navigation difficulty of specific environments. The BARN dataset is suitable for predicting the navigation difficulty of new environments, comparing different navigation systems, and serving as a cost function and curriculum for planning- and learning-based navigation systems.
- 1Benchmarking Metric Ground Navigation德克萨斯大学奥斯汀分校计算机科学系 · 2020年


