BrandonAL/pursuit_sweep_c5000_p0.3
收藏资源简介:
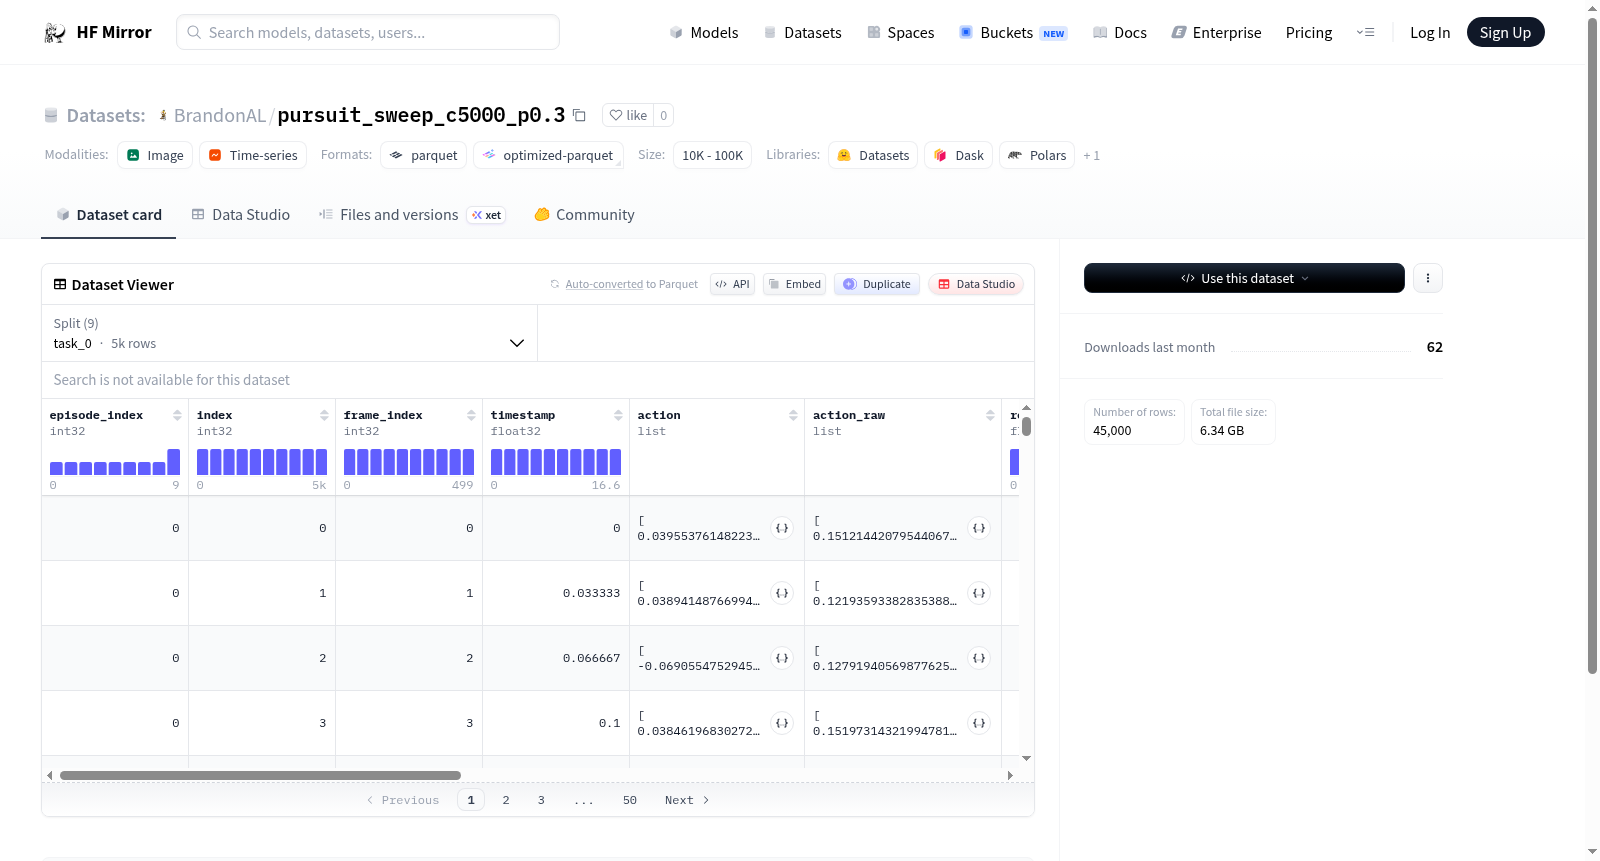
该数据集包含机器人或模拟环境中的时序交互数据,用于强化学习或机器人控制任务。数据特征包括episode索引、索引、帧索引、时间戳、动作(7维浮点数组)、原始动作(7维浮点数组)、奖励、完成标志、成功标志、两个图像观测(image和image2)、机器人状态(34维浮点数组)、pursuit_k(7维浮点数组)和pursuit_sm(7维浮点数组)。数据集分为9个任务(task_0到task_8),每个任务有5000个示例,总数据量约6.3 GB,适用于训练和评估智能体在复杂环境中的行为。
This dataset contains temporal interaction data from a robotic or simulation environment, designed for reinforcement learning or robot control tasks. Features include episode index, index, frame index, timestamp, action (7-dimensional float array), raw action (7-dimensional float array), reward, done flag, success flag, two image observations (image and image2), robot state (34-dimensional float array), pursuit_k (7-dimensional float array), and pursuit_sm (7-dimensional float array). The dataset is divided into 9 tasks (task_0 to task_8), each with 5000 examples, totaling approximately 6.3 GB, suitable for training and evaluating agents in complex environments.