
360DVO dataset
收藏资源简介:
360DVO数据集是由香港科技大学团队构建的首个面向单目360度相机的真实世界视觉里程计基准数据集,包含20个不同场景的高动态范围视频序列,涵盖野外、室内、城市及航拍视角等多种复杂环境。该数据集针对现有合成数据缺乏真实挑战的问题,专门采集了包含剧烈运动(如运动模糊、频繁旋转)和光照变化的实景数据,旨在为深度学习驱动的全景视觉里程计算法提供更贴近实际应用的评估平台。数据通过便携式360度相机采集,并以等距柱状投影格式存储,为相机位姿估计和三维重建任务提供了高质量的基准真值。
The 360DVO dataset is the first real-world visual odometry benchmark dataset for monocular 360° cameras, constructed by the team from The Hong Kong University of Science and Technology. It contains 20 high dynamic range (HDR) video sequences across diverse scenarios, covering complex environments such as outdoor fields, indoor spaces, urban areas and aerial viewpoints. Addressing the problem that existing synthetic datasets lack real-world challenges, this dataset specifically collects real-world data featuring intense motions (e.g., motion blur and frequent rotations) and illumination variations. It aims to provide a more practical evaluation platform for deep learning-driven panoramic visual odometry algorithms. The data is collected via a portable 360° camera and stored in the equirectangular projection format, providing high-quality ground truth for camera pose estimation and 3D reconstruction tasks.
360DVO: Deep Visual Odometry for Monocular 360-Degree Camera
数据集基本信息
- 数据集名称:360DVO
- 提出者/作者:Xiaopeng Guo, Yinzhe Xu, Huajian Huang, Sai-Kit Yeung
- 机构:The Hong Kong University of Science and Technology
- 发表会议/期刊:IEEE Robotics and Automation Letters (RA-L)
- 发表年份:2026
- 论文状态:已发布在arXiv
- 论文arXiv编号:2601.02309
- 论文arXiv地址:https://arxiv.org/abs/2601.02309
- 代码与数据:提供论文、补充材料、代码和数据集链接
数据集概述
- 核心贡献:提出了第一个基于深度学习的全向视觉里程计(OVO)框架,并贡献了一个新的真实世界OVO基准数据集。
- 方法名称:360DVO
- 关键模块:
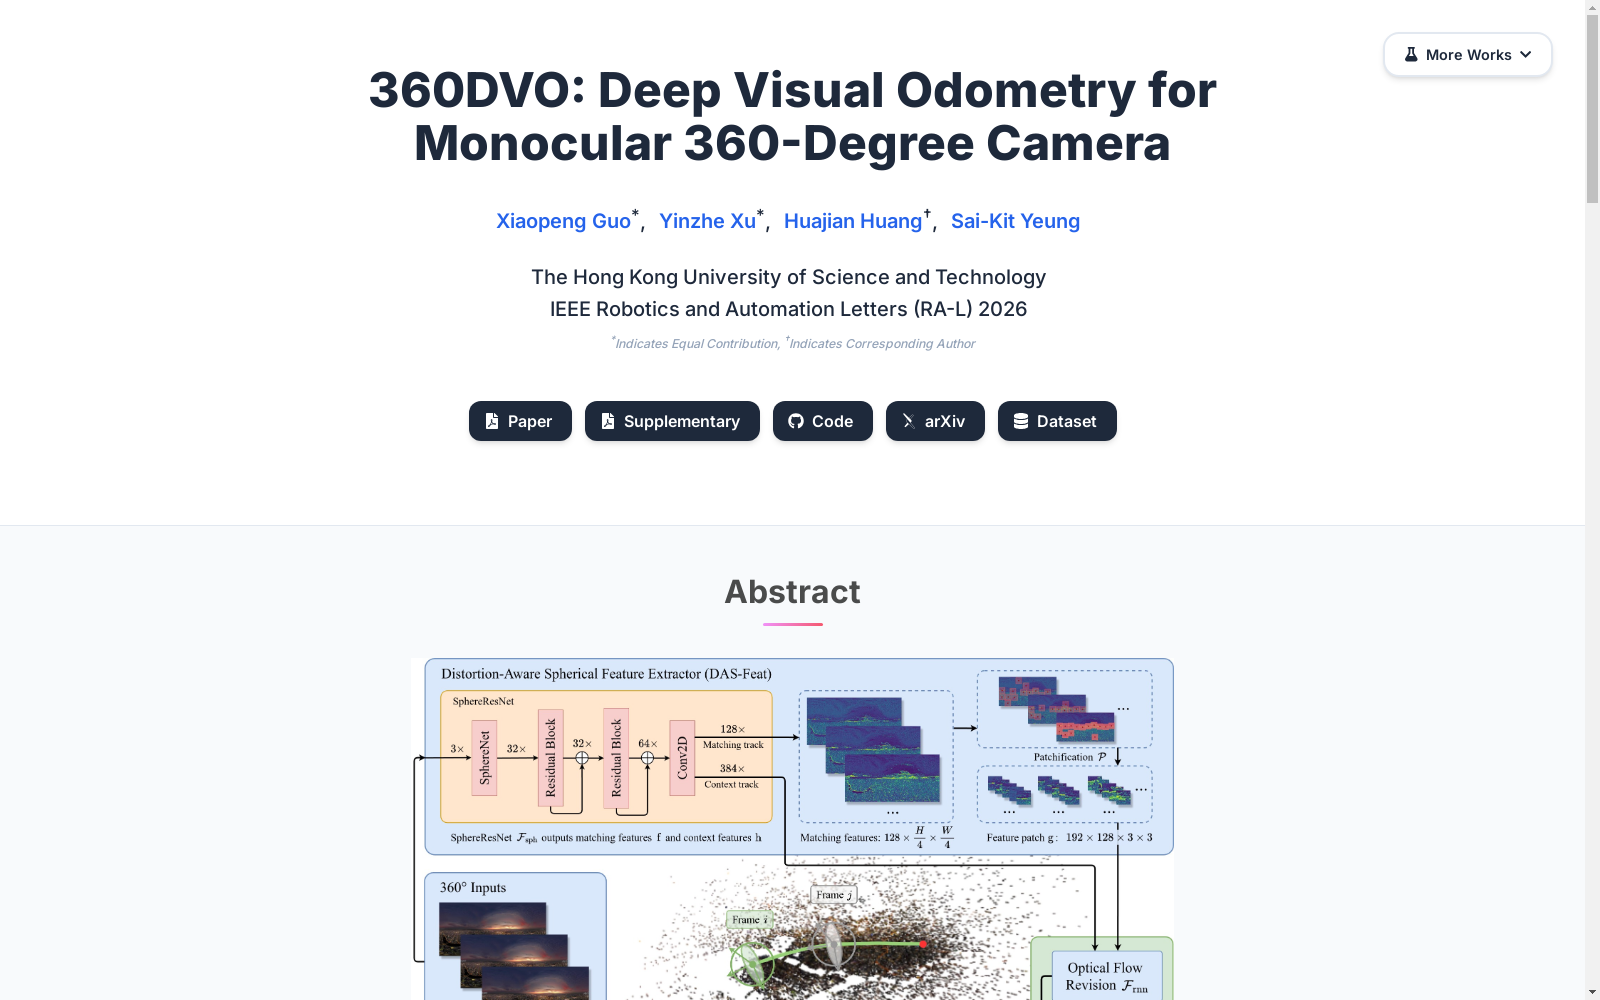
- 失真感知球面特征提取器(DAS-Feat):自适应地从360度图像中学习抗失真特征。
- 全向可微光束法平差模块(ODBA):利用稀疏特征块建立约束以进行有效的姿态估计。
- 输入数据:连续的360度RGB帧序列。
- 主要特点:通过SphereResNet提取抗失真特征,允许裁剪块而不变形;通过循环网络估计光流;在ODBA模块中联合优化当前帧的姿态和深度。
实验与评估
- 评估基准:
- 新贡献的真实世界OVO基准数据集(360DVO数据集)。
- 公开合成数据集:TartanAir V2 和 360VO。
- 对比基线:包括360VO和OpenVSLAM等最先进基线。
- 性能表现:
- 在鲁棒性上提升50%。
- 在准确性上提升37.5%。
- 在360DVO数据集上运行稳定,变异最低。
- 评估指标:轨迹精度(ATE/RPE(t)/RPE(r))和跟踪成功率(%)。
- 变体:360DVO (fast) 使用较低分辨率的图像作为输入,同时保持更稀疏的采样块。
- 1360DVO: Deep Visual Odometry for Monocular 360-Degree Camera香港科技大学·综合系统与设计部; 香港科技大学·计算机科学与工程系; 香港科技大学·海洋科学系 · 2026年


