record-test
收藏资源简介:
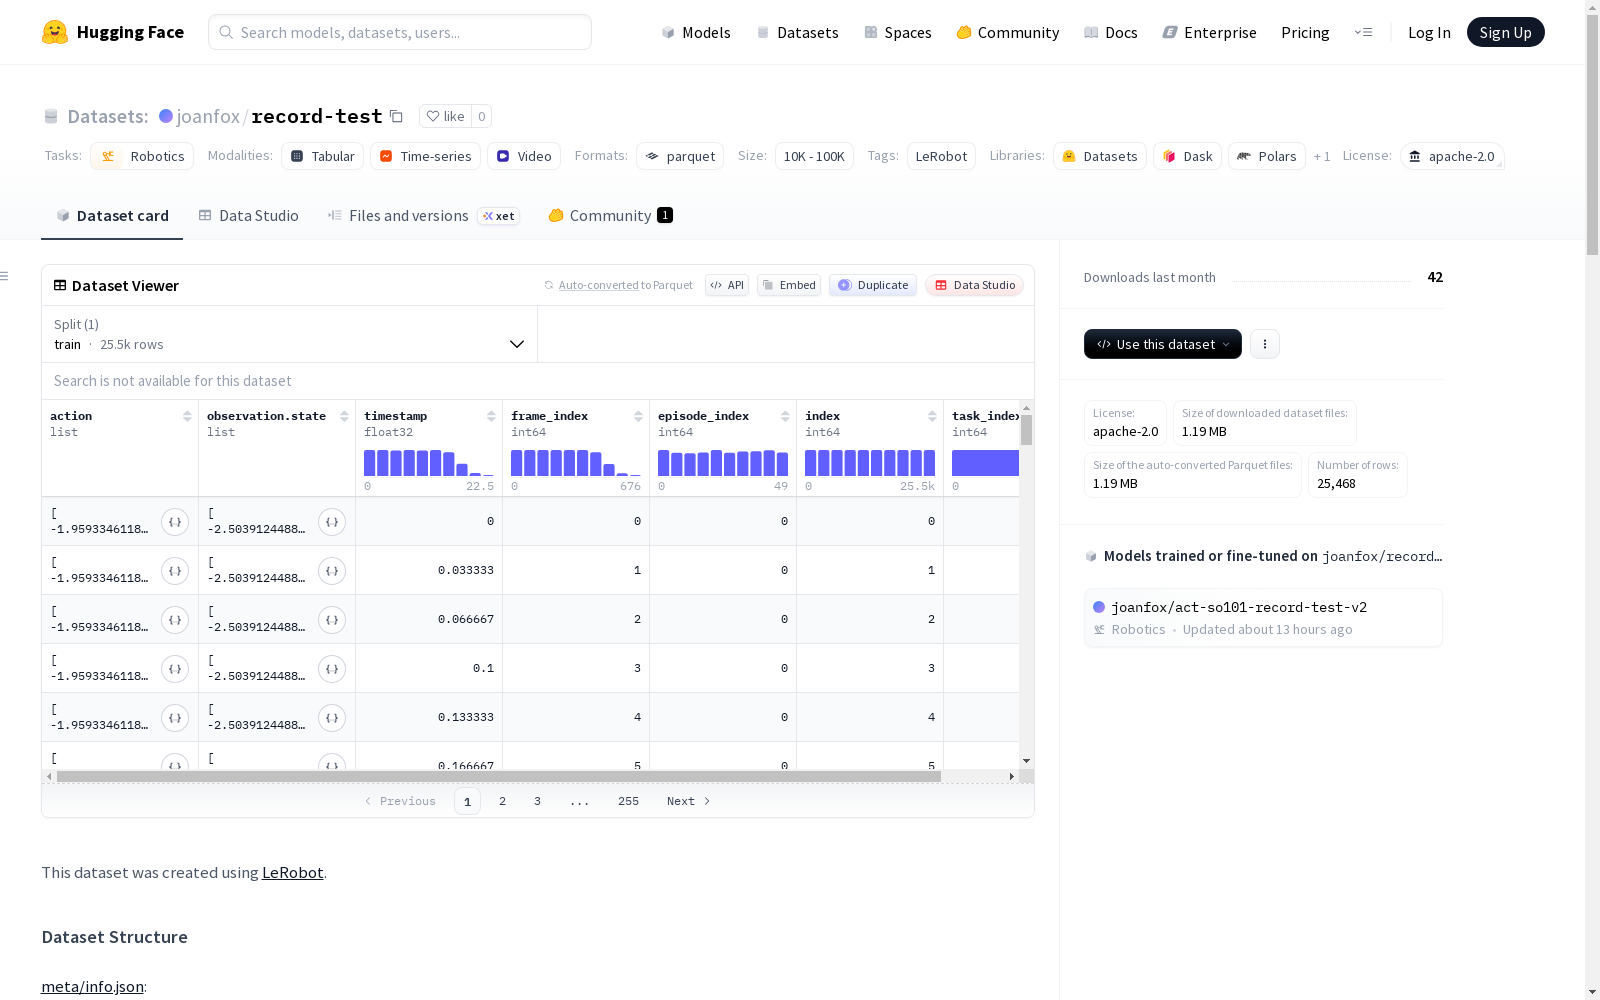
该数据集是使用LeRobot创建的,主要用于机器人技术领域。数据集采用apache-2.0许可证,包含50个episodes,总计25468帧,涉及1个任务。数据以parquet文件格式存储,总数据文件大小为100MB,视频文件大小为200MB,帧率为30fps。数据集结构包括训练集(0:50)。数据文件路径为data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet,视频文件路径为videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4。数据集包含多个特征,如动作(action)、观察状态(observation.state)、前视图像(observation.images.front)、时间戳(timestamp)、帧索引(frame_index)、episode索引(episode_index)、索引(index)和任务索引(task_index)。每个特征都有详细的数据类型、形状和名称描述。前视图像特征还包括视频高度、宽度、通道数、编解码器、像素格式、是否为深度图、帧率和是否有音频等信息。
This dataset was developed using LeRobot and is primarily targeted for robotics research and applications. It is licensed under Apache-2.0, contains 50 episodes totaling 25,468 frames, and focuses on a single task. The data is stored in Parquet format, with the total size of the data files being 100 MB, while the total size of the video files is 200 MB, and the frame rate is 30 fps. The dataset structure includes the training split with episodes ranging from 0 to 50. The data file paths are data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet, and the video file paths are videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4. The dataset includes multiple features such as action, observation.state, observation.images.front, timestamp, frame_index, episode_index, index, and task_index. Each feature has detailed descriptions of its data type, shape, and name. The front-view image feature additionally includes information such as video height, width, channel count, codec, pixel format, whether it is a depth map, frame rate, and whether audio is included.
数据集概述
基本信息
- 数据集名称: record-test
- 创建工具: LeRobot
- 许可证: Apache 2.0
- 任务类别: 机器人学
- 标签: LeRobot
数据集规模
- 总情节数: 50
- 总帧数: 25468
- 总任务数: 1
- 数据文件总大小: 100 MB
- 视频文件总大小: 200 MB
- 帧率: 30 FPS
数据组织与结构
- 配置名称: default
- 数据文件模式:
data/*/*.parquet - 数据路径模式:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频路径模式:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4 - 分块大小: 1000
- 代码库版本: v3.0
- 机器人类型: so_follower
- 数据划分: 训练集 (0:50)
数据特征
动作
- 数据类型: float32
- 形状: [6]
- 特征名: shoulder_pan.pos, shoulder_lift.pos, elbow_flex.pos, wrist_flex.pos, wrist_roll.pos, gripper.pos
观测状态
- 数据类型: float32
- 形状: [6]
- 特征名: shoulder_pan.pos, shoulder_lift.pos, elbow_flex.pos, wrist_flex.pos, wrist_roll.pos, gripper.pos
观测图像(前视)
- 数据类型: video
- 形状: [480, 640, 3]
- 维度名: height, width, channels
- 视频信息:
- 高度: 480
- 宽度: 640
- 编解码器: av1
- 像素格式: yuv420p
- 是否为深度图: false
- 帧率: 30
- 通道数: 3
- 是否包含音频: false
元数据
- 时间戳: 数据类型 float32,形状 [1]
- 帧索引: 数据类型 int64,形状 [1]
- 情节索引: 数据类型 int64,形状 [1]
- 索引: 数据类型 int64,形状 [1]
- 任务索引: 数据类型 int64,形状 [1]
引用信息
- 主页: 信息缺失
- 论文: 信息缺失
- BibTeX 引用: 信息缺失