fold_pink_cloth_in_half
收藏资源简介:
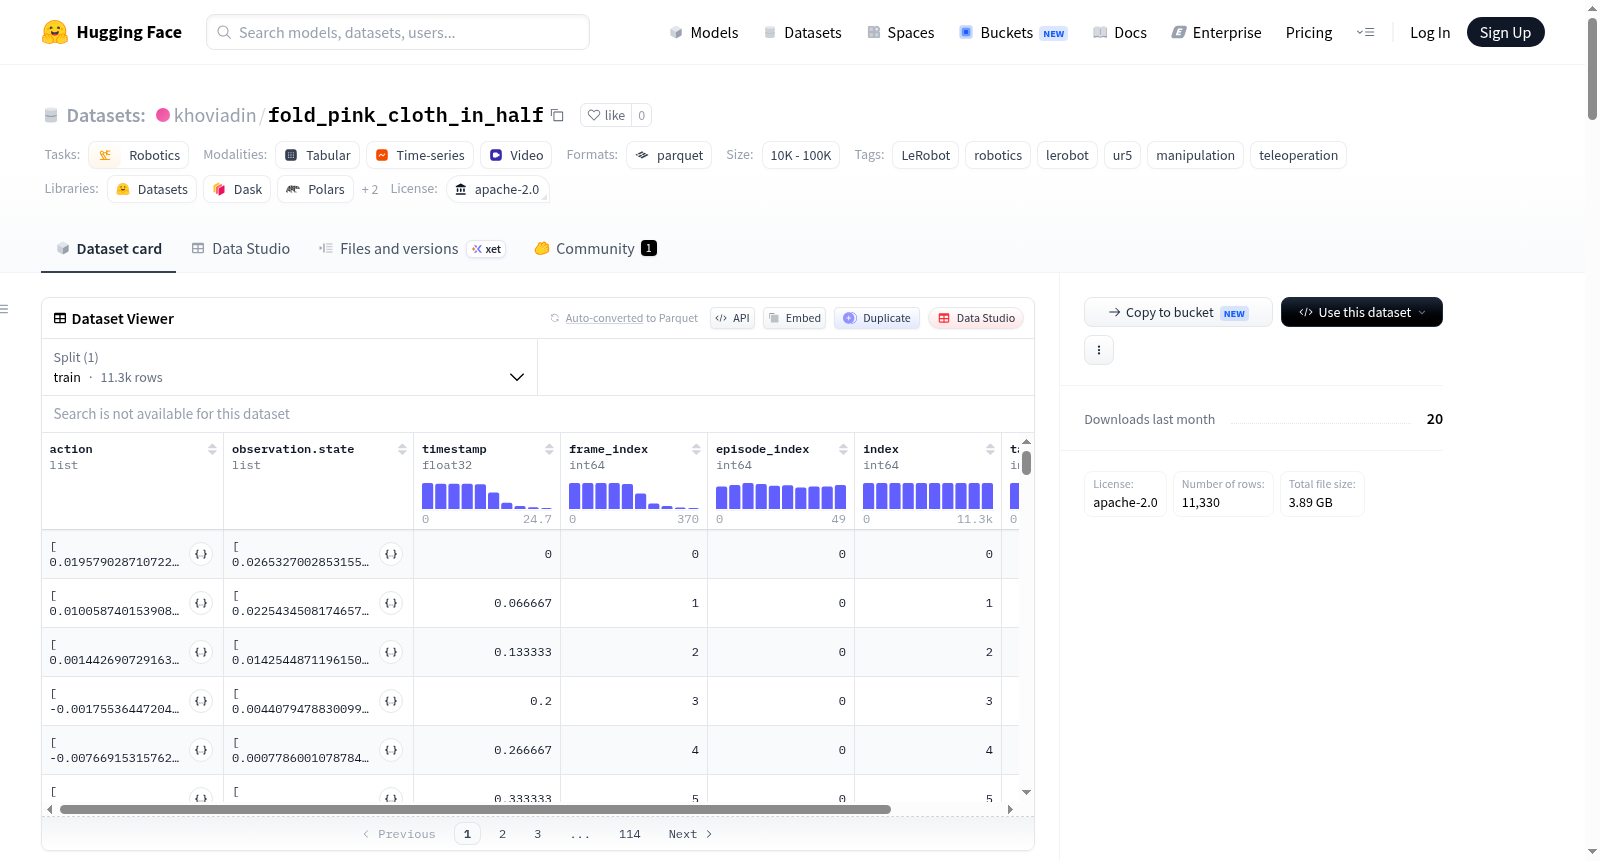
该数据集是基于 LeRobot 框架创建的机器人操作数据集,用于训练机器人折叠粉色布的任务。数据集包含 50 个演示片段,共 11330 帧,帧率为 15 FPS。机器人类型为 mantis_follower(与 UR5 相关)。数据特征包括:7 维动作向量(对应机械臂关节位置和夹爪位置)、7 维观察状态向量(与动作维度相同)、左右两个 RGB 摄像头图像(720×1280 像素,编码为 AV1 视频)、左右两个深度摄像头图像(720×1280 像素,单通道,编码为 HEVC 无损视频),以及时间戳、帧索引、片段索引、任务索引等元数据。所有数据存储为 Parquet 格式,视频文件为 MP4 格式。该数据集适用于模仿学习、机器人操作策略训练等任务,尤其适用于基于视觉反馈的机械臂操控场景。许可证为 Apache-2.0。
This dataset is a robot manipulation dataset created based on the LeRobot framework, designed for training robots to fold a pink cloth. It contains 50 demonstration episodes with a total of 11,330 frames at 15 FPS. The robot type is mantis_follower (related to UR5). Data features include: 7-dimensional action vector (corresponding to joint positions and gripper positions), 7-dimensional observation state vector (same dimension as actions), left and right RGB camera images (720×1280 pixels, encoded as AV1 video), left and right depth camera images (720×1280 pixels, single channel, encoded as HEVC lossless video), and metadata such as timestamps, frame indices, episode indices, and task indices. All data is stored in Parquet format, with video files in MP4 format. This dataset is suitable for tasks such as imitation learning and robot manipulation policy training, especially for visual feedback-based robotic arm control scenarios. The license is Apache-2.0.
数据集概述
fold_pink_cloth_in_half 是一个用于机器人操作任务的数据集,专注于将粉色布料对折的操作。该数据集通过 LeRobot 框架创建,适用于机器人的模仿学习或操作策略训练。
- 任务类型: 机器人操作 (Robotics)
- 许可证: Apache-2.0
- 数据集创建工具: LeRobot
- 机器人类型: UR5 (配备 Mantis 夹爪),遥操作采集
数据集结构
- 总回合数 (Episodes): 50
- 总帧数 (Frames): 11,330
- 任务数量 (Tasks): 1 (折叠粉色布料)
- 数据格式: Parquet 文件,包含动作和状态数据;视频文件存储图像观测
- 采样频率 (FPS): 15 Hz
- 数据分割: 仅训练集 (50个回合全部用于训练)
数据特征
数据集中包含以下特征类别:
动作与状态 (Action & State)
- action: 7维浮点数组,包含6个关节位置和1个夹爪位置(
left_shoulder_pan_joint.pos,left_shoulder_lift_joint.pos,left_elbow_joint.pos,left_wrist_1_joint.pos,left_wrist_2_joint.pos,left_wrist_3_joint.pos,gripper.pos) - observation.state: 7维浮点数组,与动作特征相同,代表机器人当前状态
图像观测 (Image Observations)
- observation.images.left: 左侧摄像头RGB视频,分辨率 720x1280,3通道,AV1编码,15 FPS
- observation.images.right: 右侧摄像头RGB视频,分辨率 720x1280,3通道,AV1编码,15 FPS
- observation.images.left_depth: 左侧深度图视频,分辨率 720x1280,单通道,HEVC无损编码,单位为毫米 (mm)
- observation.images.right_depth: 右侧深度图视频,分辨率 720x1280,单通道,HEVC无损编码,单位为毫米 (mm)
元数据
- timestamp: 浮点时间戳
- frame_index: 帧索引 (整数)
- episode_index: 回合索引 (整数)
- index: 全局索引 (整数)
- task_index: 任务索引 (整数)
数据存储
- 数据文件大小: 约 100 MB (Parquet 文件)
- 视频文件大小: 约 200 MB (MP4 文件)
- 数据路径:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频路径:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
其他信息
- 数据集可视化: 可通过 LeRobot 可视化工具在 Hugging Face Spaces 上查看:https://huggingface.co/spaces/lerobot/visualize_dataset?path=khoviadin/fold_pink_cloth_in_half
- 引用信息: 当前数据集描述中未提供 BibTeX 引用信息。