Metric-AI/so_101_chocolate_50ep_v4_20260619_155110
收藏资源简介:
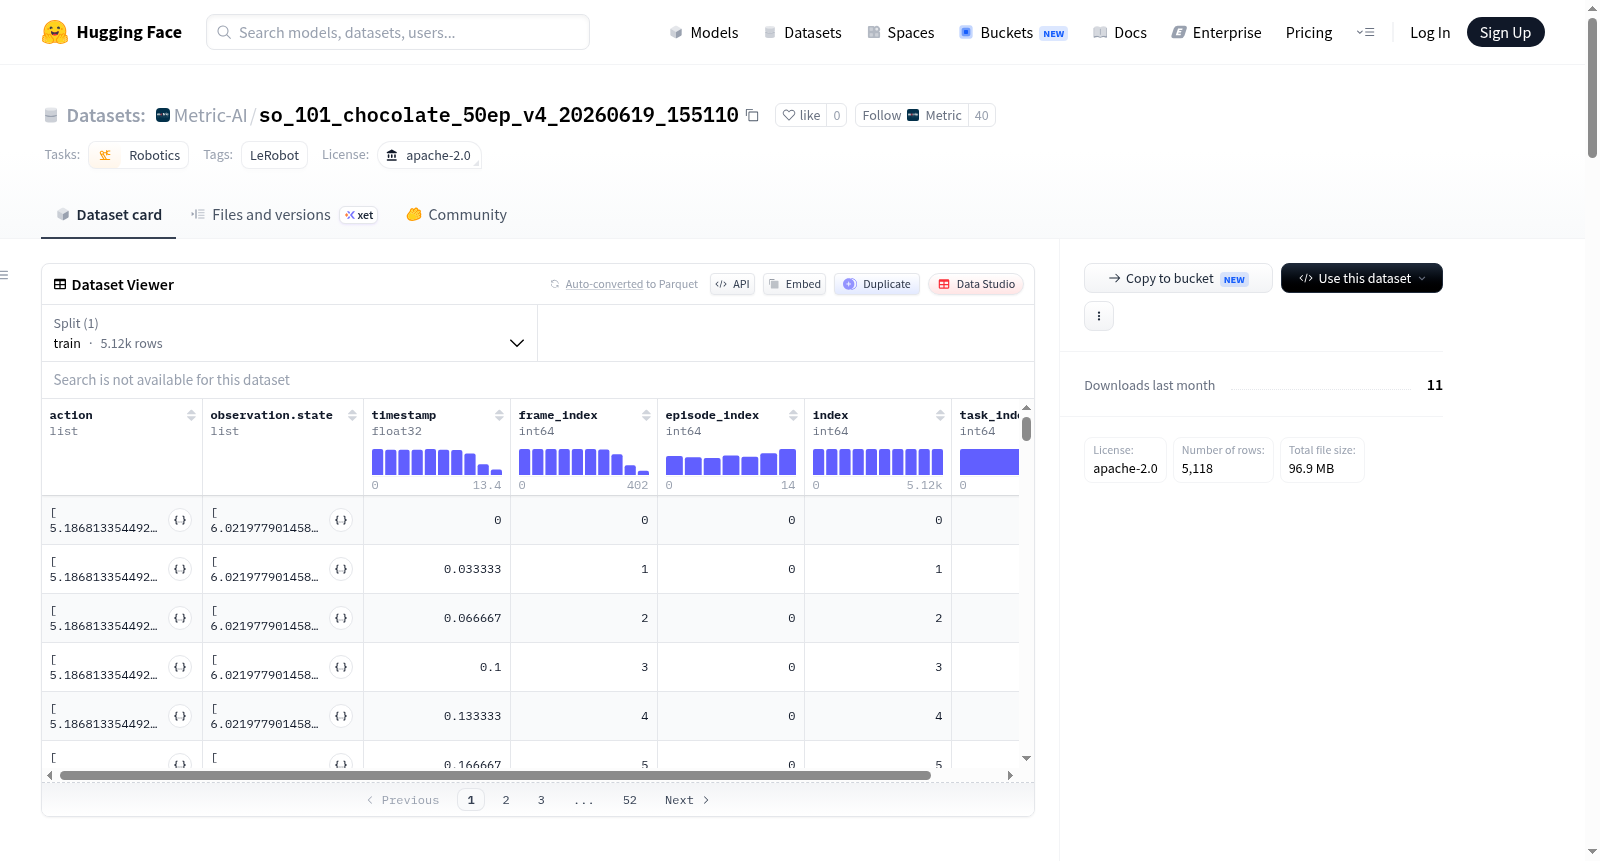
该数据集使用LeRobot创建,专注于机器人学领域,具体针对so_follower机器人类型。数据集包含15个episodes,总计5118帧数据,涉及一个任务。数据特征包括6维浮点动作(如肩部平移、肩部提升、肘部弯曲、腕部弯曲、腕部滚动和夹爪位置)和观测状态(同样为6维浮点,对应机器人关节位置)。观测图像包括固定摄像头和手眼摄像头视频,分辨率为480x640,3通道,帧率为30fps,使用AV1编解码器。此外,还包含时间戳、帧索引、episode索引、索引和任务索引等元数据。数据集以Parquet文件格式存储,总数据大小约100MB,视频文件大小约200MB。数据用于训练或评估机器人控制模型,支持分割为训练集(所有episodes)。
This dataset was created using LeRobot and focuses on the robotics domain, specifically for the so_follower robot type. It consists of 15 episodes with a total of 5118 frames, covering one task. Features include 6-dimensional float actions (e.g., shoulder pan position, shoulder lift position, elbow flex position, wrist flex position, wrist roll position, gripper position) and observation states (also 6-dimensional float, corresponding to robot joint positions). Observation images comprise fixed camera and hand-eye camera videos with a resolution of 480x640, 3 channels, 30 fps, using the AV1 codec. Additionally, metadata such as timestamp, frame index, episode index, index, and task index are included. The dataset is stored in Parquet format, with a total data size of approximately 100 MB and video files of about 200 MB. It is intended for training or evaluating robot control models and supports a split for training (all episodes).