RoboLab-BananaInBowl-hard-base-stoch-260802
收藏资源简介:
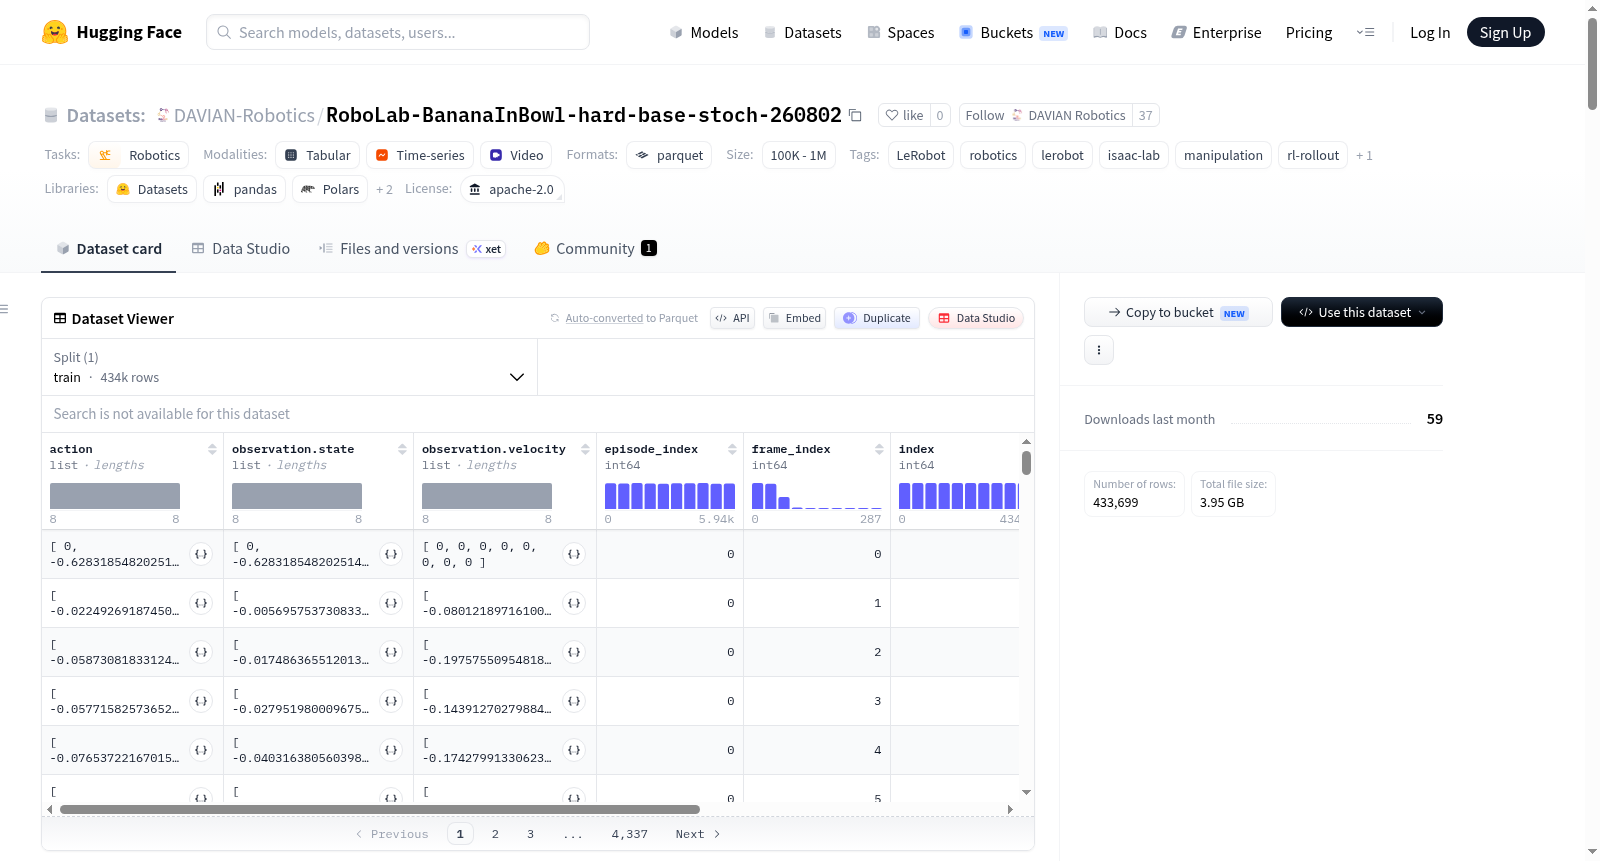
该数据集使用LeRobot工具从RoboLab (Isaac Lab)模拟环境中收集,基于一个在BananaInBowl任务上训练的策略,在hard初始位姿分布下进行强化学习rollout。数据集导出用于pi0.5 delta-action有监督微调。数据仅包含成功episodes,通过随机采样(温度1.0)获取。共有5941个episodes,总计433699帧,帧率15fps。每个样本包含:8维动作向量(绝对关节目标,其中第7个维度为二值夹爪指令,0或1表示打开/关闭)、8维观测状态(关节位置)、8维速度、两个相机视角的图像(over_shoulder_left_camera和wrist_cam,分辨率270x480,RGB视频),以及episode索引、帧索引、时间戳、任务索引、完成标志等字段。记录约定:动作采用绝对关节目标(DROID坐标系,j7偏移-π/4),夹爪为二值控制,状态为teleport原生关节向量,成功判定基于K-hold settle(success_hold_steps=15),episode达到成功即截断。所有视频为恒定帧率,经过归一化处理。数据集完全由模拟生成,无第三方数据,采用Apache-2.0许可证。
This dataset was collected using the LeRobot tool from the RoboLab (Isaac Lab) simulation environment, based on a policy trained on the BananaInBowl task with a hard initial pose distribution during reinforcement learning rollouts. The dataset is exported for supervised fine-tuning of the pi0.5 delta-action model. It contains only successful episodes obtained via random sampling (temperature 1.0). There are a total of 5941 episodes, 433699 frames, at 15fps. Each sample includes: an 8-dimensional action vector (absolute joint targets, with the 7th dimension being a binary gripper command, 0 or 1 for open/close), an 8-dimensional observation state (joint positions), 8-dimensional velocities, images from two camera views (over_shoulder_left_camera and wrist_cam, resolution 270x480, RGB video), as well as episode index, frame index, timestamp, task index, and completion flag. Recording conventions: actions use absolute joint targets (DROID coordinate system, j7 offset -π/4), gripper is binary control, states are teleport native joint vectors, success is determined by K-hold settle (success_hold_steps=15), and episodes are truncated upon success. All videos are constant frame rate and normalized. The dataset is entirely simulated, contains no third-party data, and is licensed under Apache-2.0.
数据集概述:RoboLab-BananaInBowl-hard-base-stoch-260802
基本信息
- 数据集名称: RoboLab-BananaInBowl-hard-base-stoch-260802
- 创建工具: LeRobot (https://github.com/huggingface/lerobot)
- 许可证: Apache-2.0
- 任务类别: 机器人学 (robotics)
- 标签: LeRobot, robotics, lerobot, isaac-lab, manipulation, rl-rollout, pi0.5
数据集内容
- 总集数 (episodes): 5941
- 总帧数 (frames): 433699
- 任务数: 1
- 分割: train (0:5941)
- 帧率 (fps): 15
数据来源与采集方式
- 数据来源于RoboLab(Isaac Lab)环境中
BananaInBowl任务的强化学习策略回放(RL rollouts)。 - 采集策略使用hard初始姿态分布,基于checkpoint
/home/nas_main/minhopark/repos/dg-rl/libs/FlashSAC/models/init-pose-ladder/ipl-bana-hard-s0/BananaInBowl/seed0-0731-195129/step6104(该checkpoint为RFCL代理,采用reverse→forward转换阈值solved_frac_threshold = 0.9,最终评估成功率为0.98,平均成功片段长度为47.7步)。 - 数据通过采样方式从策略分布(temperature 1.0)收集,仅包含成功片段,失败片段在采集时被丢弃。
- 一个确定性(argmax)版本的数据集将单独发布。注意:另有一个分支(
banana-hard-sf50,阈值0.5)重新训练的任务,其数据不可与本数据集互换,在进行对比实验时请勿混用。
初始姿态分布(hard)
- 位置: 任务可测量可行范围的100%
- 偏航角 (yaw): 均匀分布于±180°(全圆)
- 固定物体: 名称含
bin的容器保持固定;其他资产(包括bowl)与目标一起随机化。 - 存储的偏航角为绝对角度,已包含各资产的场景默认方向。
- 所有初始布局来自预生成的物理验证布局数据集(
DAVIAN-Robotics/robolab-init-positions),不存在物体互相穿透的初始状态。
记录规范
| 字段 | 规范 |
|---|---|
| 臂部动作 | 绝对关节目标(DROID帧,j7偏移−π/4) |
| 夹爪动作 | 二值 {0, 1}(raw > 0 → close) |
| 状态 | 完整关节向量(teleport-native) |
| 成功标准 | K-hold settle,success_hold_steps = 15,达到成功即截断片段 |
| 相机 | over_shoulder_left_camera, wrist_cam |
| 帧率 | 15 |
重要说明:夹爪动作为二值形式。早期版本中连续夹爪信号会高估下游策略质量,请勿从二值信号重新推导连续通道。
数据特征
- 动作 (action): float32,形状[8],包含电动机:j0, j1, j2, j3, j4, j5, j6, gripper,帧率15
- 状态 (observation.state): float32,形状[8],包含关节:joint_0至joint_7,帧率15
- 速度 (observation.velocity): float32,形状[8],帧率15
- 图像 (observation.images): 两个相机视图(over_shoulder_left_camera 和 wrist_cam),均为270×480×3像素,AVC1编码,yuv420p像素格式,帧率15
- 其他字段: episode_index, frame_index, index, task_index, timestamp, next.done
元数据
meta/provenance.json:记录了采样模式、初始姿态等级、动作/夹爪约定、保持长度等溯源信息。meta/stats.json:包含q01/q99分位数统计(用于pi0.5分位数归一化),在聚合后计算。- 所有视频已应用恒定帧率(CFR)规范化处理(解决PTS抖动问题)。
文件结构与大小
- 数据文件: parquet格式,路径
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet,大小约100 MB - 视频文件: mp4格式,路径
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4,大小约200 MB - 分块大小: 1000
可视化
可通过LeRobot数据集可视化工具查看:Open in the LeRobot dataset visualizer
其他信息
- 数据集完全合成,由本项目在仿真环境中生成,无第三方录制内容。
- 主页、论文和引用信息均为"More Information Needed"。