LHPR-VLN
收藏资源简介:
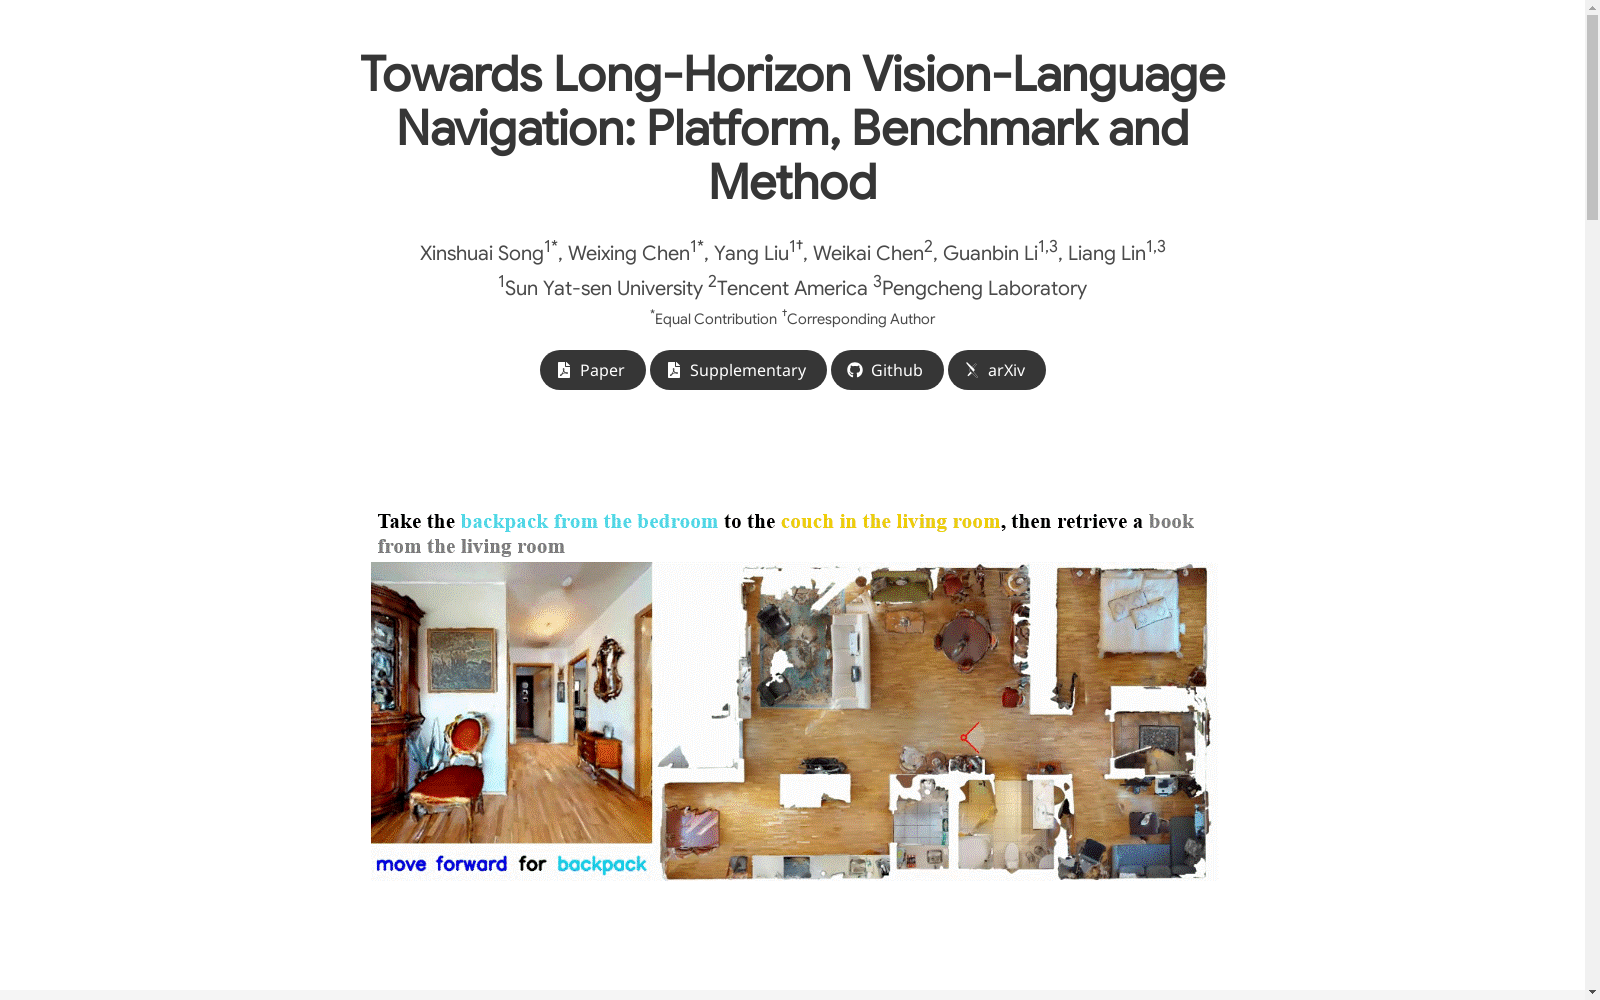
LHPR-VLN数据集是由中山大学开发的一个用于长时程视觉语言导航任务的基准数据集。该数据集包含3260个任务,平均每个任务有150个步骤,旨在模拟复杂的多阶段导航任务。数据集通过自动化的数据生成平台NavGen创建,采用双向多粒度生成方法,确保任务的多样性和复杂性。创建过程中,利用GPT-4生成任务指令,并通过Habitat3模拟器生成轨迹数据。LHPR-VLN数据集主要应用于评估和提升机器人在复杂环境中的导航能力,特别是在需要长时间规划和多阶段任务执行的场景中。
The LHPR-VLN dataset is a benchmark dataset developed by Sun Yat-sen University for long-term visual-language navigation tasks. This dataset contains 3,260 tasks, with an average of 150 steps per task, and aims to simulate complex multi-stage navigation tasks. It was created via the automated data generation platform NavGen, adopting a bidirectional multi-granularity generation method to ensure the diversity and complexity of the tasks. During its development, task instructions were generated using GPT-4, and trajectory data was produced via the Habitat3 simulator. The LHPR-VLN dataset is primarily used to evaluate and enhance the navigation capabilities of robots in complex environments, particularly in scenarios requiring long-term planning and multi-stage task execution.