ramen-noodels/red_button_small_n25
收藏资源简介:
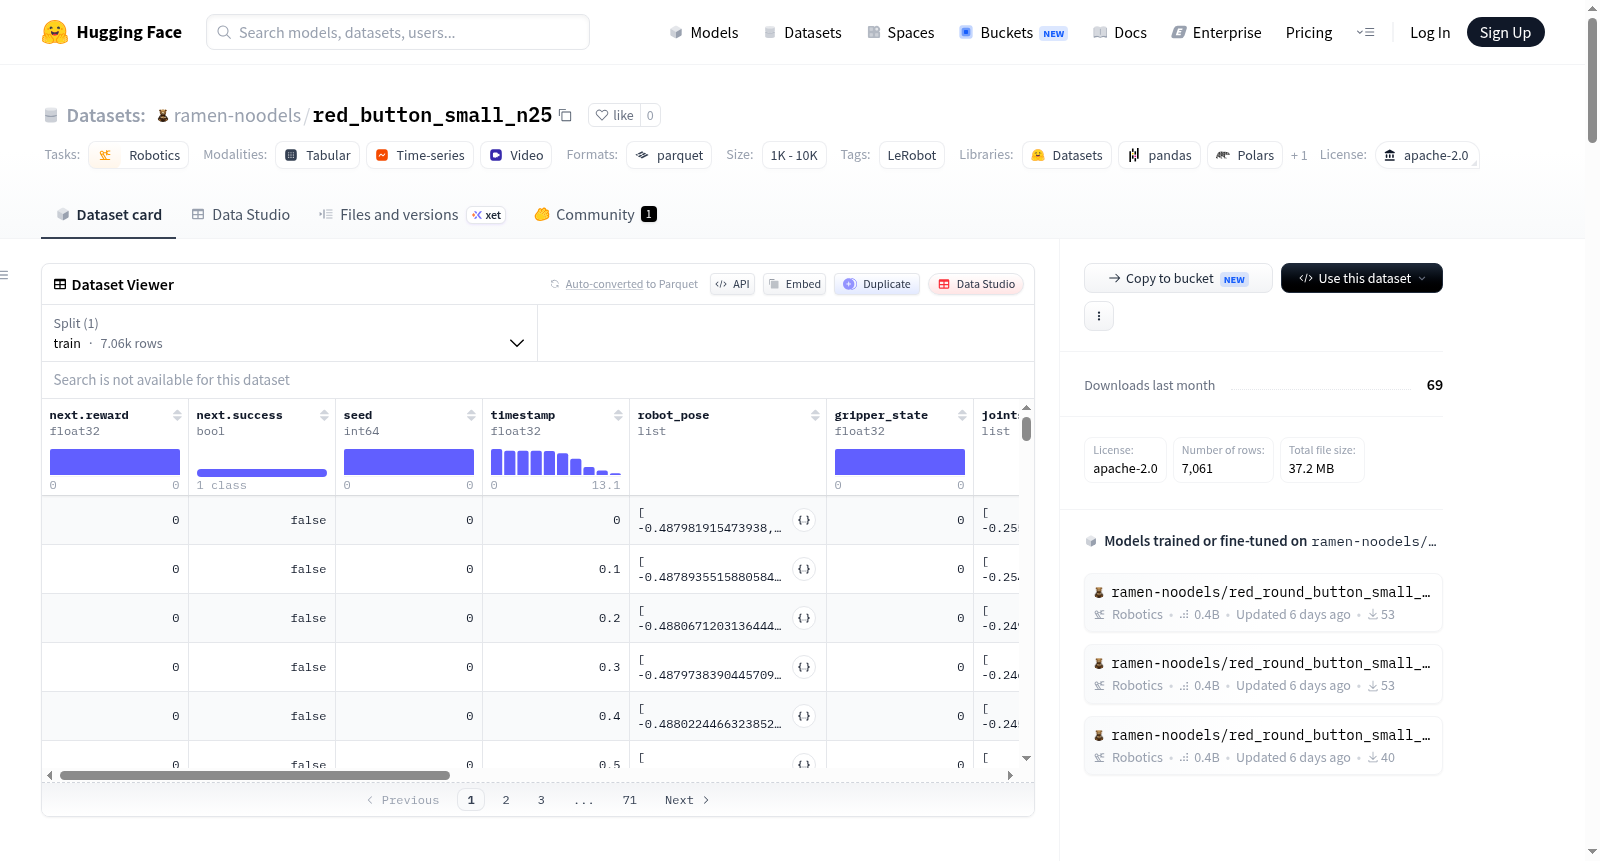
该数据集由LeRobot项目创建,专注于机器人学任务。它包含75个episodes,总计7061帧,帧率为10fps。数据以parquet文件格式存储,并附带mp4格式的视频文件,总数据大小约为100MB,视频文件大小约为200MB。数据集仅包含一个任务,并分为训练集(涵盖所有episodes)。特征包括:next.reward(奖励值,float32类型)、next.success(成功标志,bool类型)、seed(种子值,int64类型)、timestamp(时间戳,float32类型)、robot_pose(机器人姿态,6维float32数组)、gripper_state(夹爪状态,float32类型)、joints(关节状态,6维float32数组)、ft(力/力矩数据,6维float32数组)、btn_state(按钮状态,float32类型)、action(动作,9维float64数组)、frame_index(帧索引,int64类型)、episode_index(episode索引,int64类型)、index(索引,int64类型)、task_index(任务索引,int64类型)、observation.state(观测状态,float32类型)。此外,观测数据包括来自手腕摄像头的图像(observation.images.wrist_image,视频格式,3通道,240x320分辨率,使用av1编解码器)和音频频谱图(observation.audio.spectogram_values,视频格式,3通道,298x128分辨率,使用av1编解码器)。这些特征支持机器人控制、感知和强化学习应用。
This dataset was created using the LeRobot project and focuses on robotics tasks. It consists of 75 episodes, totaling 7061 frames with a frame rate of 10fps. The data is stored in parquet file format and accompanied by video files in mp4 format, with a total data size of approximately 100MB and video file size of about 200MB. The dataset includes only one task and is split into a training set (covering all episodes). Features include: next.reward (reward value, float32 type), next.success (success flag, bool type), seed (seed value, int64 type), timestamp (timestamp, float32 type), robot_pose (robot pose, 6-dimensional float32 array), gripper_state (gripper state, float32 type), joints (joint states, 6-dimensional float32 array), ft (force/torque data, 6-dimensional float32 array), btn_state (button state, float32 type), action (action, 9-dimensional float64 array), frame_index (frame index, int64 type), episode_index (episode index, int64 type), index (index, int64 type), task_index (task index, int64 type), observation.state (observation state, float32 type). Additionally, observation data includes images from a wrist camera (observation.images.wrist_image, video format, 3 channels, 240x320 resolution, using av1 codec) and audio spectrograms (observation.audio.spectogram_values, video format, 3 channels, 298x128 resolution, using av1 codec). These features support applications in robot control, perception, and reinforcement learning.