TartanGround
收藏资源简介:
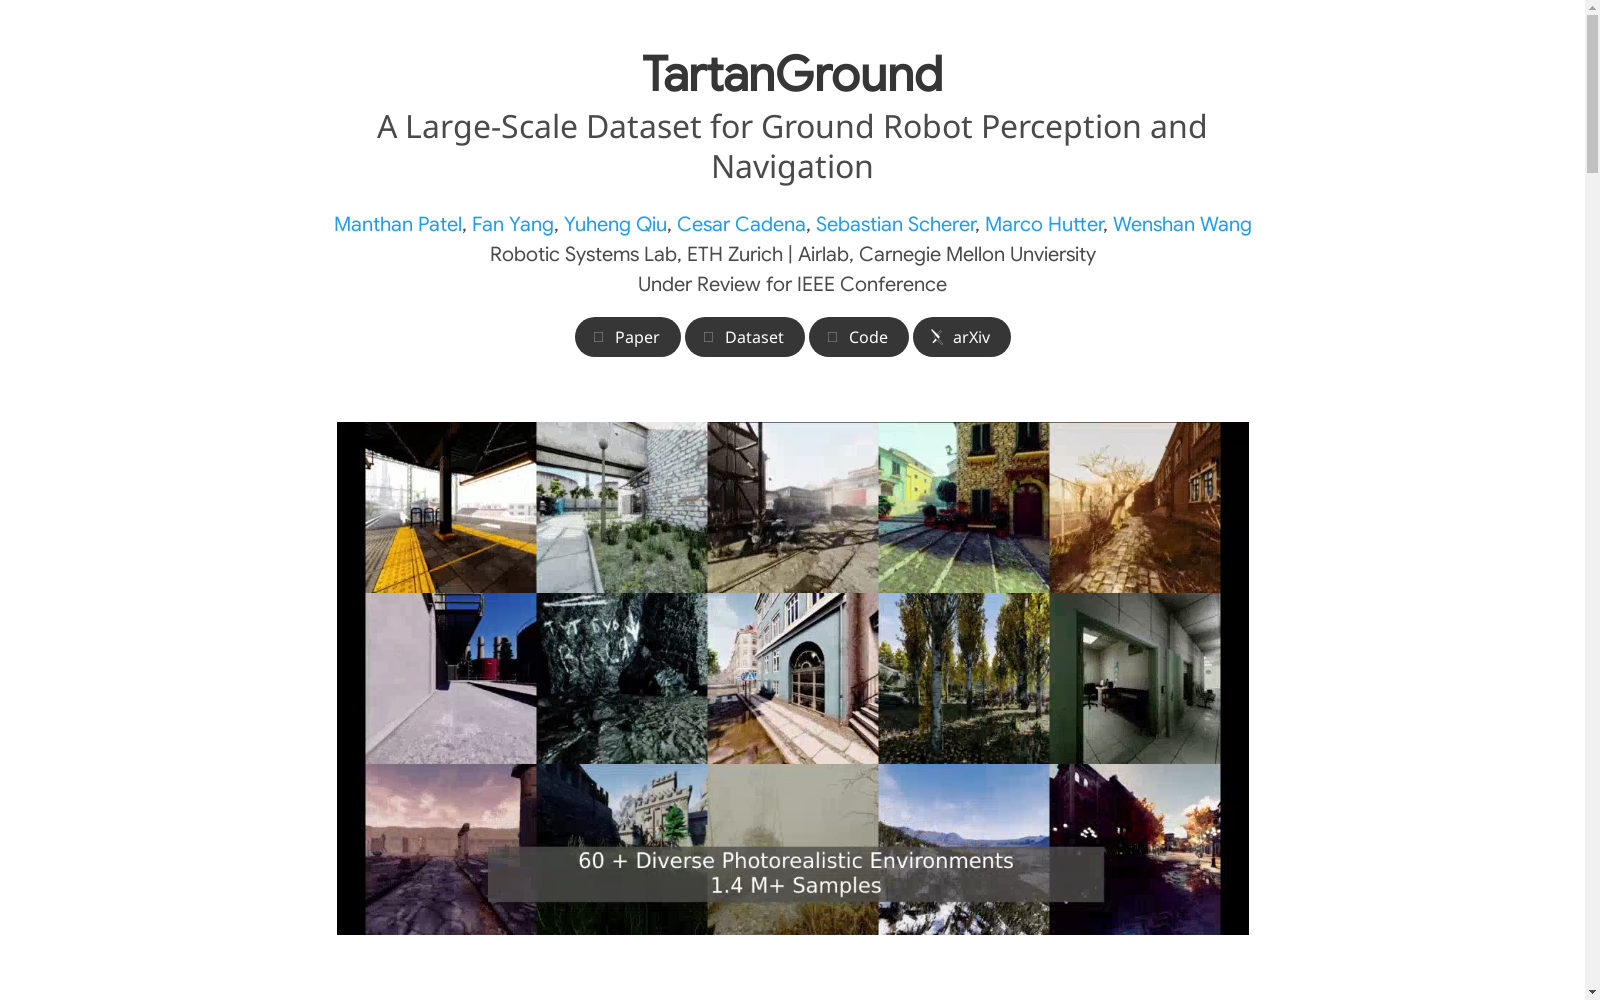
TartanGround是一个大规模的多模态数据集,旨在推进地面机器人在各种环境中的感知和自主性。该数据集收集于各种逼真的模拟环境,包括多台RGB立体相机、深度、光流、立体视差、激光雷达点云、真实姿态、语义分割图像和具有语义标签的占用图。数据采用自动集成流程收集,生成模拟各种地面机器人平台运动模式的轨迹,包括轮式和腿式机器人。我们在70个环境中收集了910个轨迹,产生了150万个样本。在占用预测和SLAM任务上的评估表明,在现有数据集上训练的最先进方法难以推广到多样化的场景中。TartanGround可以作为各种基于学习的任务的训练和评估平台,包括占用预测、SLAM、神经场景表示、基于感知的导航等,以实现机器感知和自主性的进步,使其更广泛地应用于各种场景。
TartanGround is a large-scale multimodal dataset designed to advance the perception and autonomy of ground robots across diverse environments. This dataset is collected across various realistic simulated environments, containing data from multiple RGB stereo cameras, depth maps, optical flow, stereo disparity, LiDAR point clouds, ground-truth poses, semantic segmentation images, and occupancy maps with semantic labels. The data is collected via an automated integration pipeline, generating trajectories that simulate the movement patterns of various ground robot platforms, including wheeled and legged robots. We collected 910 trajectories across 70 environments, yielding a total of 1.5 million samples. Evaluations on occupancy prediction and SLAM tasks demonstrate that state-of-the-art methods trained on existing datasets struggle to generalize to diverse scenarios. TartanGround can serve as a training and evaluation platform for a variety of learning-based tasks, including occupancy prediction, SLAM, neural scene representations, perception-based navigation, and more, to advance machine perception and autonomy and enable their broader deployment across diverse scenarios.