ROV6D
收藏资源简介:
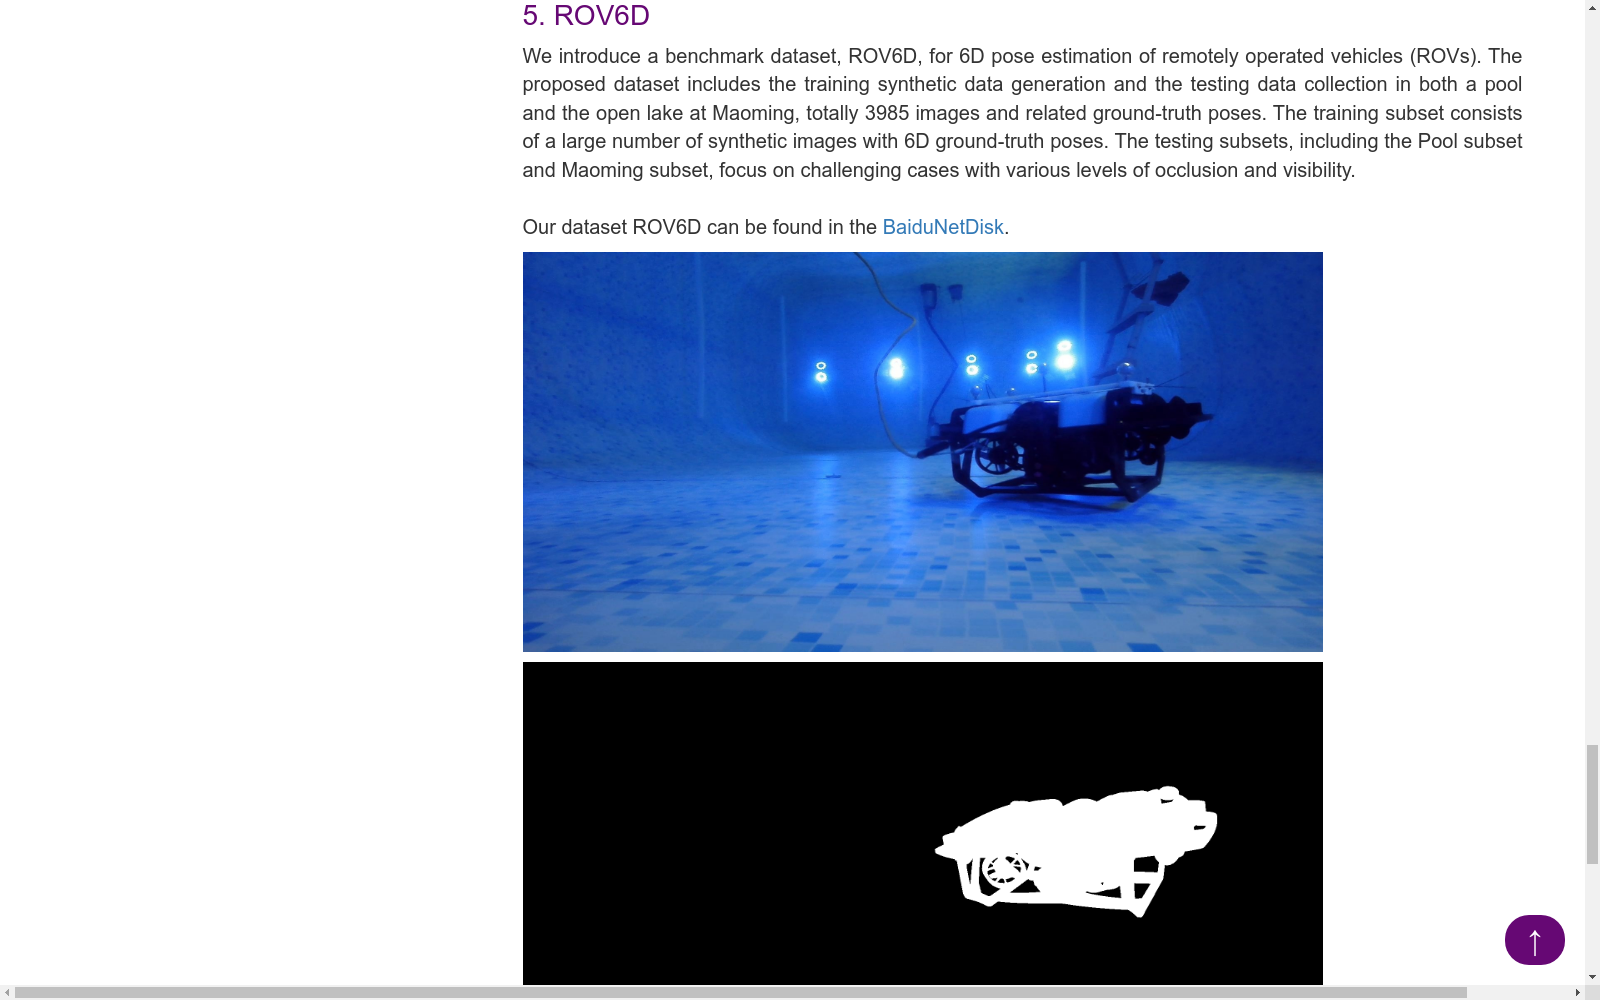
ROV6D 是一个面向水下遥控机器人(ROV)六自由度位姿估计任务的基准数据集,旨在支持复杂真实场景下的算法评测与研究。该数据集同时包含基于合成数据的训练集和来自真实环境的测试集,共计 3985 张图像,并提供精确的 6D 位姿标注。训练集由大量带有完整位姿真值的合成图像构成,用于提升模型的泛化能力;测试集则分别采集于受控水池环境和茂名开放水域,重点覆盖不同遮挡程度和可见性条件下的挑战性场景,以更真实地反映水下作业环境中的实际难度。ROV6D 数据集目前通过百度网盘提供获取。
ROV6D is a benchmark dataset for the 6-degree-of-freedom (6DoF) pose estimation task of underwater remotely operated vehicles (ROVs), designed to support algorithm evaluation and research in complex real-world scenarios. This dataset includes both a synthetic training set and a real-world test set, with a total of 3985 images, and provides accurate 6D pose annotations. The training set consists of a large number of synthetic images with complete ground-truth poses, which is used to enhance the generalization capability of models. The test set was collected from both a controlled pool environment and the open waters of Maoming, focusing on challenging scenarios with varying degrees of occlusion and visibility conditions, to more realistically reflect the actual difficulty of underwater operational environments. Currently, the ROV6D dataset is available for acquisition via Baidu Wangpan.