
CARLA-Loc
收藏资源简介:
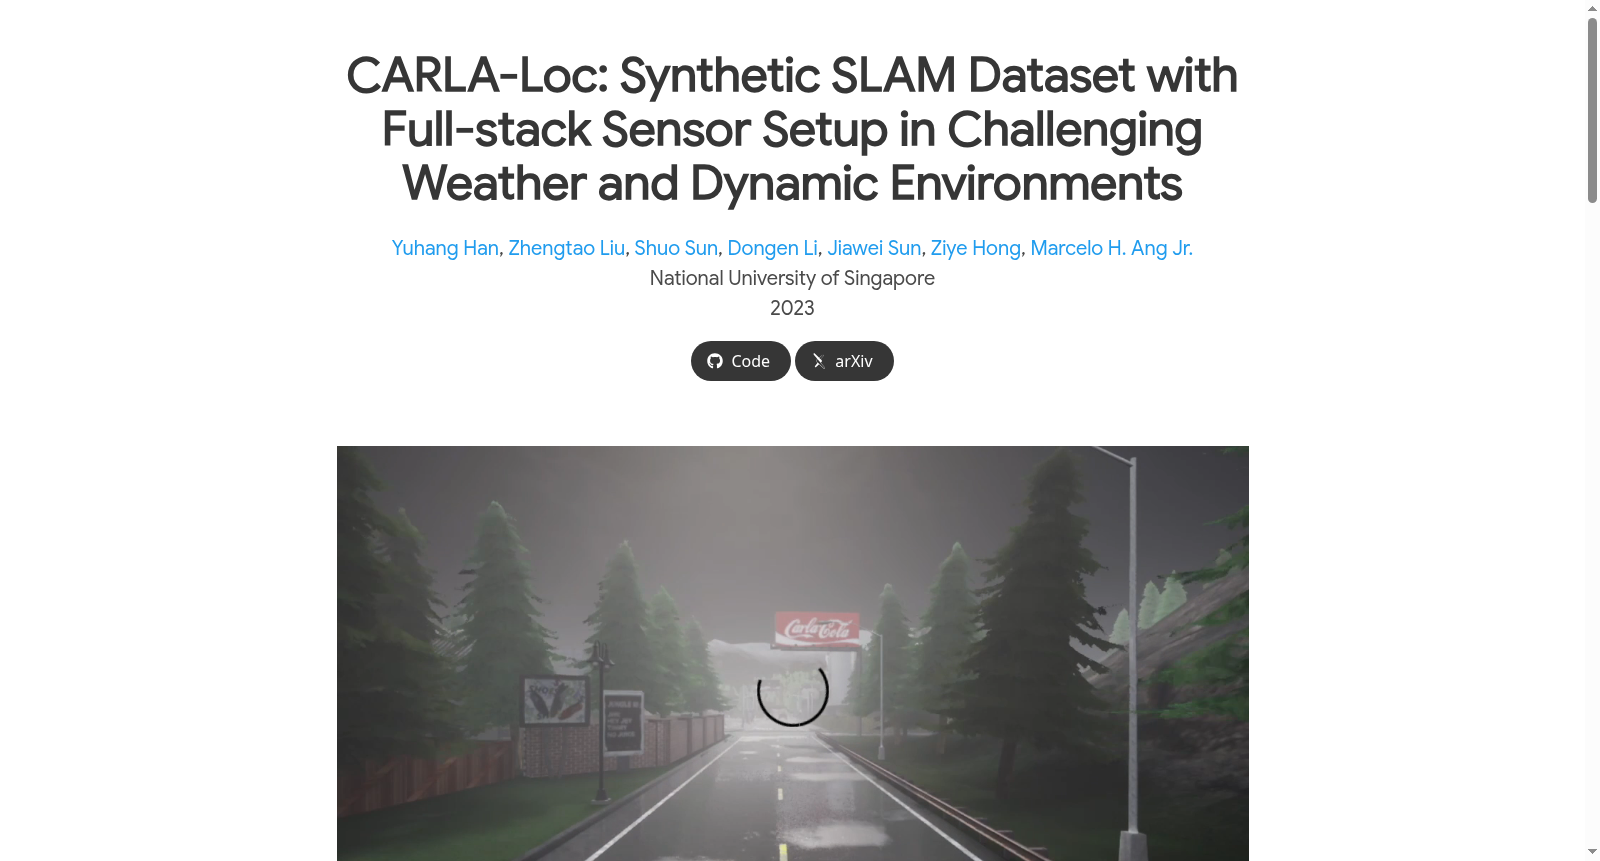
CARLA-Loc数据集是由新加坡国立大学先进机器人中心开发的一个合成数据集,专门设计用于评估在具有挑战性的动态环境中的SLAM(同时定位与地图构建)算法。该数据集利用CARLA模拟器创建,集成了多种传感器,包括摄像头、事件摄像头、激光雷达、雷达和IMU等,以确保生成数据的真实性。CARLA-Loc包含7个地图和42个序列,每个序列在动态性和天气条件上都有所不同。此外,还提供了一个管道脚本,使用户能够方便地生成自定义序列。数据集主要用于验证SLAM算法在多样条件下的有效性,特别是在自动驾驶领域的应用。
CARLA-Loc dataset is a synthetic dataset developed by the Advanced Robotics Center of the National University of Singapore, specifically designed to evaluate SLAM (Simultaneous Localization and Mapping) algorithms in challenging dynamic environments. Created using the CARLA simulator, this dataset integrates multiple sensors including cameras, event cameras, LiDAR, radar, IMU and others to ensure the authenticity of the generated data. CARLA-Loc comprises 7 maps and 42 sequences, with each sequence differing in terms of dynamics and weather conditions. Additionally, a pipeline script is provided to allow users to conveniently generate custom sequences. This dataset is primarily intended to validate the effectiveness of SLAM algorithms across diverse conditions, particularly for applications in the autonomous driving field.
- 1CARLA-Loc: Synthetic SLAM Dataset with Full-stack Sensor Setup in Challenging Weather and Dynamic Environments新加坡国立大学先进机器人中心 · 2024年


