zijian2022/t8401
收藏资源简介:
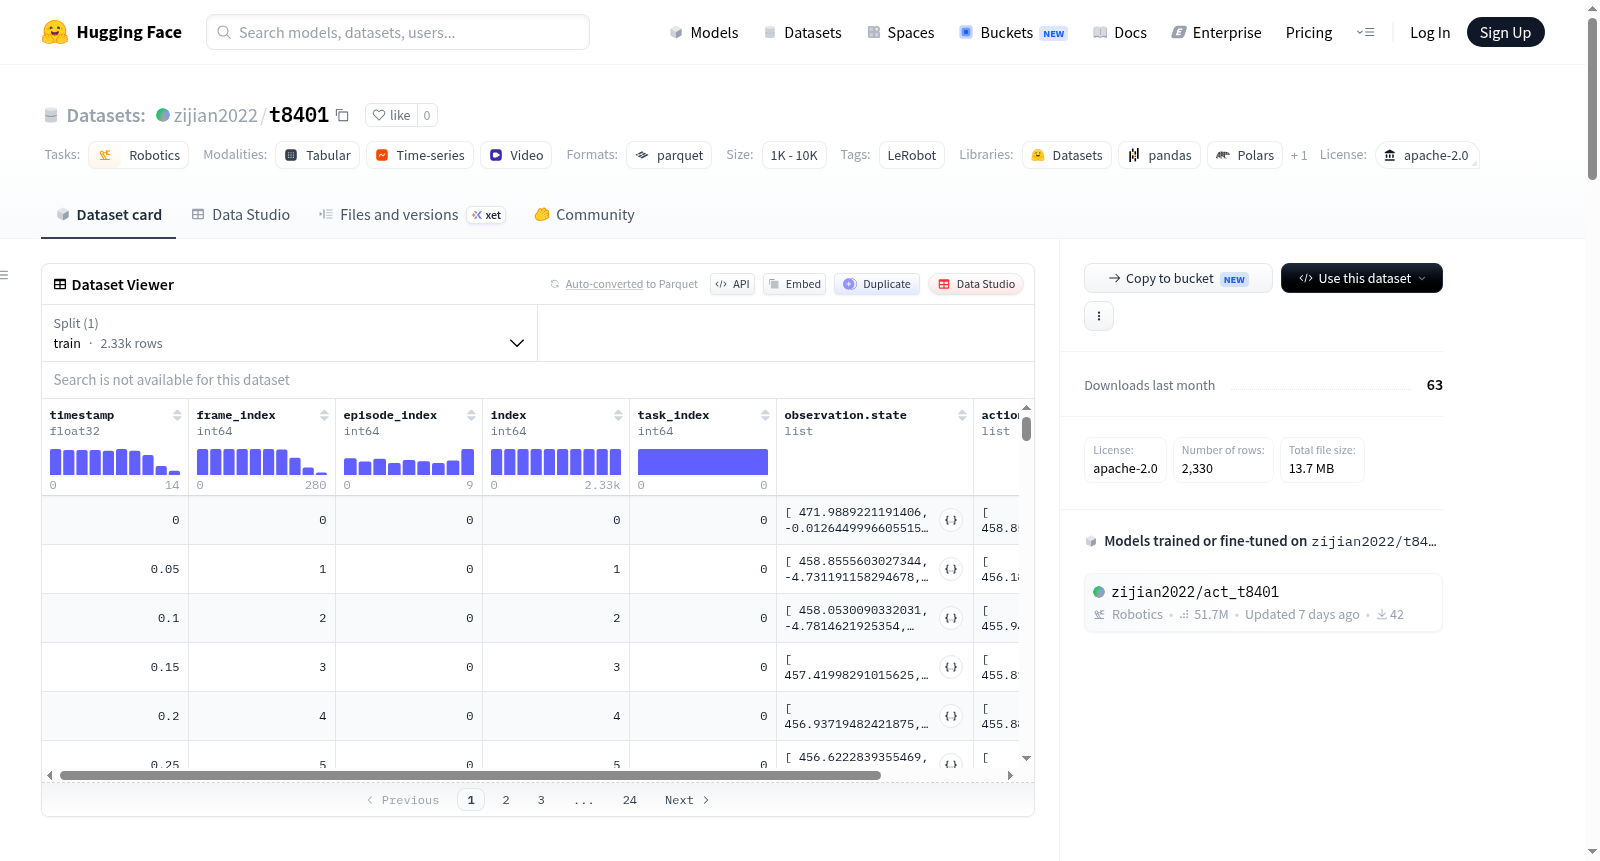
该数据集使用LeRobot创建,专为机器人学任务设计。数据集包含10个完整的情节(episodes),总计2330帧,涉及1个任务。数据以parquet格式存储,总数据文件大小为100MB,视频文件大小为200MB,帧率为20帧/秒。数据集采用xarm机器人类型,代码库版本为v3.0。数据结构包括时间戳、帧索引、情节索引、索引、任务索引等特征。观测状态包含10维的关节状态(j0, j1, j2, r0, r1, r2, r3, r4, r5, j7)和顶部摄像头图像(分辨率为480x640,3通道,视频编码为av1,帧率30帧/秒)。动作特征同样为10维,对应关节控制。数据集仅包含训练分割(索引0到10),数据路径和视频路径按块和文件索引组织。
This dataset was created using LeRobot and is designed for robotics tasks. It contains 10 total episodes with 2330 total frames, covering 1 task. The data is stored in parquet format, with a total data file size of 100MB and video file size of 200MB, at a frame rate of 20 fps. The dataset uses the xarm robot type with a codebase version of v3.0. The structure includes features such as timestamp, frame index, episode index, index, task index, etc. Observations consist of a 10-dimensional joint state (j0, j1, j2, r0, r1, r2, r3, r4, r5, j7) and top camera images (resolution 480x640, 3 channels, video codec av1, fps 30). Actions are also 10-dimensional, corresponding to joint control. The dataset only includes a train split (indices 0 to 10), with data and video paths organized by chunk and file indices.