Sendera/pick0430p4
收藏资源简介:
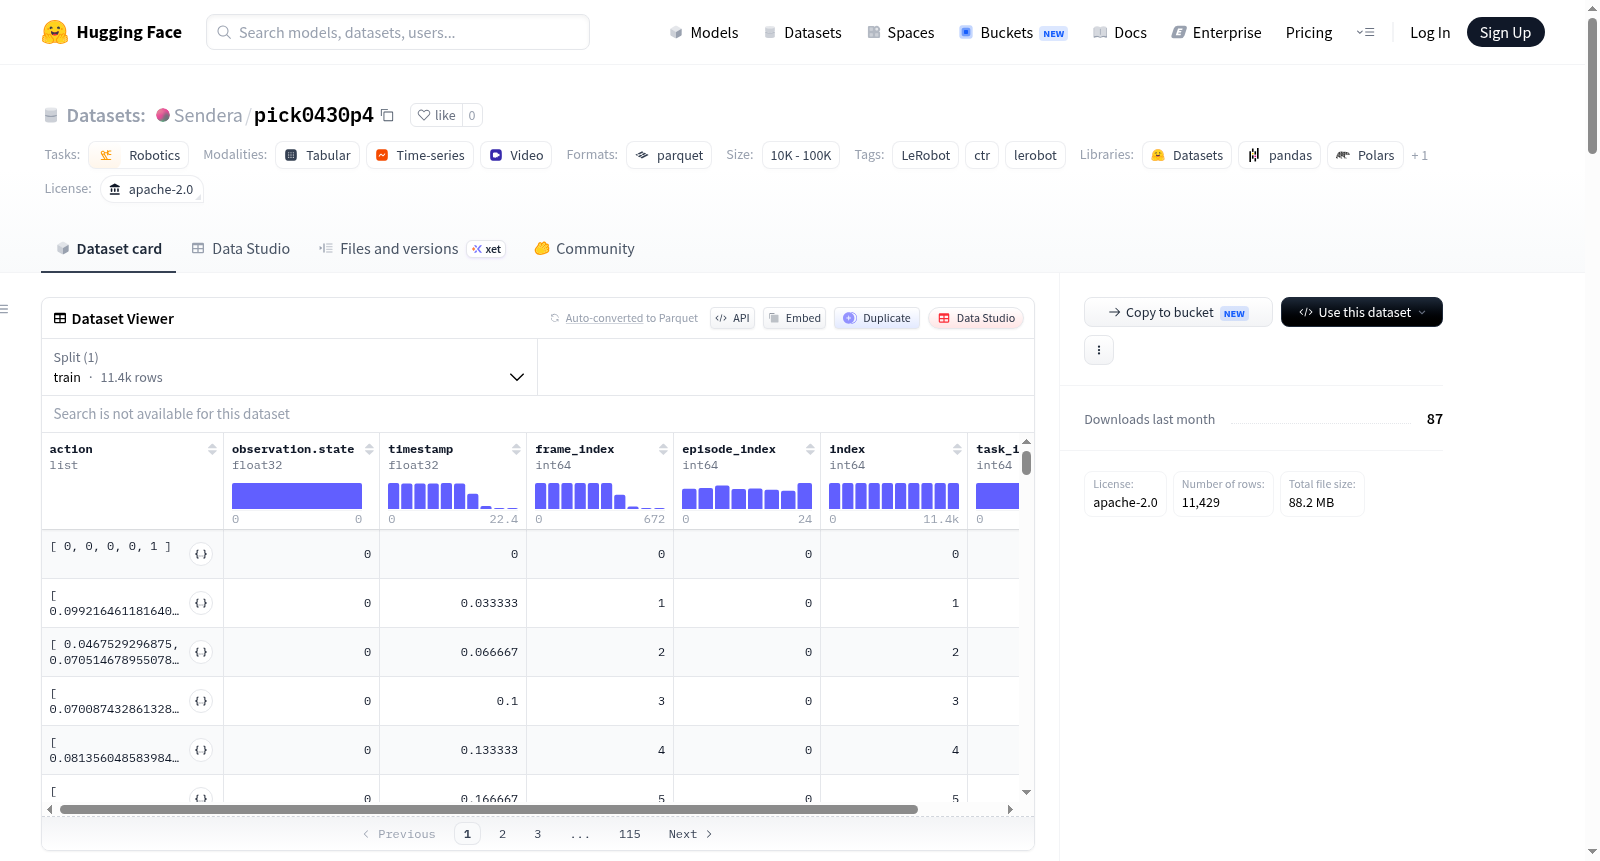
该数据集由LeRobot创建,主要用于机器人技术领域。数据集包含25个episodes,11429帧,1个任务。数据特征包括动作(dx, dy, dz, dr, gripper_cmd)、观测状态(dummy_state)、三个全局摄像头(Cam1_global, Cam2_global, Cam3_global)的图像数据,以及时间戳、帧索引、episode索引等元数据。图像分辨率为400x400,帧率为30fps。数据以parquet格式存储,视频以mp4格式存储。数据集遵循apache-2.0许可证。
This dataset was created by LeRobot and is primarily used in the field of robotics. It contains 25 episodes, 11429 frames, and 1 task. The features include actions (dx, dy, dz, dr, gripper_cmd), observation states (dummy_state), images from three global cameras (Cam1_global, Cam2_global, Cam3_global), as well as metadata such as timestamps, frame indices, and episode indices. The image resolution is 400x400 with a frame rate of 30fps. Data is stored in parquet format, and videos are stored in mp4 format. The dataset is licensed under apache-2.0.