
Physical Human-Humanoid Data (PH2D)
收藏资源简介:
PH2D数据集是一个大规模的任务导向型 egocentric 人类-人形机器人数据集,由加州大学圣地亚哥分校等机构收集。该数据集包含26824个任务导向的人类演示,采用消费者级VR设备收集,提供了准确的3D手部关键点姿态和语言注释。数据集覆盖了多种操作任务、不同的物体和容器,旨在通过模仿人类行为来学习人形机器人的操作策略,促进跨模态学习并提高机器人政策的泛化能力和鲁棒性。
The PH2D Dataset is a large-scale task-oriented egocentric human-humanoid robot dataset collected by the University of California, San Diego and other institutions. It contains 26,824 task-oriented human demonstrations collected via consumer-grade VR devices, and provides accurate 3D hand keypoint poses and linguistic annotations. The dataset covers a variety of manipulation tasks, diverse objects and containers, and aims to learn manipulation strategies for humanoid robots by imitating human behaviors, promote cross-modal learning, and improve the generalization ability and robustness of robot policies.
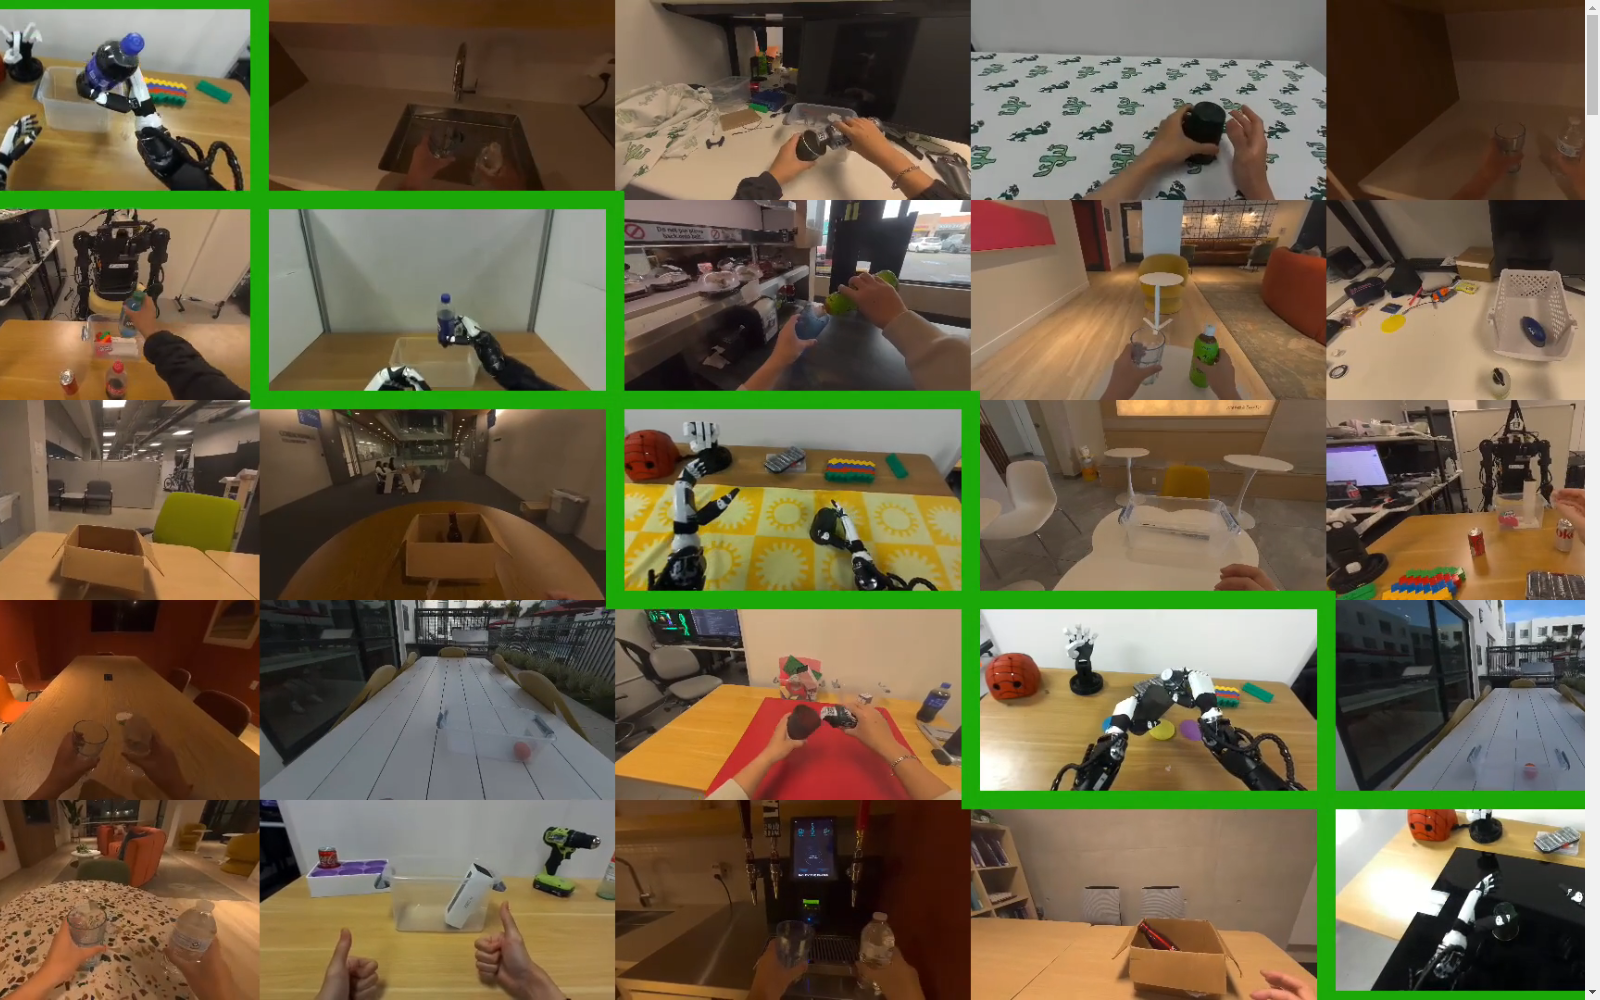
- 1Humanoid Policy ~ Human Policy加州大学圣地亚哥分校, 卡内基梅隆大学, 华盛顿大学, 麻省理工学院 · 2025年


