UMI
收藏资源简介:
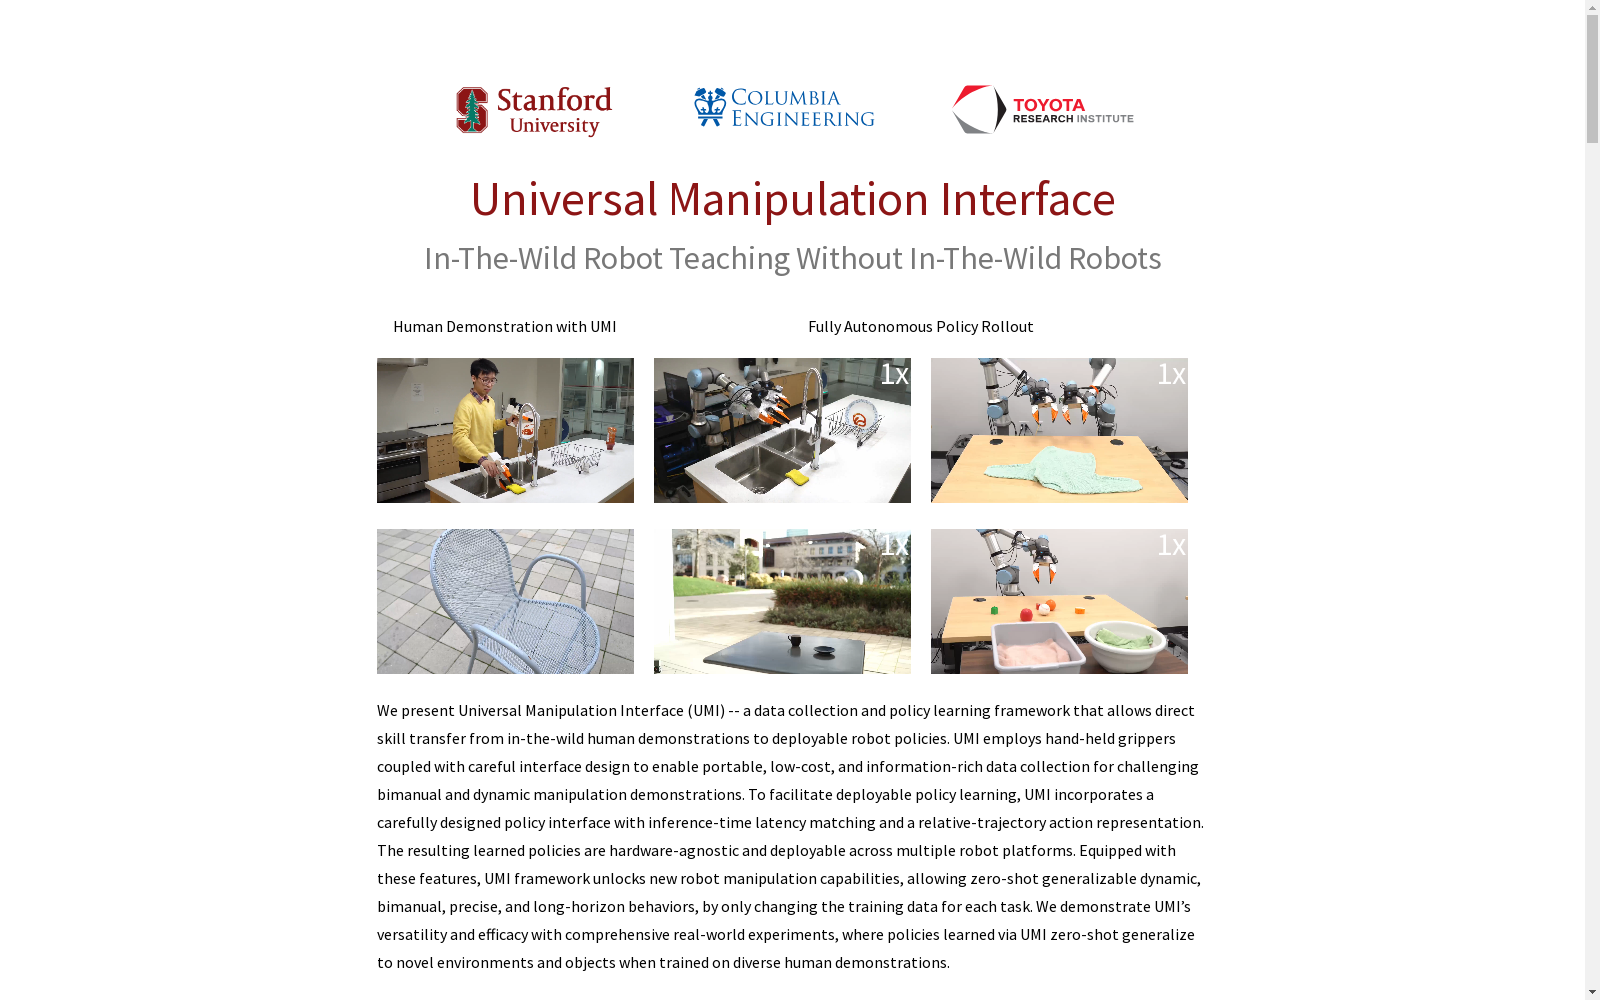
UMI是由斯坦福大学、哥伦比亚大学和丰田研究所联合开发的便携式、低成本数据收集与策略学习框架,旨在将人类在真实环境中的操作技能直接转化为可部署的机器人策略。该框架通过手持式夹具和精心设计的接口,实现复杂双臂和动态操作任务的数据收集。UMI数据集包含多样的操作任务,涵盖动态、双臂、精确和长时域等场景,数据来源广泛,包括实验室和真实环境。数据集的创建过程通过手持式夹具和GoPro相机进行操作演示,利用视觉惯性SLAM技术实现精确的动作捕捉。UMI数据集的应用领域主要集中在机器人操作技能的迁移与泛化,能够为不同机器人平台提供通用的策略学习基础,显著提升机器人在复杂环境中的适应能力。
UMI is a portable, low-cost data collection and policy learning framework jointly developed by Stanford University, Columbia University, and Toyota Research Institute, designed to directly translate human operational skills in real-world environments into deployable robotic policies. This framework facilitates data collection for complex dual-arm and dynamic manipulation tasks through hand-held grippers and well-engineered interfaces. The UMI dataset includes a diverse array of manipulation tasks, covering scenarios such as dynamic manipulation, dual-arm operations, precision tasks, and long-horizon settings, with broad data sources ranging from laboratory environments to real-world environments. The dataset is created via operation demonstrations conducted using hand-held grippers and GoPro cameras, leveraging visual-inertial SLAM technology to enable precise motion capture. The primary application areas of the UMI dataset center on the transfer and generalization of robotic manipulation skills, offering a universal policy learning foundation for various robotic platforms and substantially enhancing the adaptability of robots in complex environments.