NavRAG
收藏资源简介:
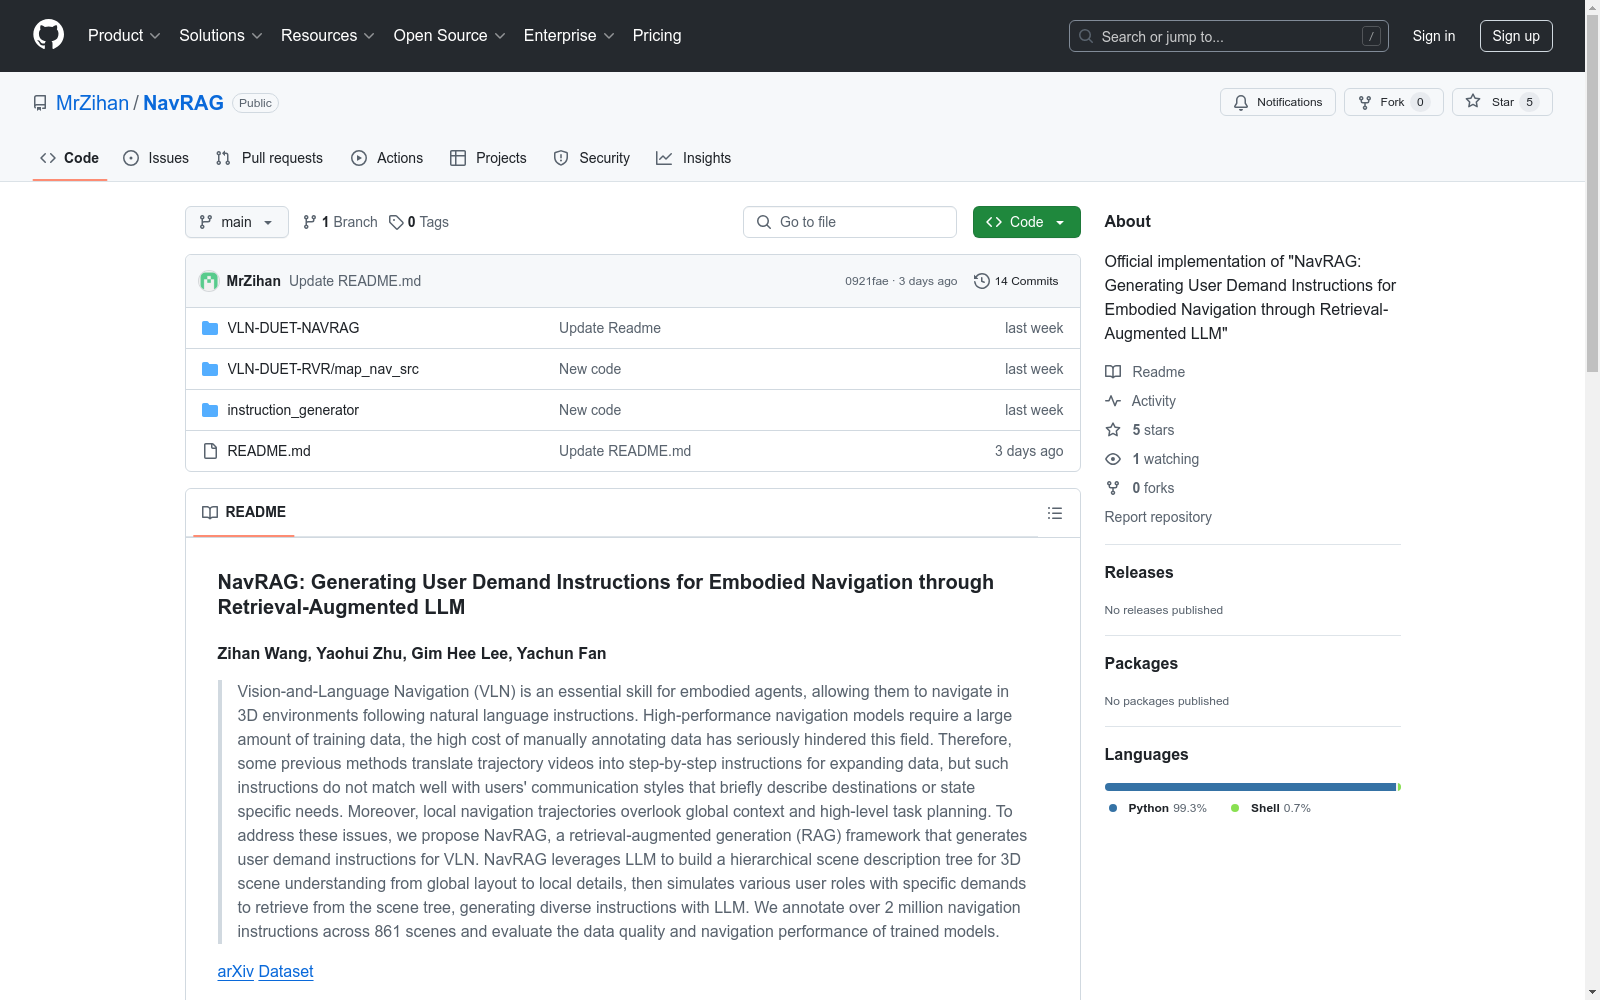
NavRAG是一个检索增强生成框架,用于为视觉语言导航生成用户需求指令。NavRAG利用LLM构建从全局布局到局部细节的3D场景描述树,然后模拟具有特定需求的用户角色从场景树中检索,生成多样化的指令。
NavRAG is a retrieval-augmented generation framework designed for generating user demand instructions for vision-language navigation. NavRAG leverages LLMs to construct a 3D scene description tree spanning from global layout to local details, then simulates user roles with specific requirements to retrieve information from the scene tree and generate diverse instructions.
NavRAG 数据集概述
数据集简介
- 名称:NavRAG
- 用途:为具身导航生成用户需求指令
- 领域:视觉与语言导航(VLN)
- 核心问题:解决手动标注数据成本高、现有指令与用户沟通风格不匹配、局部导航轨迹忽略全局上下文等问题
数据集特点
- 数据规模:标注超过200万条导航指令,覆盖861个场景
- 生成方法:采用检索增强生成(RAG)框架,利用LLM构建分层场景描述树
- 多样性:模拟不同用户角色生成多样化指令
数据集内容
- 场景数据:
- Matterport3D (MP3D)
- Habitat-Matterport 3D (HM3D)
- 预训练特征文件:包含在数据下载包中
- 检查点文件:包含在数据下载包中
获取方式
- 下载地址:
- TeraBox: https://1024terabox.com/s/1D5HEHsaW5AcWTjjIO15jpA
- 百度网盘: https://pan.baidu.com/s/15UoGbtPU3A9XPrq3R9fDsg?pwd=2fny
相关工具
- 模拟器要求:
- Matterport3D模拟器
- Habitat模拟器(可选)
使用方法
-
预训练: bash cd VLN-DUET-NAVRAG/pretrain_src bash run_rag_h14.sh "0,1" 2345
-
微调/评估: bash cd VLN-DUET-NAVRAG/map_nav_src bash scripts/rag_h14_envedit_mix.sh "0,1" 2346
引用格式
bibtex @article{wang2025navrag, title={NavRAG: Generating User Demand Instructions for Embodied Navigation through Retrieval-Augmented LLM}, author={Wang, Zihan and Zhu, Yaohui and Lee, Gim Hee and Fan, Yachun}, journal={arXiv preprint arXiv:2502.11142}, year={2025} }
相关资源
- 论文地址:https://arxiv.org/abs/2502.11142
- 基础代码库:
- DUET: https://github.com/cshizhe/VLN-DUET
- ScaleVLN: https://github.com/wz0919/ScaleVLN
- BEVBert: https://github.com/MarSaKi/VLN-BEVBert