LIUYUYAO/rollout_zihao_grab_dolls_20260529_122146
收藏资源简介:
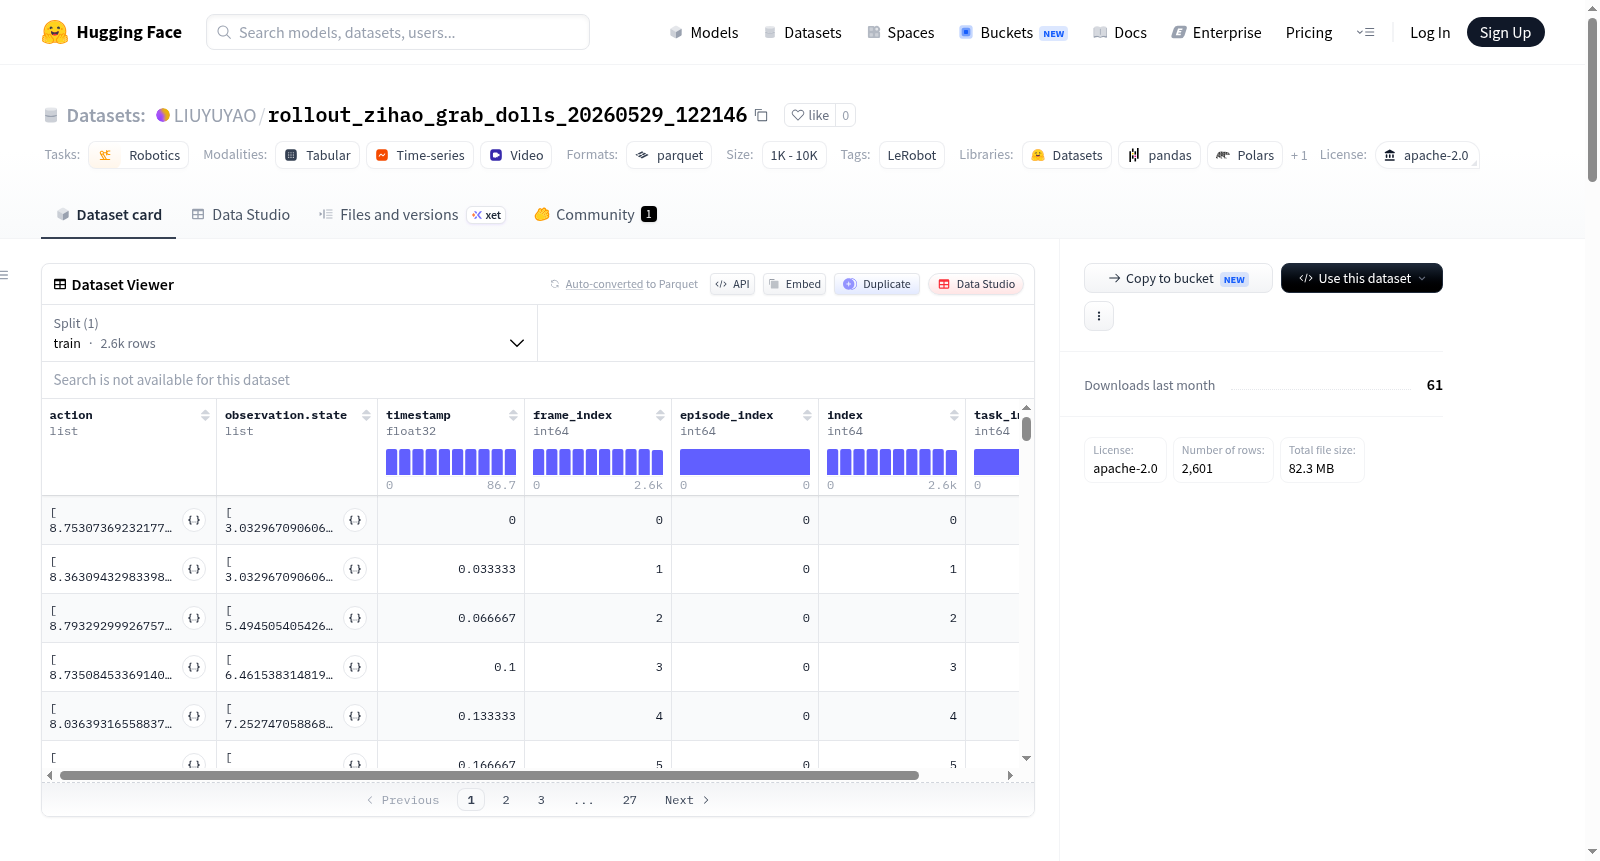
该数据集使用LeRobot创建,专注于机器人学领域,具体任务为抓取玩偶。数据集包含一个总集数,共2601帧,帧率为30fps。特征包括动作(6个浮点值,对应肩部平移、肩部提升、肘部弯曲、腕部弯曲、腕部旋转和夹爪位置)、状态观测(与动作相同的6个浮点值)、前端图像观测(视频格式,分辨率1080x1920,3通道,编码为av1,无音频)、时间戳、帧索引、集索引、索引和任务索引。数据以parquet文件存储,视频文件单独存储,总数据文件大小为100MB,视频文件大小为200MB。机器人类型为so_follower,数据集仅包含训练分割。
This dataset was created using LeRobot and focuses on robotics, specifically for a doll-grabbing task. It contains one total episode with 2601 frames at 30 fps. Features include action (6 float32 values for shoulder pan position, shoulder lift position, elbow flexion position, wrist flexion position, wrist roll position, and gripper position), observation state (same 6 float32 values as action), observation images from the front (video format with 1080x1920 resolution, 3 channels, av1 codec, no audio), timestamp, frame index, episode index, index, and task index. Data is stored in parquet files, with video files stored separately; total data file size is 100MB and video file size is 200MB. The robot type is so_follower, and the dataset includes only a training split.