
PoseGAM Synthetic Dataset
收藏资源简介:
该数据集由阿卜杜拉国王科技大学团队构建,是一个面向6D物体姿态估计任务的大规模合成数据集,包含超过19万个高质量3D物体模型。数据集通过整合Toys4K、3D-FUTURE等多源公开数据,经过严格的几何质量筛选和纹理重烘焙处理,确保模型在光照变化、外观差异等复杂场景下的泛化能力。每个物体配备多视角渲染图像、几何点云图及相机位姿信息,通过Blender标准化流程生成,旨在解决未见物体在机器人操作、增强现实等领域的姿态估计难题。
This dataset was developed by a team from King Abdullah University of Science and Technology (KAUST). It is a large-scale synthetic dataset for 6D object pose estimation tasks, containing over 190,000 high-quality 3D object models. The dataset is constructed by integrating multiple publicly available datasets such as Toys4K and 3D-FUTURE, and undergoes rigorous geometric quality filtering and texture re-baking processing to ensure the generalization capability of the models under complex scenarios including varying lighting conditions and appearance differences. Each object is equipped with multi-view rendered images, geometric point clouds, and camera pose information, which are generated via standardized Blender workflows. This dataset aims to address the pose estimation challenges of unseen objects in fields such as robotic manipulation and augmented reality.
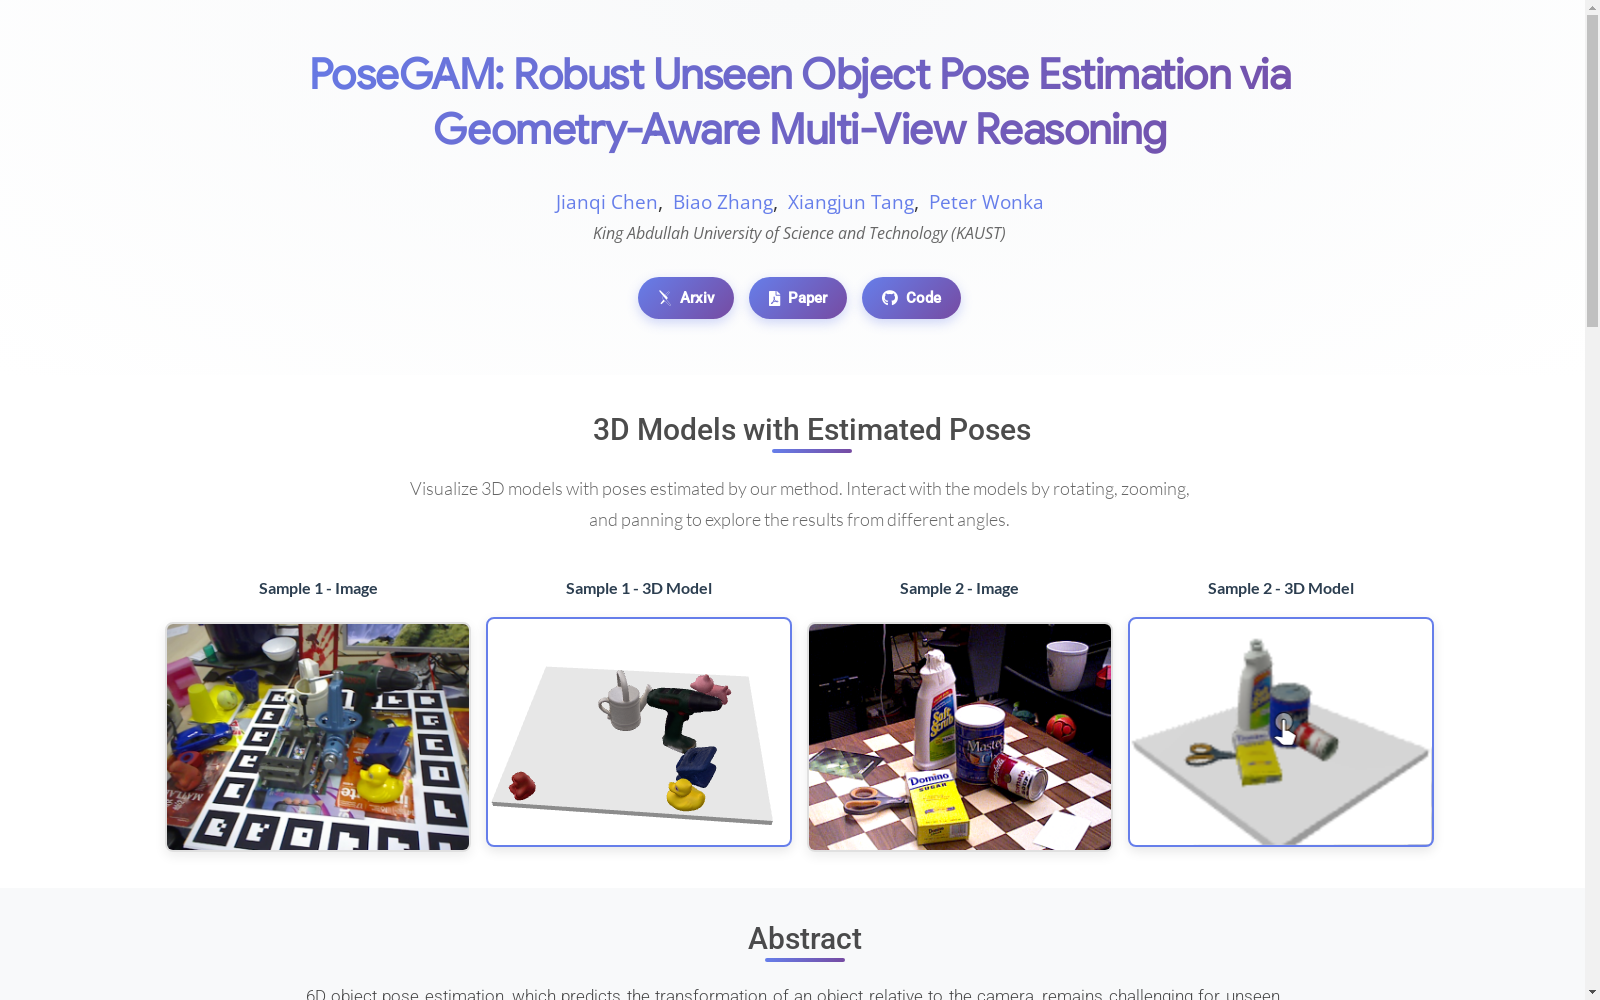
- 1PoseGAM: Robust Unseen Object Pose Estimation via Geometry-Aware Multi-View Reasoning阿卜杜拉国王科技大学 · 2025年


