cf-group-4/cloth_folding_final_consistent_correct_2nd_fold
收藏资源简介:
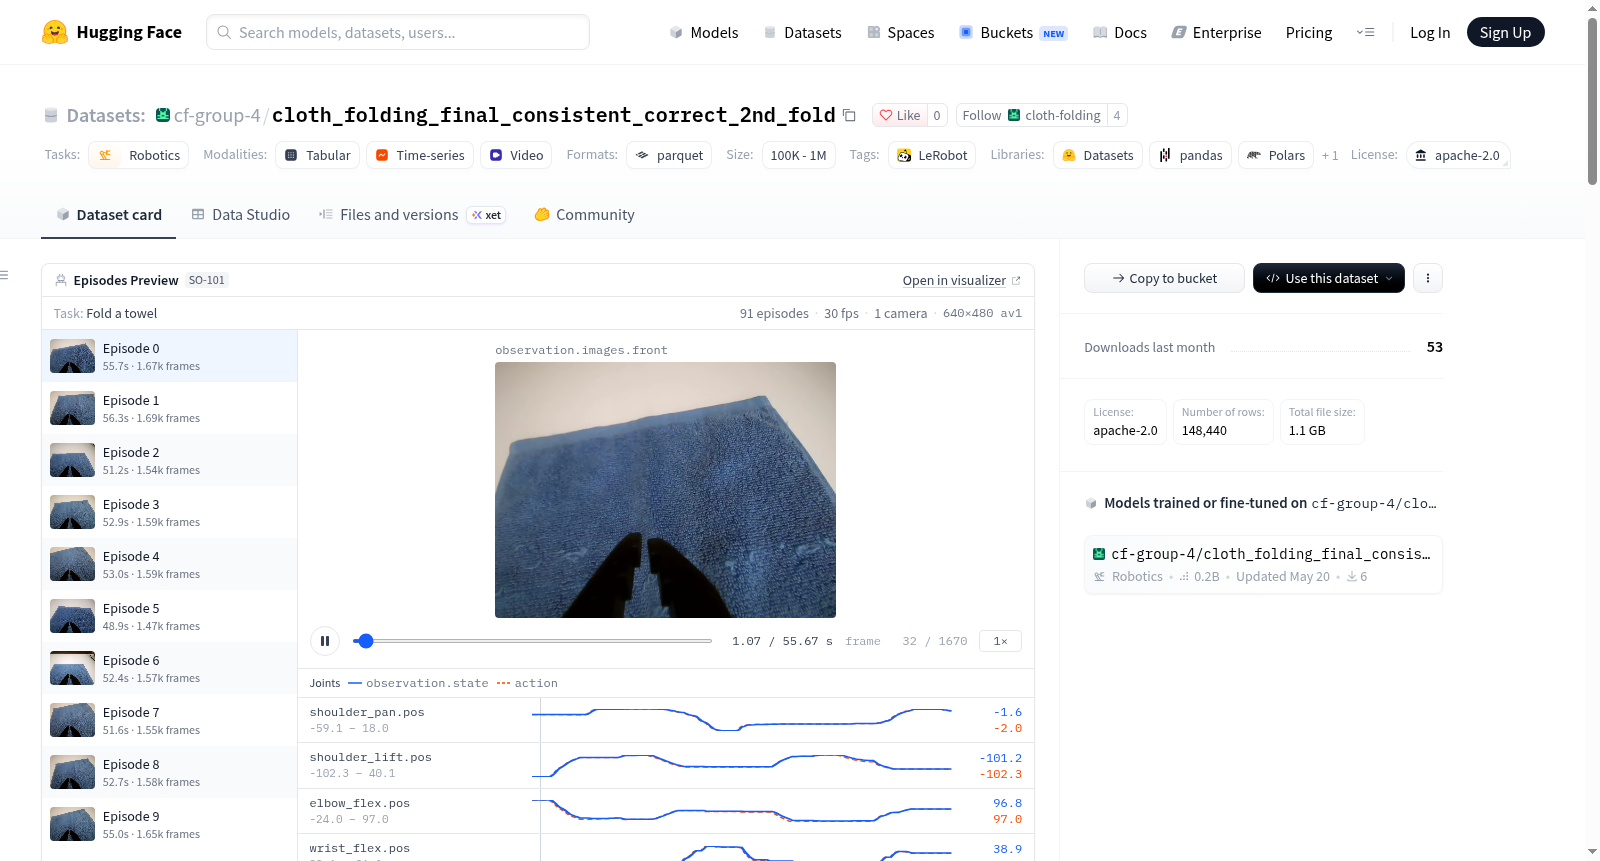
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). <a class="flex" href="https://huggingface.co/spaces/lerobot/visualize_dataset?path=cf-group-4/cloth_folding_final_consistent_correct_2nd_fold"> <img class="block dark:hidden" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl.svg"/> <img class="hidden dark:block" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl-dark.svg"/> </a> ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "robot_type": "so_follower", "total_episodes": 91, "total_frames": 148440, "total_tasks": 1, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "fps": 30, "splits": { "train": "0:91" }, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "features": { "action": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.state": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.images.front": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false } }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
This dataset was created using LeRobot and focuses on robotic manipulation, specifically cloth folding tasks (inferred from the filename). It consists of 91 episodes with a total of 148,440 frames at 30 fps. Features include: 6-dimensional joint position actions (shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, gripper position), 6-dimensional joint position observation states, front-view camera images (480x640 resolution, RGB three channels), and metadata such as timestamp, frame index, and episode index. Data is stored in parquet format with chunking, suitable for imitation learning or reinforcement learning in robotics.