LIBERO
收藏资源简介:
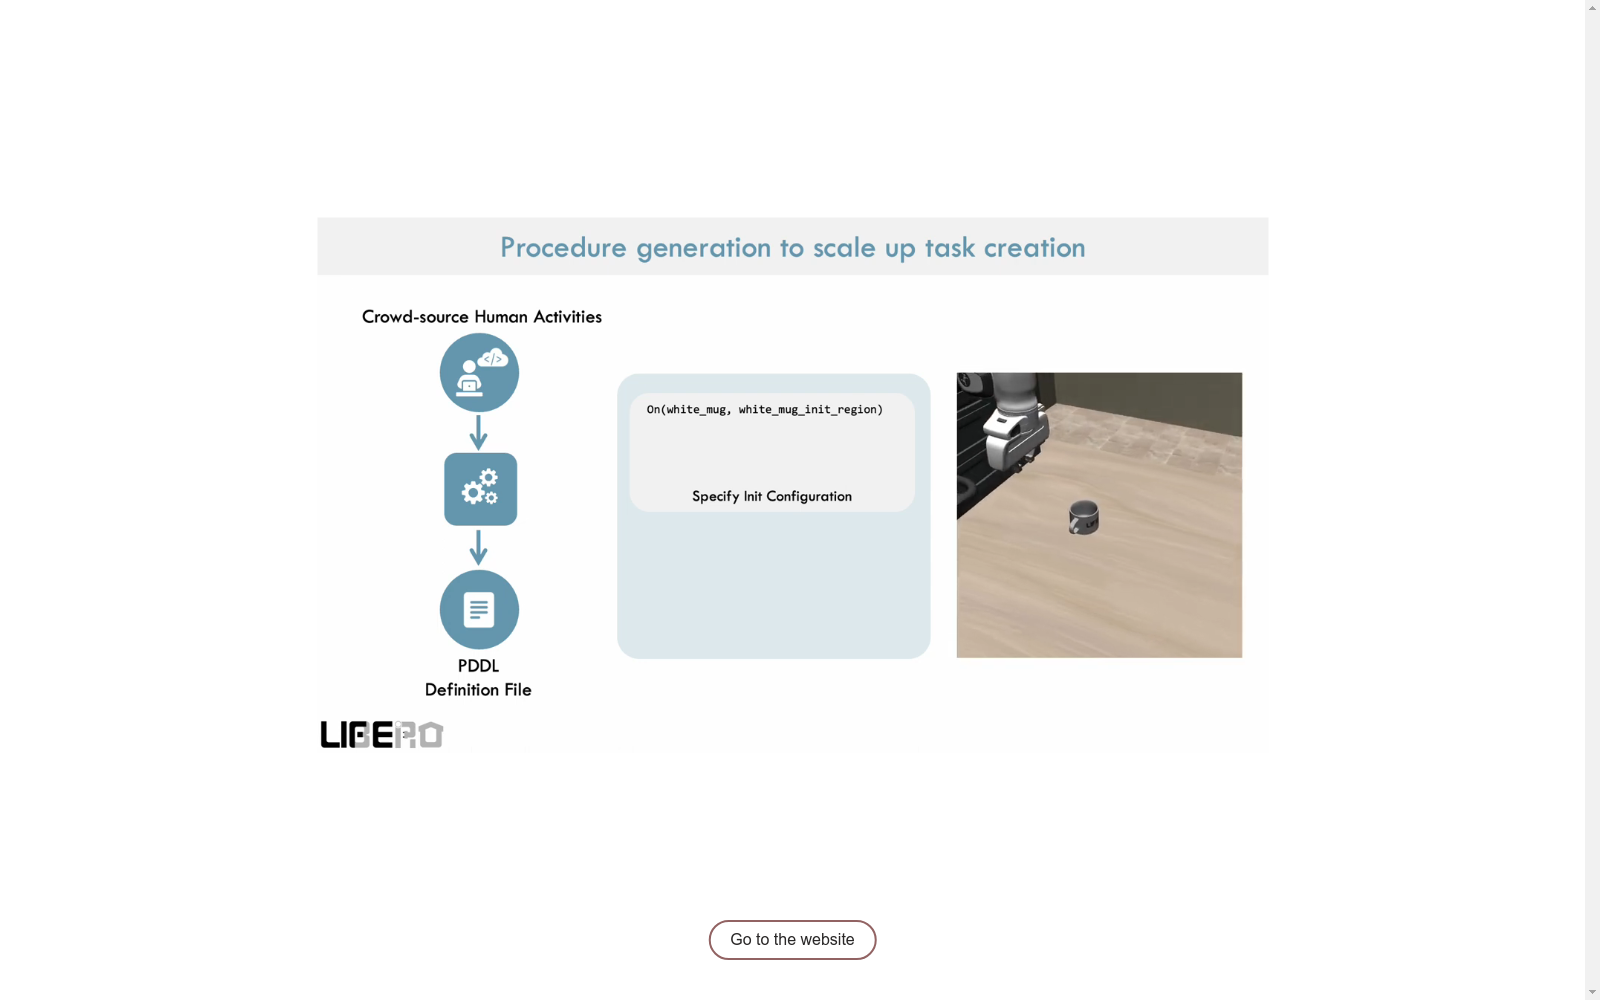
LIBERO是一个专为机器人操作设计的终身学习基准数据集,由德克萨斯大学奥斯汀分校的研究团队创建。数据集包含130个任务,旨在通过模拟人类活动,测试机器人在不同任务间的知识和技能转移能力。数据集通过一个可扩展的程序生成管道创建,支持高效学习,并提供了高质量的人类远程操作演示数据。LIBERO的应用领域主要集中在机器人学习和决策制定,特别是在需要程序性和声明性知识转移的场景中。
LIBERO is a lifelong learning benchmark dataset dedicated to robotic manipulation, developed by a research team at The University of Texas at Austin. The dataset encompasses 130 tasks, which are designed to test robots' capability of transferring knowledge and skills across diverse tasks by simulating human activities. Built upon a scalable programmatic generation pipeline, it supports efficient learning and provides high-quality human teleoperation demonstration data. The primary application domains of LIBERO lie in robotic learning and decision-making, especially in scenarios that demand procedural and declarative knowledge transfer.