clean_desk_cube_pi
收藏资源简介:
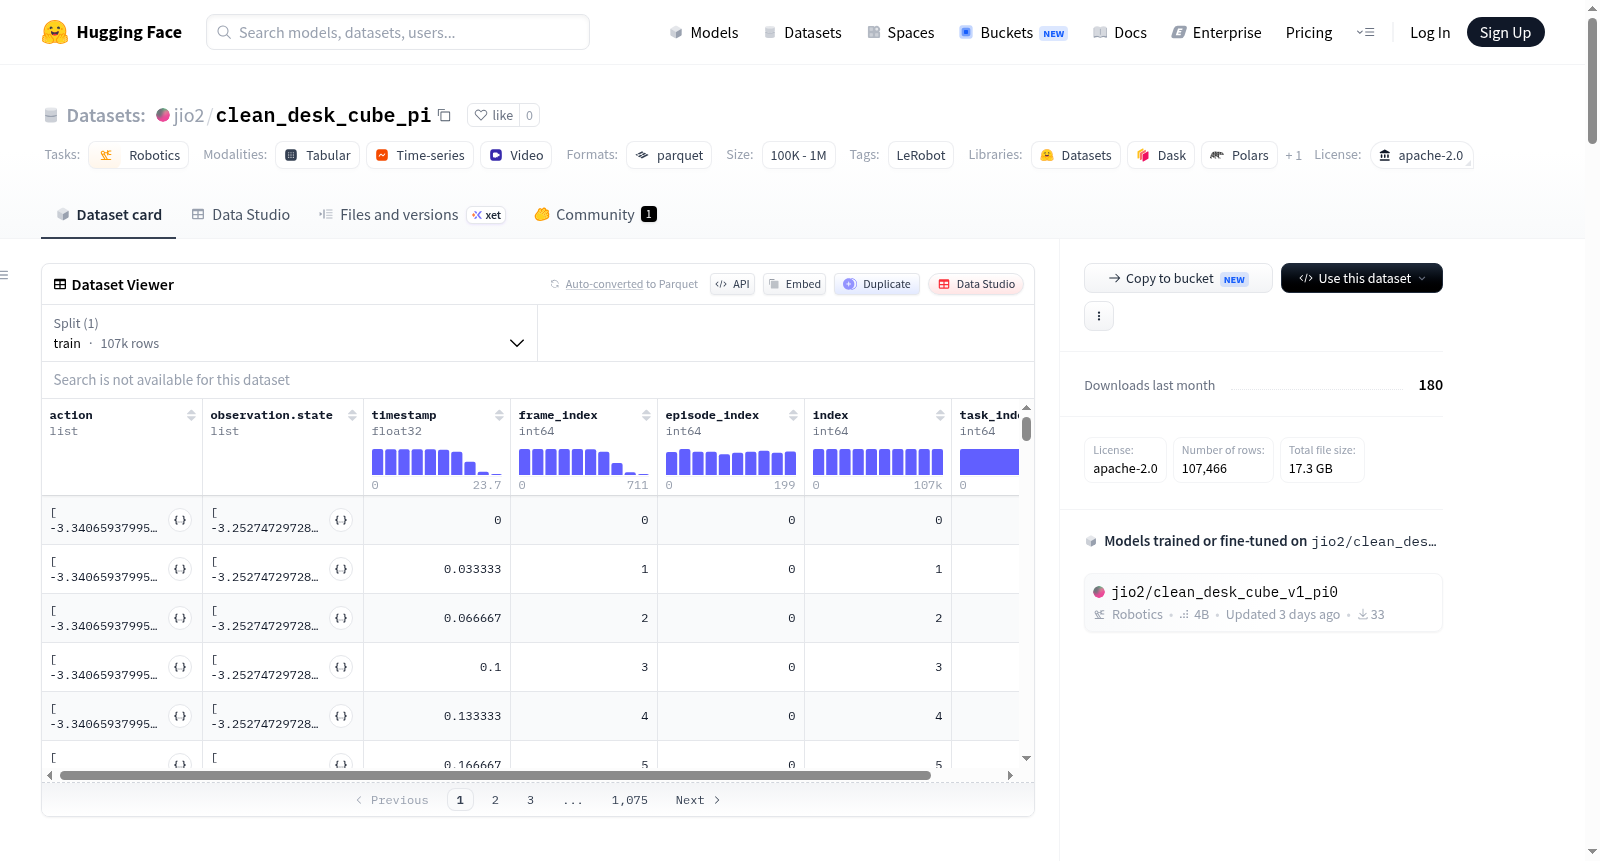
该数据集由LeRobot项目创建,是一个用于机器人学研究的开源数据集。数据集包含98个任务片段(episodes),共计58,766帧数据,采集帧率为30fps。数据内容涵盖双机械臂(bi_so_follower型机器人)的操控任务,具体包括:动作数据(12维浮点数组,表示左右机械臂的肩部平移、肩部抬升、肘部弯曲、腕部弯曲、腕部旋转和夹爪位置等12个关节的位置指令);状态观测(12维浮点数组,表示与动作数据对应的机械臂各关节的实际位置);以及来自三个不同视角的视觉观测(left_left_top、left_top、right_right_top),每个视角的视频分辨率为720×1280,3通道彩色,采用AV1编码。此外,数据集还包含时间戳、帧索引、片段索引、数据索引和任务索引等辅助字段。数据以parquet格式分块存储,总数据文件约100MB,视频文件约200MB。该数据集适用于机器人模仿学习、强化学习、视觉-动作映射等研究任务。
This dataset is created by the LeRobot project and is an open-source dataset for robotics research. It contains 98 task episodes, totaling 58,766 frames of data, with a collection frame rate of 30fps. The data covers manipulation tasks for a dual-arm robot (bi_so_follower type), including: action data (a 12-dimensional floating-point array representing position commands for 12 joints such as shoulder translation, shoulder elevation, elbow flexion, wrist flexion, wrist rotation, and gripper position for both left and right arms); state observations (a 12-dimensional floating-point array representing the actual positions of the robot arm joints corresponding to the action data); and visual observations from three different perspectives (left_left_top, left_top, right_right_top), with each perspectives video resolution being 720×1280, 3-channel color, encoded in AV1. Additionally, the dataset includes auxiliary fields such as timestamps, frame indices, episode indices, data indices, and task indices. The data is stored in parquet format in chunks, with total data files approximately 100MB and video files approximately 200MB. This dataset is suitable for research tasks such as robot imitation learning, reinforcement learning, and vision-action mapping.